← Bo Shang CV Portfolio
Infrastructure Deck ↗ PDF PPTX
MECHATRONICS FACULTY RESEARCH STATEMENT PRESENTATION

Intelligent Field Mechatronics: Reconfigurable Mechanisms, Fractional-Order Control, and Multi-Sensor Autonomy

From Hybrid Aerial-Climbing Robots and Delay-Robust Flight Control to 3D Robotic NDT and Synchronized Infrastructure Sensing

US 12,296,994 B2

Granted Hybrid Robot Patent & ASCE 2025 Pankow Award

0.933 s vs. 0.546 s

+71% Vision Sampling-Period Margin via Fractional PD^μ

IEEE T-ASE / IROS 25

Climbing-Robot + Serverless Cloud 3D Defect Analytics

5 Lab/Lecture Courses

Mechatronics, UAS, Circuits & Robotics Control Taught

Bo Shang, Ph.D. · Postdoctoral Associate · Civil & Environmental Engineering & Maryland Transportation Institute · University of Maryland, College Park
bshang@umd.edu · cnpcshangbo.github.io
BACKGROUND · MECHATRONICS RESEARCH & HANDS-ON TEACHING 02 / 26

Academic Trajectory & Mechatronics Laboratory Teaching Record

Research Appointments & Education

  • Jul 2026 – Present: Postdoctoral Associate, University of Maryland, College Park (CEE & Maryland Transportation Institute; Advisor: Prof. Xianfeng Yang).
  • Dec 2022 – Jun 2026: Postdoctoral Researcher, CCNY Robotics Lab & AI/Mobility Lab; Adjunct Assistant Professor, CUNY City College & Vaughn College.
  • 2020 – 2022: Postdoctoral Fellow, Missouri University of Science and Technology (INSPIRE UTC · BIRDS Hybrid Bridge Robot).
  • Ph.D. (2020): Pattern Recognition & Intelligent Systems, Northeastern University · Exchange Ph.D. & Junior Specialist (2015–2017): UC Merced MESALab (Prof. YangQuan Chen).

Hands-On Mechatronics, Circuits & Robotics Courses Taught

  • MCE 355 — Introduction to Robotics, Mechanics & Control (Vaughn College, Adjunct Assistant Professor).
  • ENGR 204 — Electric Circuits (CUNY City College, Adjunct Assistant Professor).
  • ME 190 — Mechatronics Labs (UC Merced: microcontrollers, sensors, actuators, closed-loop benchtop builds).
  • ME 143 — Unmanned Aircraft Systems Labs & ME 021 — Engineering Computing Labs (UC Merced).
  • Core Mechatronics Stack: C/C++, Python, ROS, Embedded Linux (Jetson/Odroid/RPi), TI Tiva C / Arduino / PX4, MATLAB/Simulink, OpenCV, PyTorch.
RESEARCH THESIS · WHY FIELD MECHATRONICS IS HARD 03 / 26

Co-Designing Mechanisms, Embedded Sensing, and Robust Control

1. Reconfigurable Mechanisms

  • Pure multirotors exhaust batteries in minutes while fighting under-bridge wind gusts.
  • Mechatronic solution: Dual-mode aerial flight + rapid 1.3 s mechanical flange clamping + motorized surface rolling (US Patent 12,296,994 B2), plus wall-climbing NDT robots.

2. Embedded Multi-Sensor Fusion

  • GPS and magnetometers fail beneath steel bridge decks; asynchronous sensors smear 3D geometry.
  • Mechatronic solution: Onboard RGB-D flange/heading perception on Jetson/RPi, quadrature encoder limit loops, and sub-frame LiDAR-camera clock synchronization.

3. Delay- & Gain-Robust Control

  • Onboard vision latency, payload shifts, and wind disturbances destabilize integer-order PID loops.
  • Mechatronic solution: Iso-damping fractional-order PD^μ control expanding maximum vision sampling period by +71% (0.546 s → 0.933 s) with flat crossover phase.

Synthesis: Core Principle: Treat mechanism compliance, sensor latency, and feedback control as a single coupled co-design problem rather than isolated layers.

PORTFOLIO OVERVIEW · VAUGHN BASE + 2024–2026 UPDATES 04 / 26

Four Connected Mechatronic Systems Across Scales

I. BIRDS Hybrid Robot

  • Flying + steel I-girder clamping & rolling robot.
  • TI Tiva C + 4× DC/encoder arms + Jetson RGB-D + ROS.
  • New: US Patent 12,296,994 B2 (2025) & ASCE Pankow Award.

II. Fractional UAV Control

  • Iso-damping PD^μ visual servoing on PX4 + Odroid.
  • Max sampling period: 0.933 s vs. 0.546 s (+71%).
  • Browser HSV tuner GUI & +20% flight hover precision.

III. Climbing 3D NDT

  • Wall-climbing robot + iPad RGB-D/gravity app.
  • AWS Lambda CNN + WebODM 3D crack skeletonization.
  • New: Published in IEEE T-ASE 2025 & IROS 2025.

IV. Roadside 3D Pods

  • 2025–2026 mechatronic sensor-pod extension.
  • LiDAR-RGB sync (90.1% vs. 72.9% on NYSDOT I-95; 61.9 h).
  • PACO occlusion law (0.37 → 1.00) & UMD CERRA.
THRUST I · HYBRID AERIAL-SURFACE MECHATRONICS 05 / 26

Bridge Inspection Robot Deployment System (BIRDS)

Mechanical clamping kinematics, closed-loop MCU motor/encoder electronics, onboard RGB-D flange perception, and GPS-denied flight-to-traverse reconfiguration.

US 12,296,994 B2

Granted Patent (May 2025)

ASCE Pankow 2025

National Innovation Award

1.3 s Close / 8.5 s Open

Asymmetric Clamping Control

6 Hardware Videos

Bench, Vision, Perch & Traverse

THRUST I · MOTIVATION & DUAL-SUBSYSTEM DESIGN 06 / 26

BIRDS: Decoupling Flight Endurance from Bridge Inspection Time

Engineering Motivation & System Architecture

  • 617,000+ U.S. bridges require biennial inspection; snooper trucks block highway lanes, while hovering drones drain batteries in 15–20 min.
  • Dual-Mode Hybrid Vehicle: Flies up beneath a steel I-girder, clamps onto the bottom flange, powers down rotors (0 W flight power), and rolls along the span.
  • Multi-Camera NDT Payload: Synchronized visible, thermal IR, and hyperspectral cameras supervised via a custom iOS app.
  • Updated Milestones (2024–2025): Granted U.S. Patent 12,296,994 B2 (Chen, Reven, Shang, Shi, Li), ASCE 2025 Charles Pankow Award (PI: Genda Chen), and Report INSPIRE-024.
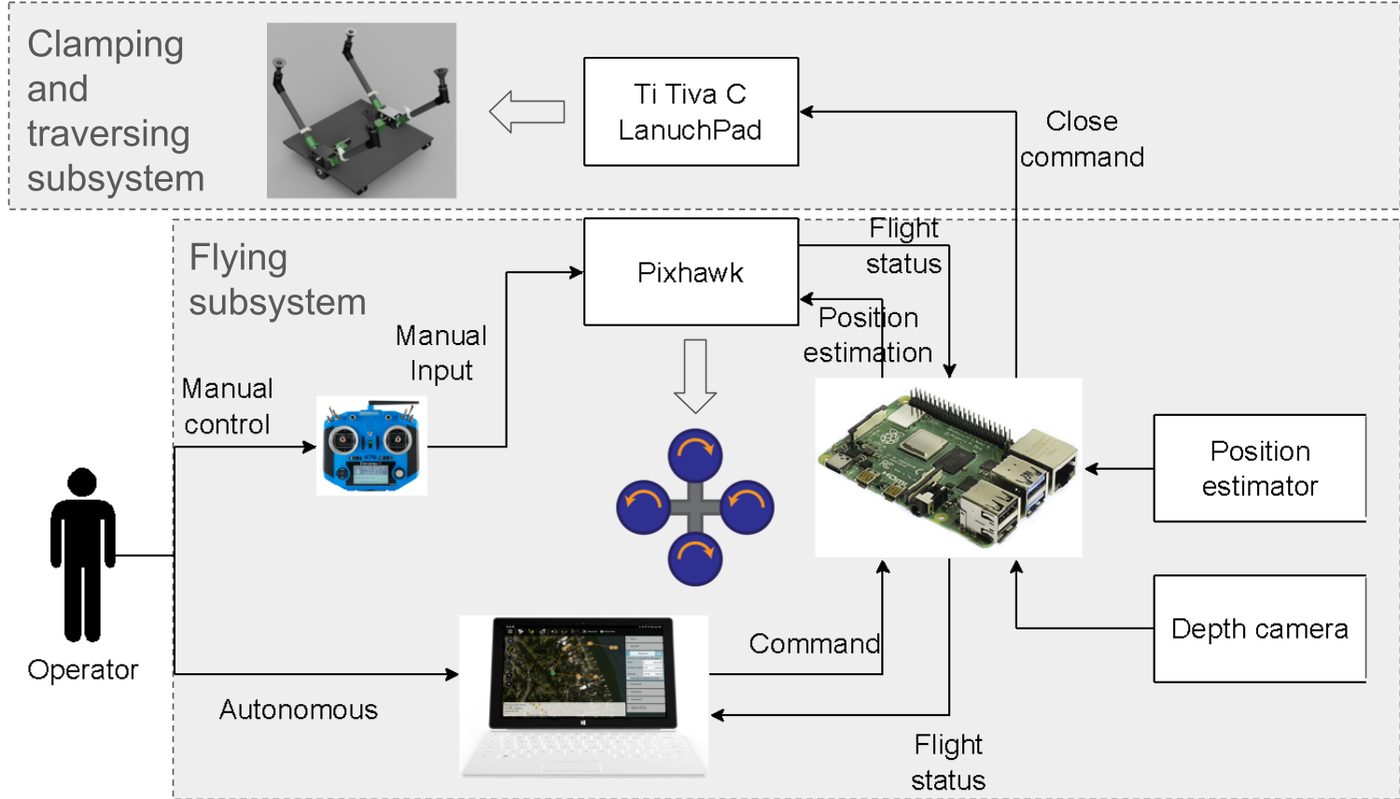
Patented BIRDS dual-subsystem architecture integrating the flying UAS and clamping-traversing carriage.
THRUST I · ELECTRO-MECHANICAL SUBSYSTEM 07 / 26

Clamping & Traversing Subsystem: Mechanical CAD & MCU Electronics

Dual V-arm clamping geometry self-centers on I-girder flanges while a TI Tiva C LaunchPad microcontroller closes 4 independent motor + quadrature-encoder loops.
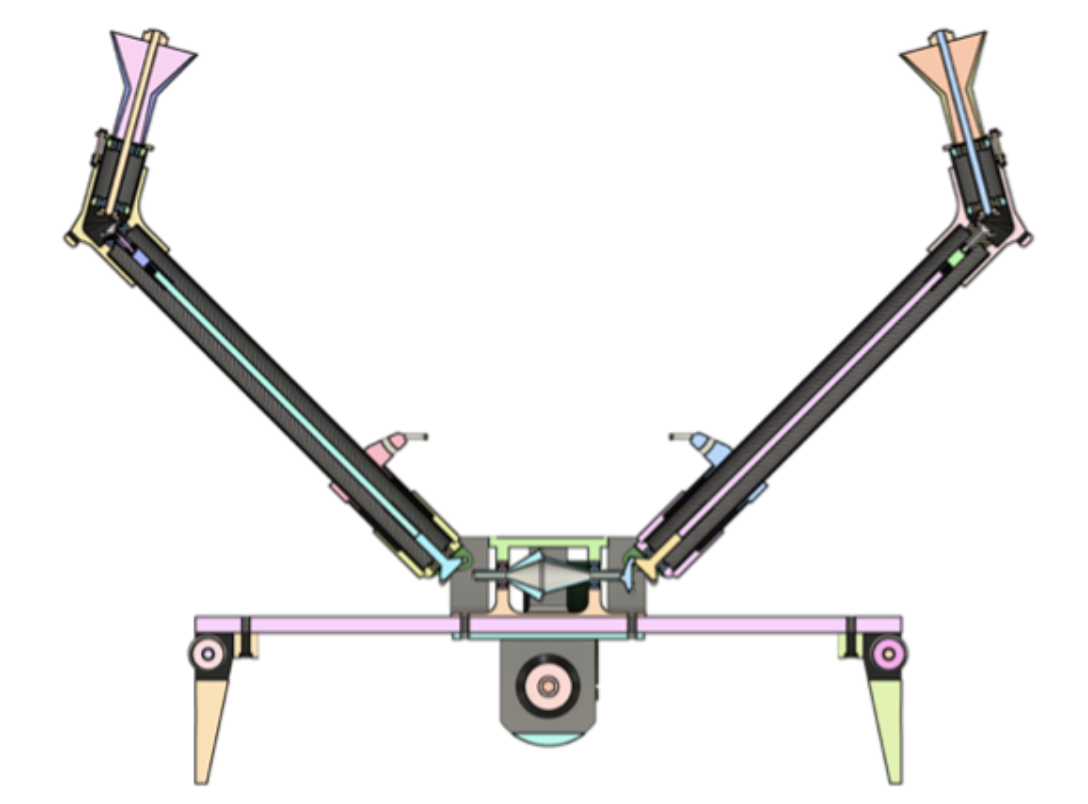
Mechanical CAD: Dual pivoting clamping arms, lead-screw/gear actuation, and compliant flange rollers.
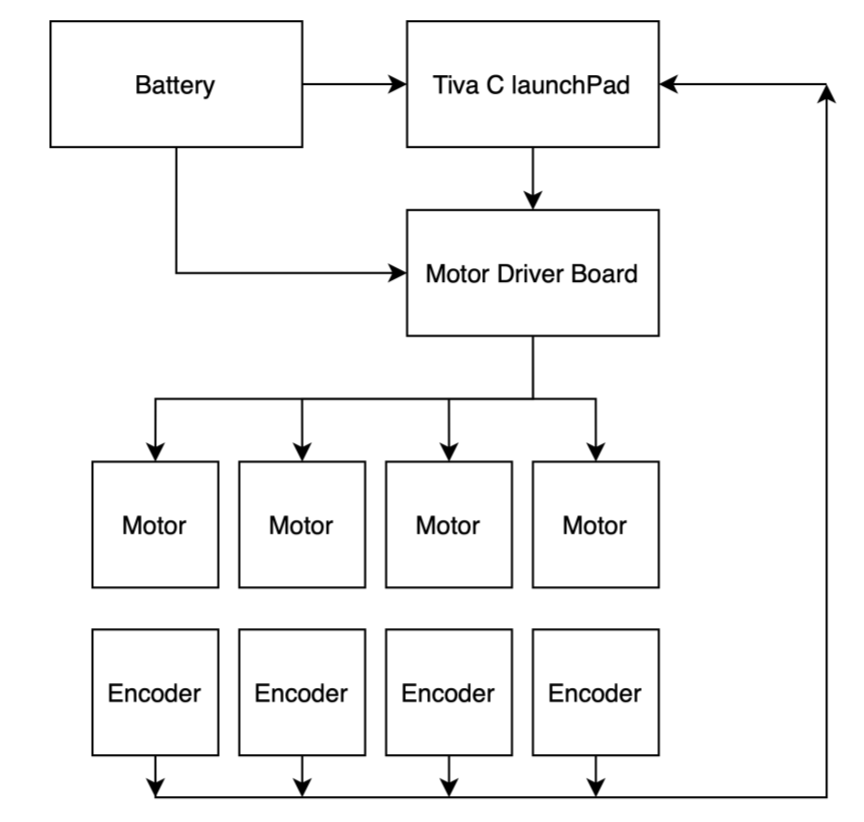
Electronic Architecture: Battery → TI Tiva C LaunchPad → Motor Driver Board → 4 Motors + 4 Quadrature Encoders.
THRUST I · ACTUATOR CONTROL & BENCH VALIDATION 08 / 26

Asymmetric Clamping Control (1.3 s Capture) & Live Bench Test
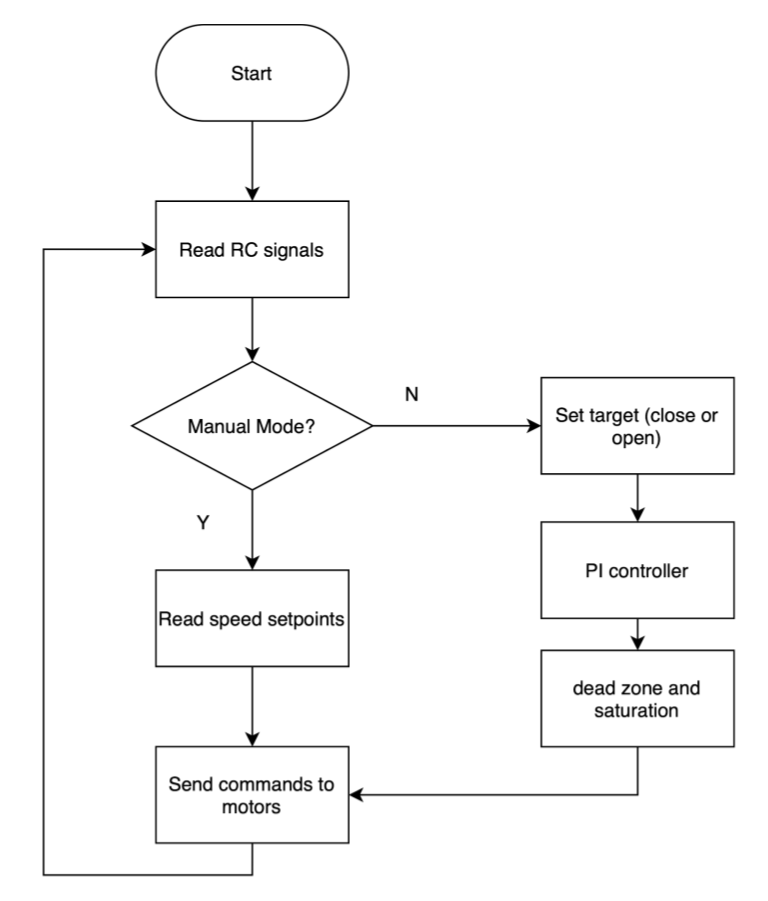
Firmware flowchart: RC/Auto target → PI loop → dead-zone & saturation.
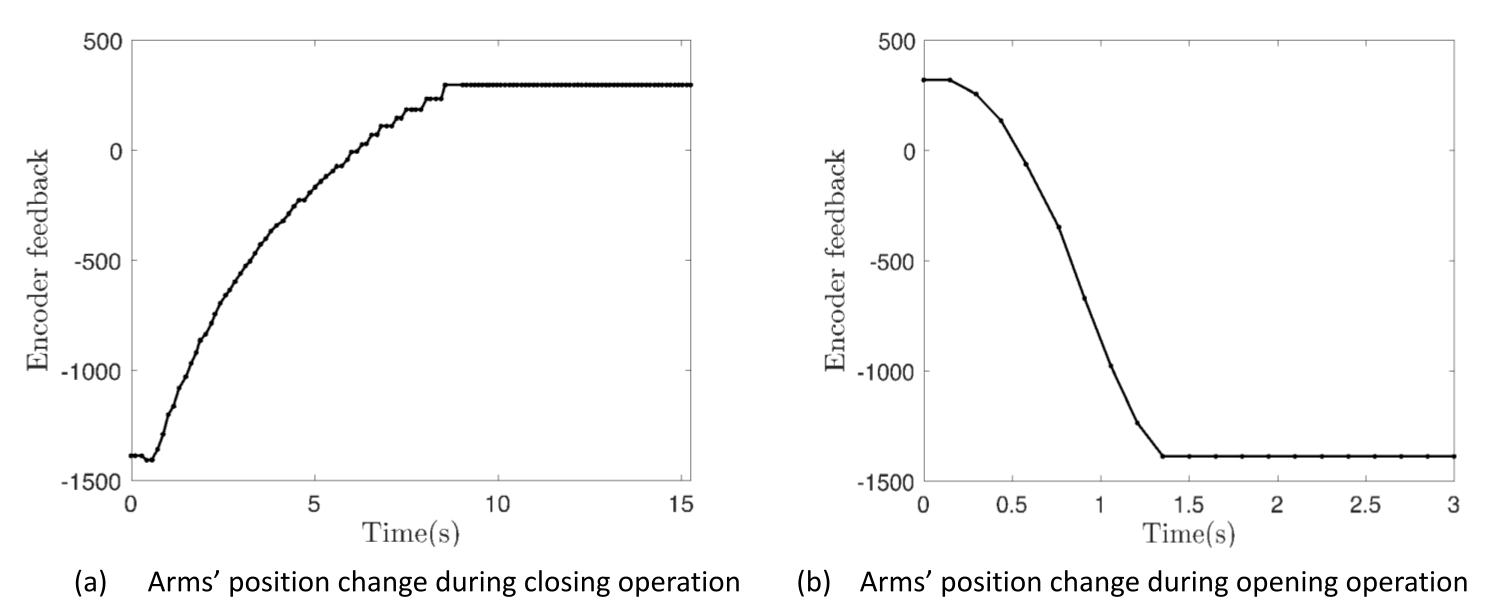
Encoder response: ~1.3 s urgent closing vs. ~8.5 s smooth opening.
Experimental bench test of synchronized front/rear clamping arms with position limits.
Experimental bench test of synchronized front/rear clamping arms with position limits. · YouTube ↗
THRUST I · AUTONOMOUS FLIGHT SUBSYSTEM 09 / 26

Flying Subsystem: Embedded Vision Hardware, MAVROS & Vicon Hover
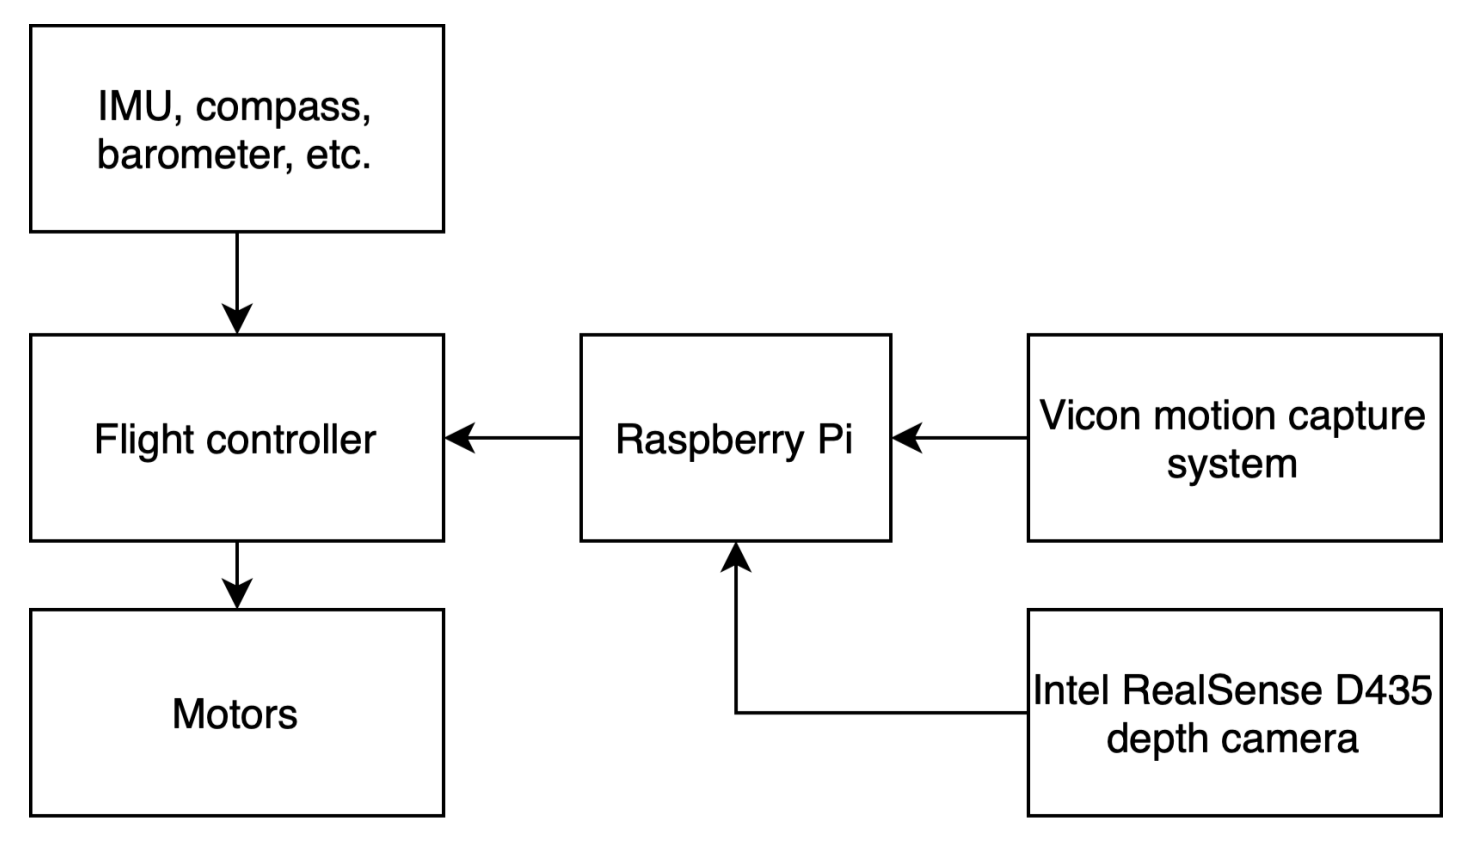
Hardware: Flight controller + RPi/Jetson + RealSense D435 + Vicon.
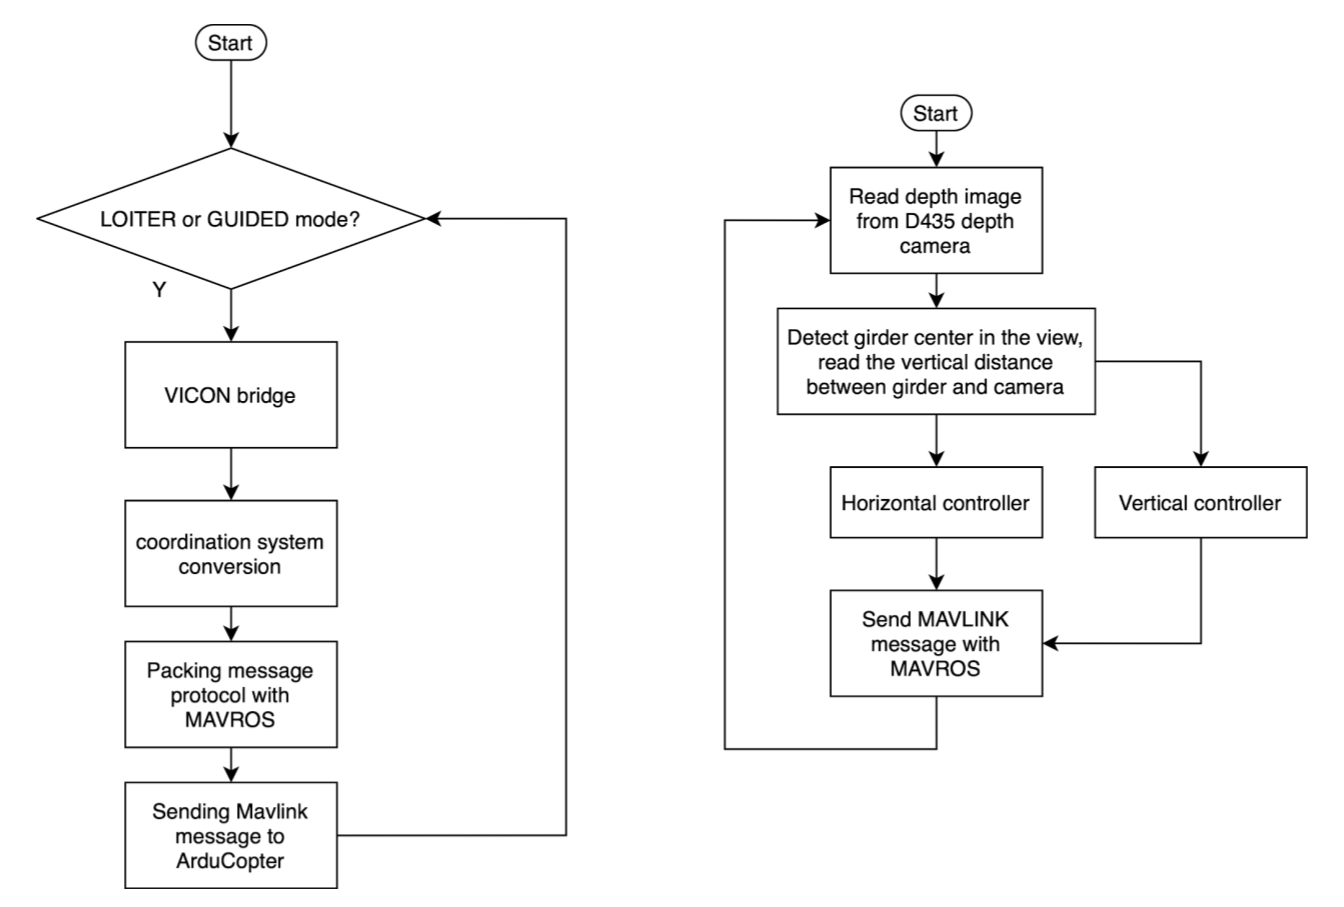
Software: Parallel Vicon/MAVROS bridge & D435 horizontal/vertical loops.
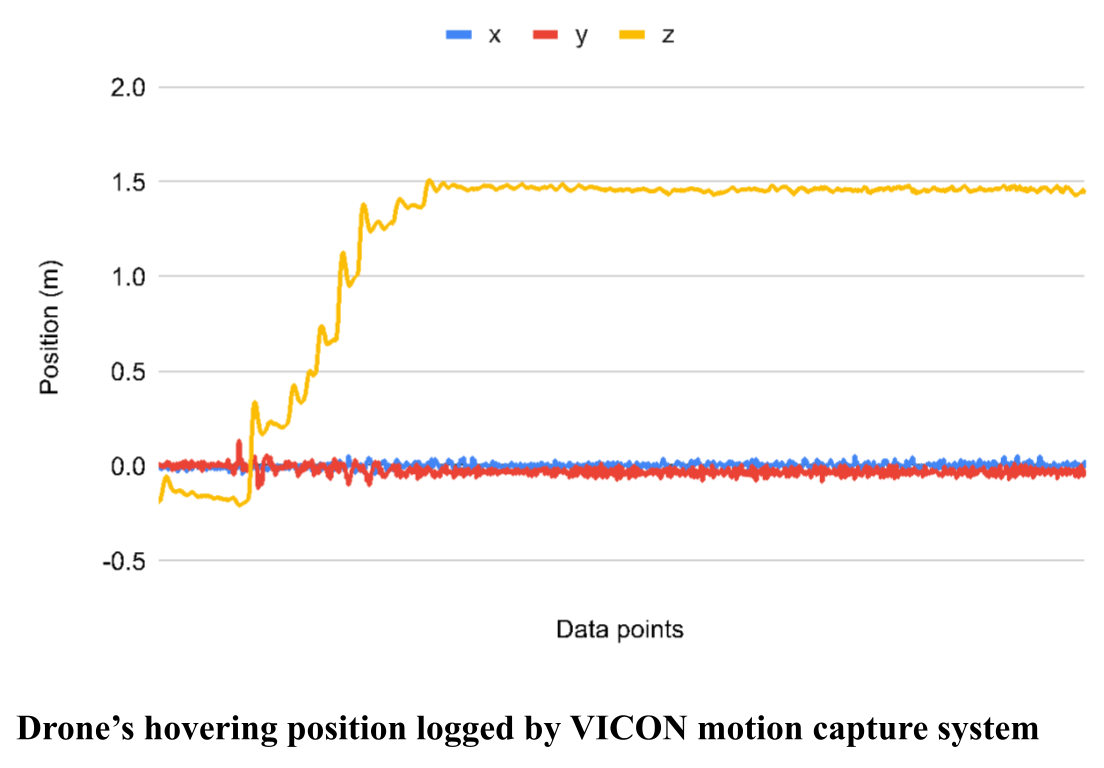
GPS-denied Vicon hovering test verifying tight X/Y/Z hold at 1.5 m.
THRUST I · EDGE PERCEPTION TO ACTUATION (INLINE VIDEOS) 10 / 26

Onboard RGB-D Flange Tracking & Autonomous Distance Trigger

Real-Time Depth Segmentation & Closed-Loop Trigger

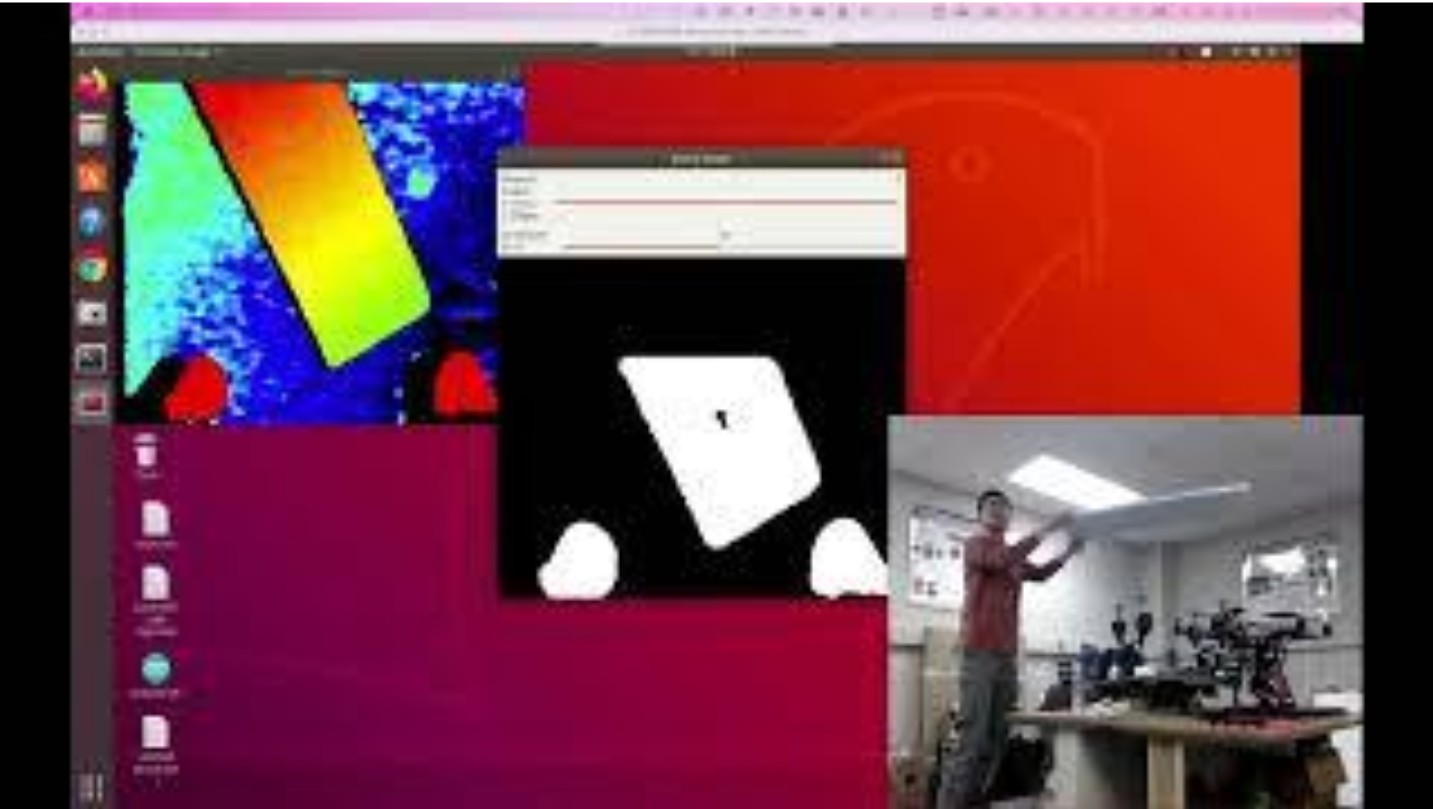
  • Upward RealSense D435 Pipeline: Segments overhead girder plane, extracting flange centroid (pink), inlier points (red), and metric camera-to-steel standoff (yellow).
  • Zero-Human-Latency Trigger: When vertical distance drops below the capture threshold (e.g., 0.26 m), ROS immediately commands the Tiva C clamping controller to fire.
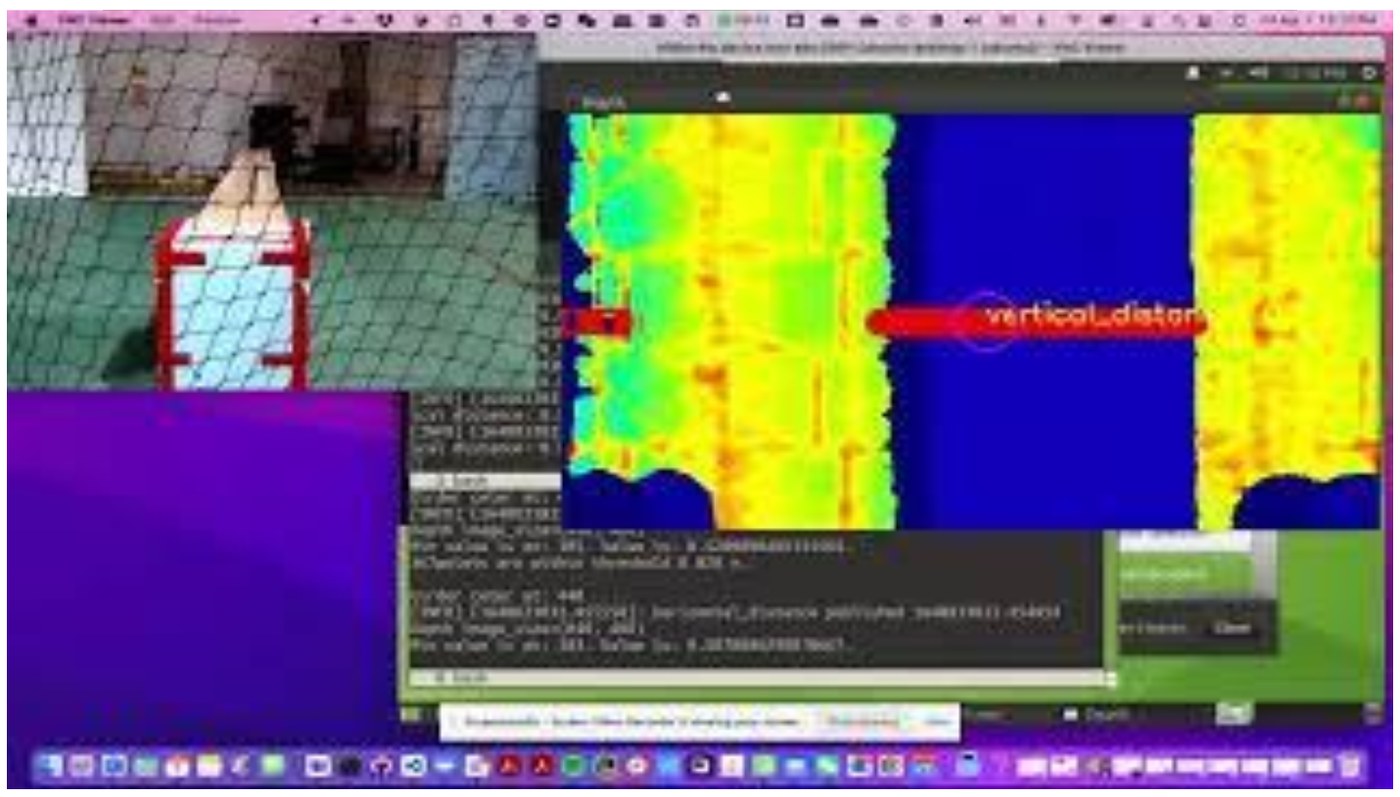
Video 1: Real-time girder center & vertical distance tracking.
Video 1: Real-time girder center & vertical distance tracking. · YouTube ↗
Video 2: Autonomous 1.3 s arm closure triggered by RGB-D distance.
Video 2: Autonomous 1.3 s arm closure triggered by RGB-D distance. · YouTube ↗
THRUST I · GPS/COMPASS-DENIED ALIGNMENT & PERCHING 11 / 26

Non-GPS Yaw Alignment & Full Flight-to-Girder Clamping Test
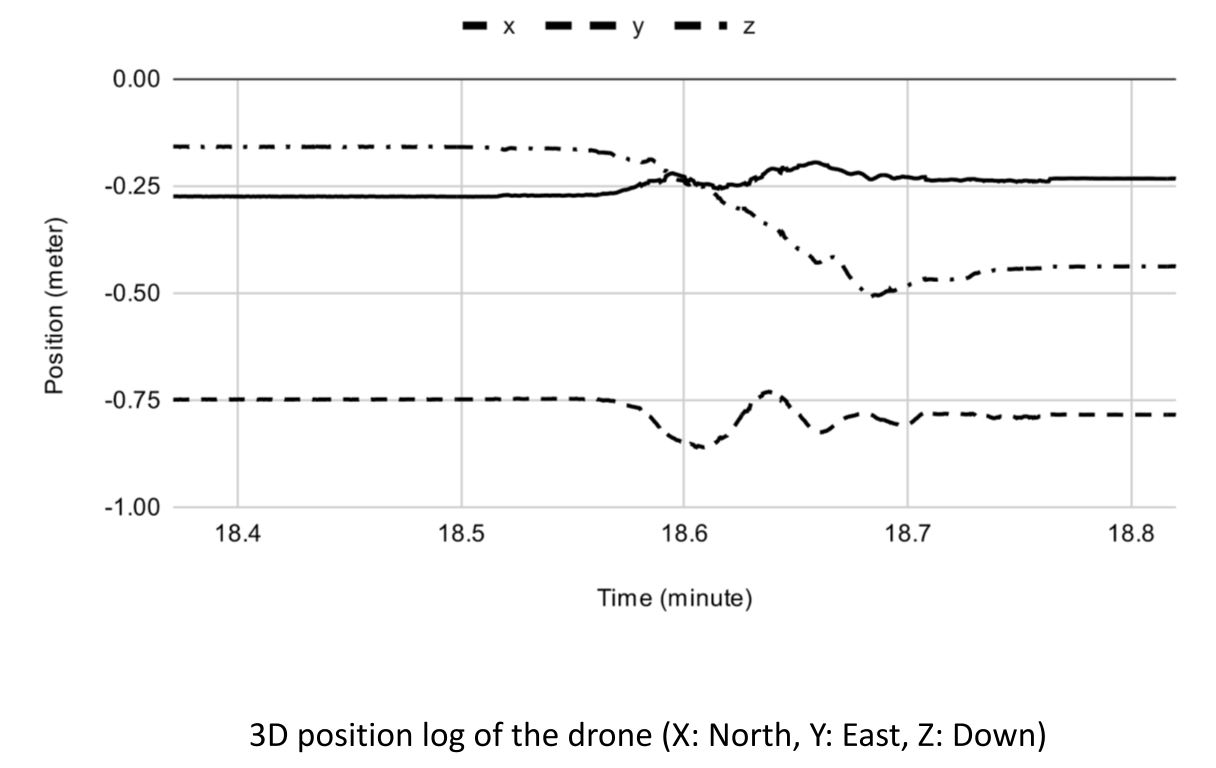
Logged 3D NED trajectory (X, Y, Z) across approach, clamping & perch.
Video 3: Depth-mask girder yaw alignment without compass/GPS.
Video 3: Depth-mask girder yaw alignment without compass/GPS. · YouTube ↗
Video 4: Assisted approaching & automated overhead beam clamping.
Video 4: Assisted approaching & automated overhead beam clamping. · YouTube ↗
THRUST I · SURFACE TRAVERSE MODE & COMPANION ROBOTICS 12 / 26

Zero-Flight-Power Steel I-Girder Traversal & Scour Robotics

Clamped Rolling Inspection & Broader Inspection Suite

  • Surface Traverse Configuration: Once clamped, quadrotor motors power off completely; motorized drive wheels roll BIRDS along the steel I-girder bottom flange.
  • Companion Underwater Scour Robot: Built ROS + Arduino + embedded Linux acoustic-imaging robot for submerged bridge pier scour evaluation.
  • HIL & Digital Twin Extension: Co-authored hardware-in-the-loop & digital-twin autonomous robotics inspection (IEEE ISAS 2023).
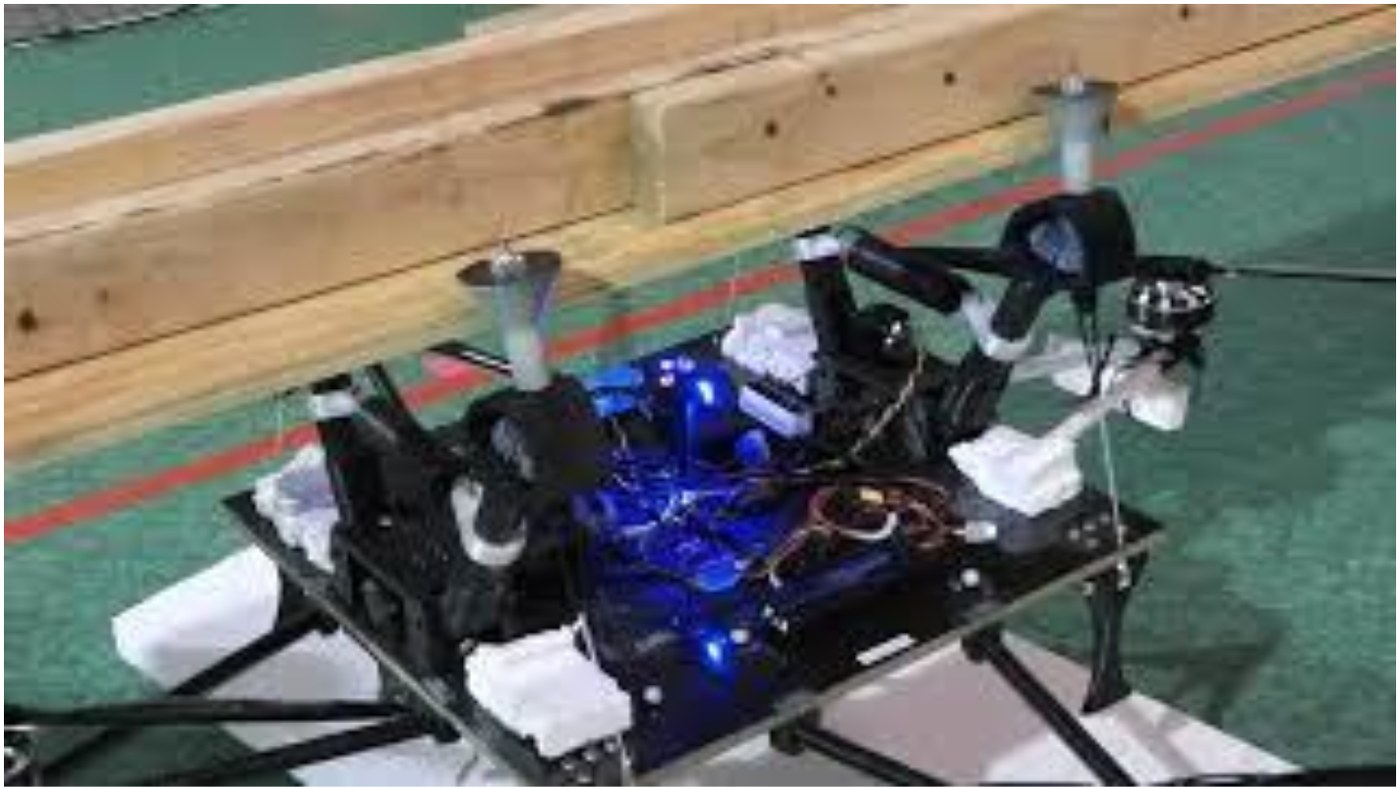
BIRDS2 clamped onto a steel I-girder executing motorized rolling traversal with rotors off.
BIRDS2 clamped onto a steel I-girder executing motorized rolling traversal with rotors off. · YouTube ↗
THRUST II · ROBUST CONTROL THEORY MEETS EMBEDDED VISION 13 / 26

Fractional-Order Autonomous UAV Visual Servoing

Iso-damping PD^μ synthesis, analytical maximum sampling-period stability bounds, embedded PX4-Odroid integration, and live browser vision tuning.

0.933 s vs. 0.546 s

+71% Max Vision Sampling Period

d∠G(jω)/dω = 0

Iso-Damping Gain Invariance

+20% Precision

Outdoor Flight Hover Improvement

Nonlinear Dynamics

Springer Journal (2019) + ICUAS

THRUST II · PROBLEM FORMULATION & CONTROL STRUCTURE 14 / 26

Quadrotor Visual Servoing Under Wind & Vision Latency

Why Classical Integer-Order PID Struggles on Small UAVs

  • GPS-Denied Drift: Under bridges, indoors, and inside caves, position hold relies on onboard monocular/RGB-D visual servoing.
  • Coupled Disturbances: Aerodynamic gusts, battery voltage sag (changing actuator gain K), and low-FPS embedded vision delay erode phase margin.
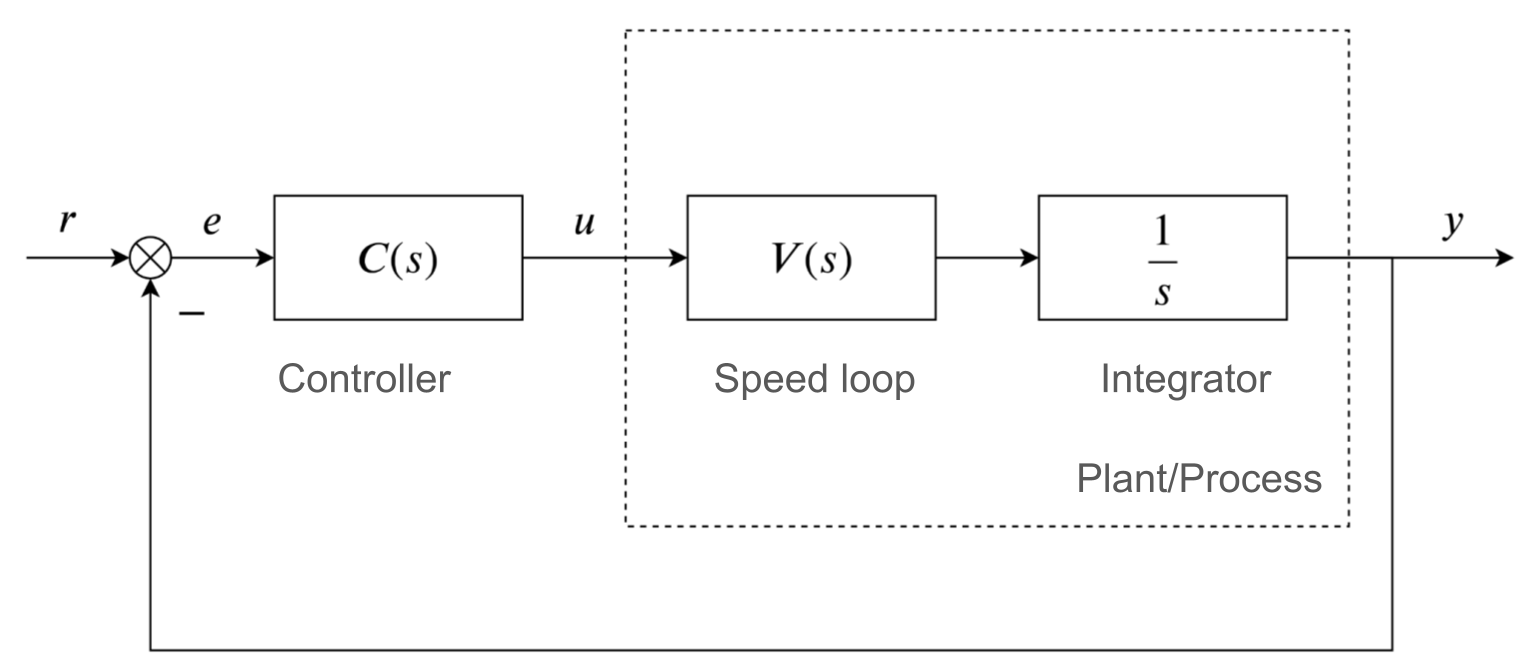
  • Cascaded Outer/Inner Loop: Outer visual position controller C(s) commands the inner autopilot velocity loop V(s) = k / (τs + 1) cascaded with kinematic integrator 1/s.
Cascaded visual-servoing feedback loop: C(s) outer vision controller driving speed loop V(s) and 1/s integrator.
THRUST II · FREQUENCY-DOMAIN ISO-DAMPING DESIGN 15 / 26

Extending Integer PID to Iso-Damping Fractional-Order PD^μ

Three Exact Frequency-Domain Specifications at ω_c

  • Controller Law: C(s) = K_p + K_d s^μ (continuous fractional differentiation order μ ∈ (0, 2) adds an analytical degree of freedom).
  • 1. Phase Margin: Arg[C(jω_c) P(jω_c)] = −π + φ_m.
  • 2. Iso-Damping (Flat Phase): | d Arg[C(jω) P(jω)] / dω |_{ω=ω_c} = 0.
  • 3. Unity Gain Crossover: |C(jω_c) P(jω_c)|_{dB} = 0.
  • Physical Meaning: Zero phase slope around ω_c preserves phase margin even when plant gain or delay shifts!
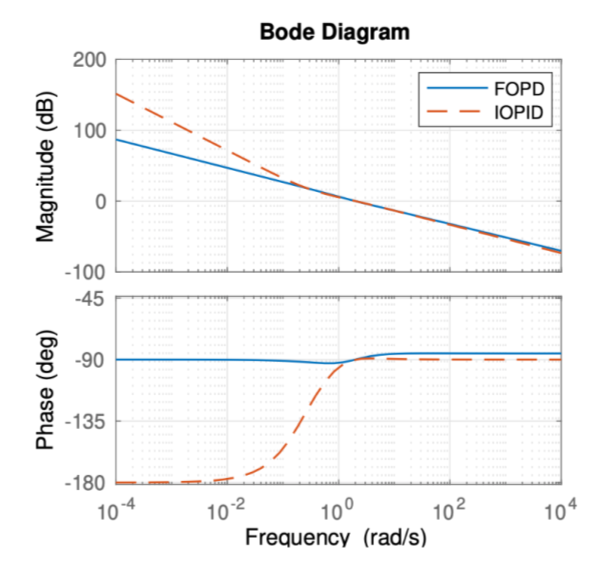
Open-loop Bode comparison: FOPD achieves a flat phase plateau across crossover ω_c unlike steep IOPID phase roll-off.
THRUST II · SIMULINK SYNTHESIS & GAIN ROBUSTNESS 16 / 26

Iso-Damping Invariance Against ±50% Plant-Gain Variations

When actuator/payload gain varies from 50% K to 150% K, IOPID overshoot fluctuates substantially while FOPD maintains nearly identical, virtually zero-overshoot convergence.
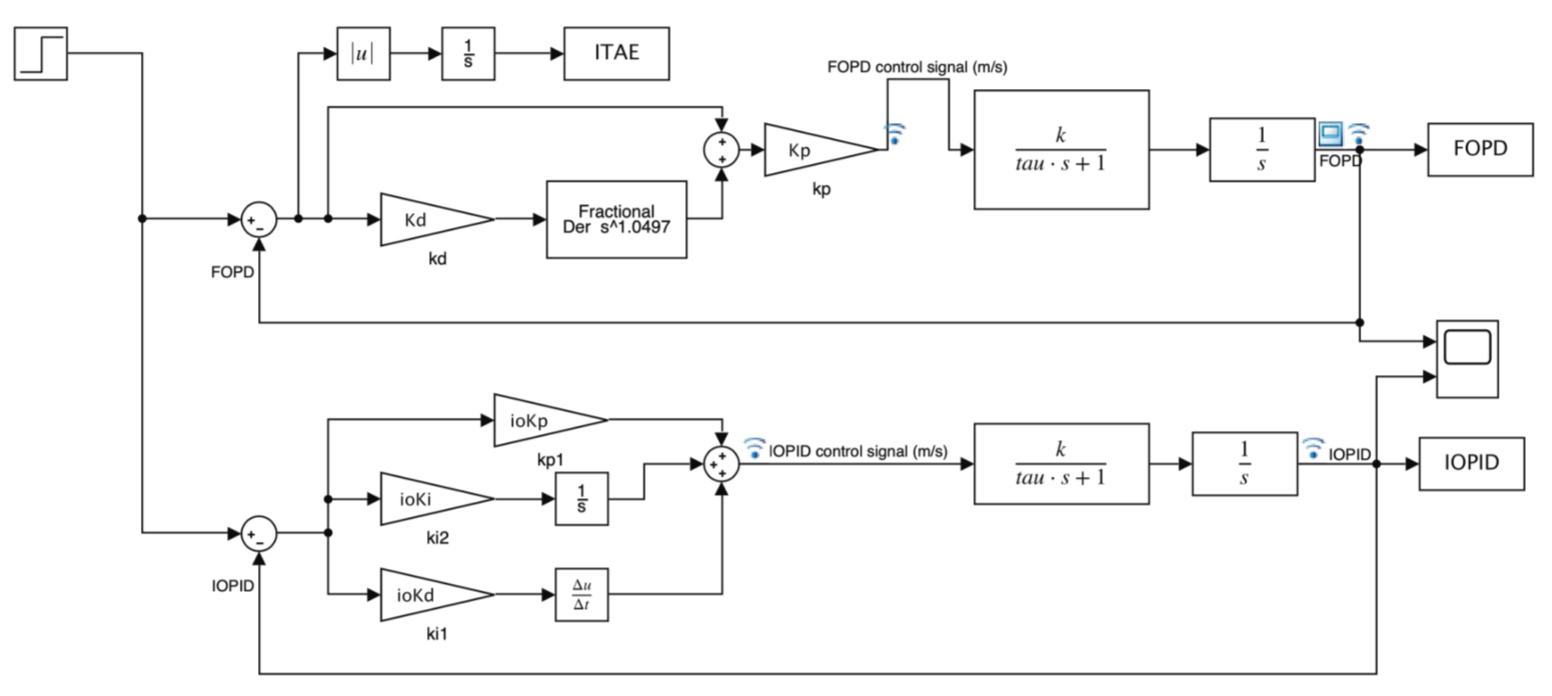
Parallel MATLAB/Simulink benchmark (Fractional Der s^1.0497 vs. tuned IOPID with ITAE instrumentation).
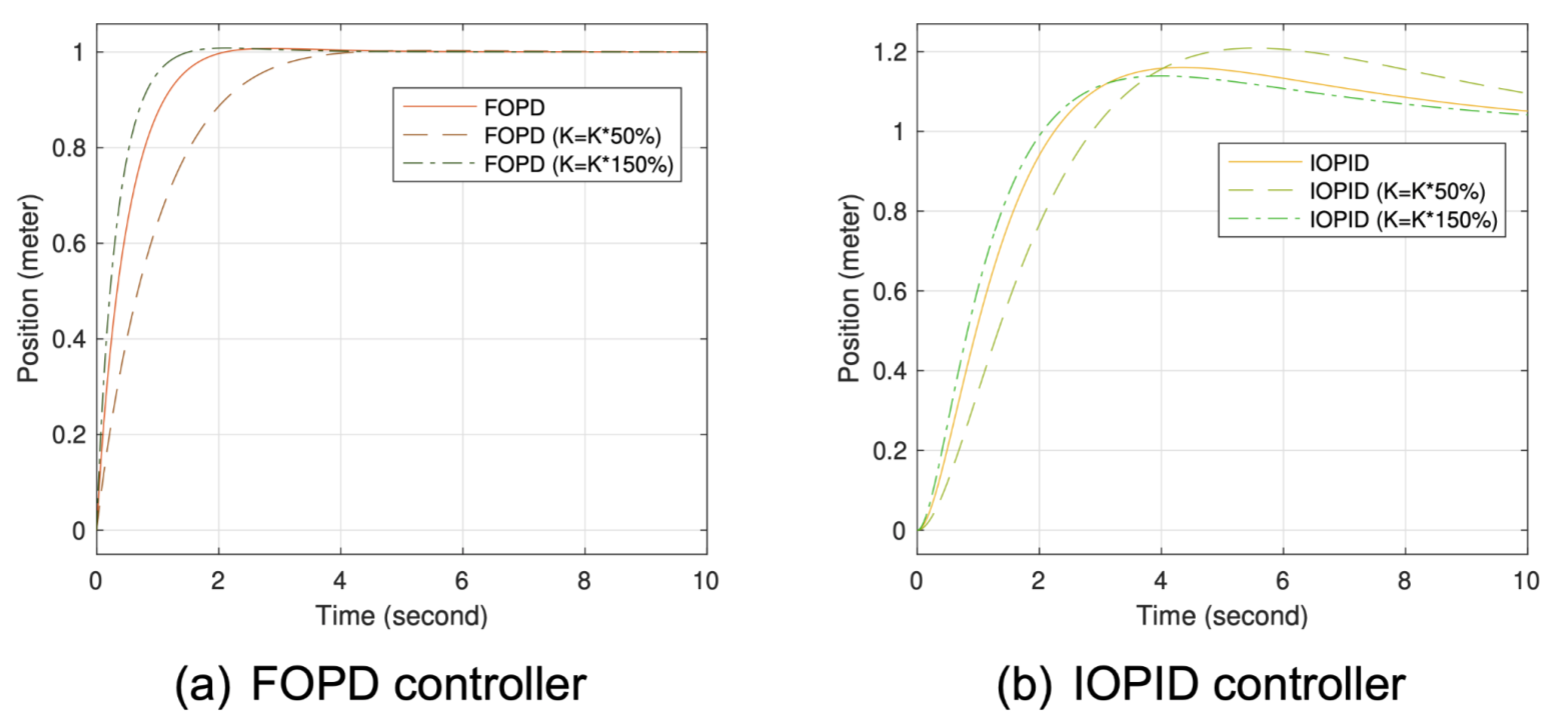
Step responses under K, 0.5K, and 1.5K: (a) FOPD iso-damped constant overshoot vs. (b) IOPID overshoot variation.
THRUST II · SAMPLED-DATA DELAY STABILITY BOUNDS 17 / 26

Expanding Maximum Vision Sampling Period by +71% (0.933 s)

Stability boundary analysis proves IOPID diverges past h_max = 0.546 s, whereas FOPD remains stable up to h_max = 0.933 s — dramatic resilience to onboard vision compute load.
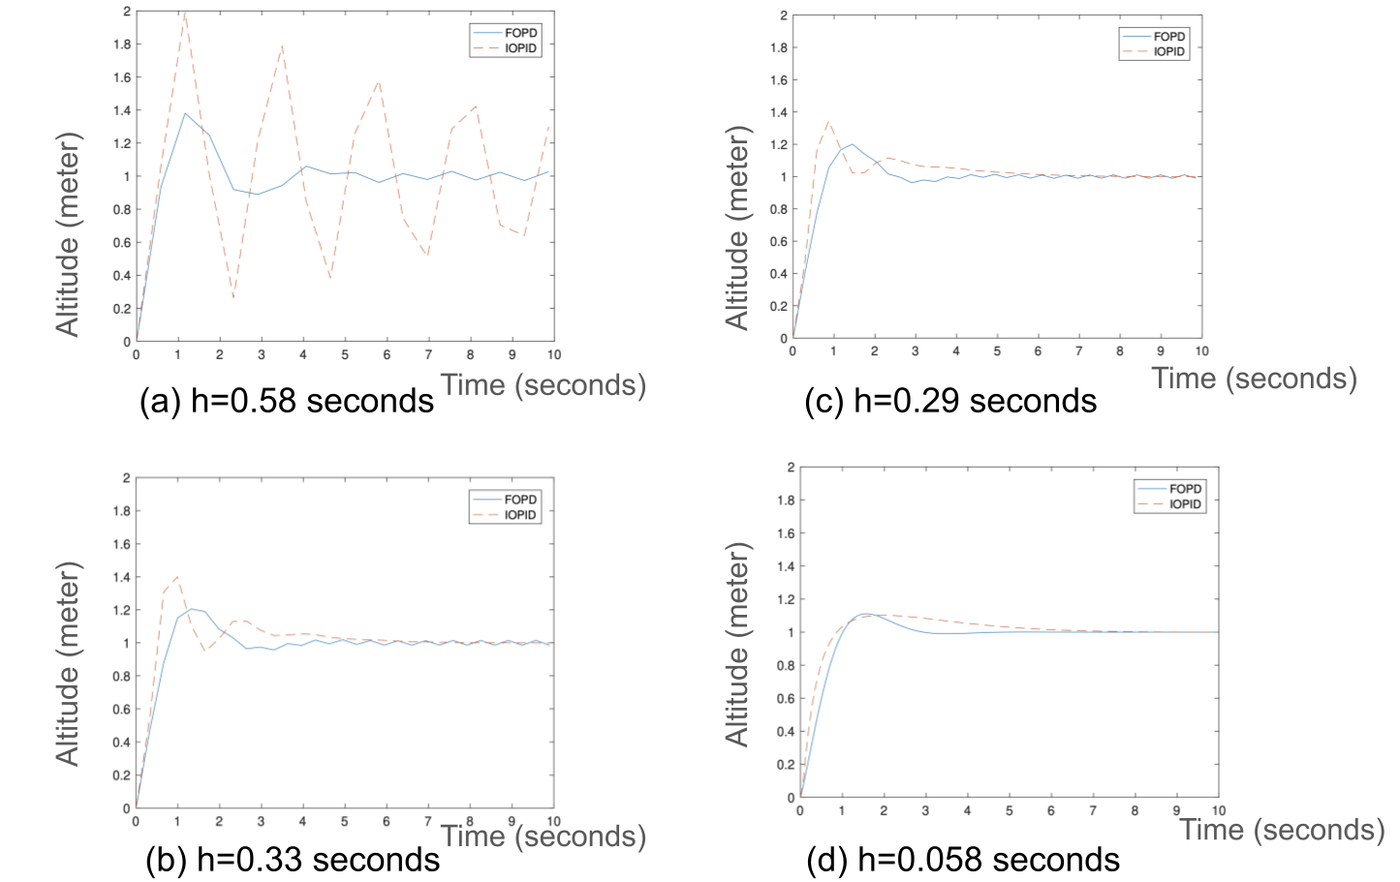
Multi-rate step responses at h = 0.58 s, 0.33 s, 0.29 s, and 0.058 s (FOPD stays stable at 0.58 s where IOPID diverges).
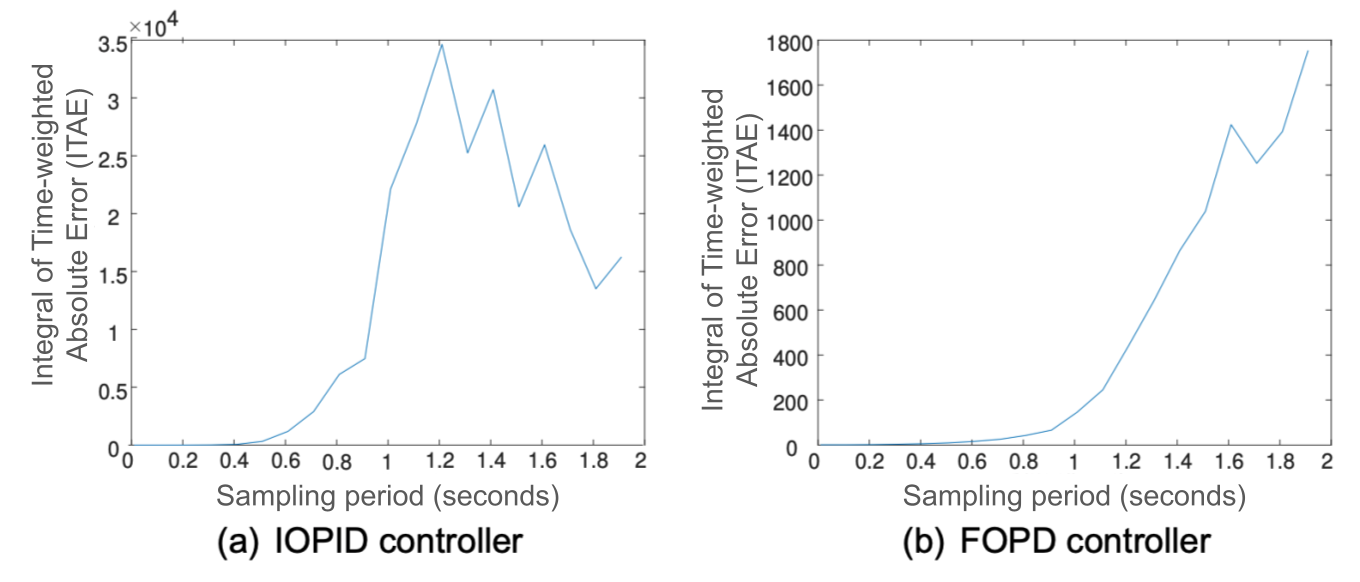
Integral of Time-Weighted Absolute Error (ITAE) vs. sampling period: FOPD error stays an order of magnitude lower.
THRUST II · EMBEDDED MECHATRONICS & HUMAN-MACHINE INTERFACE 18 / 26

PX4–Odroid Hardware Architecture & Live Browser HSV Tuner
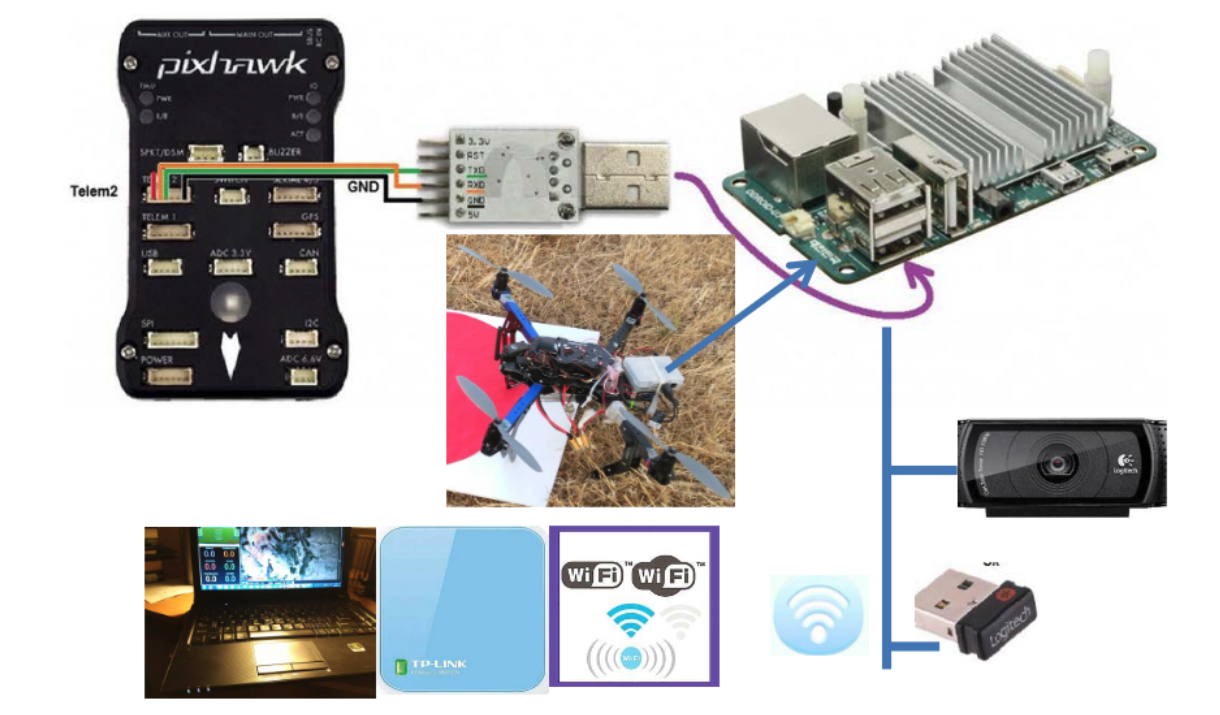
Quadrotor platform with Pixhawk/PX4, Odroid Linux computer & camera.
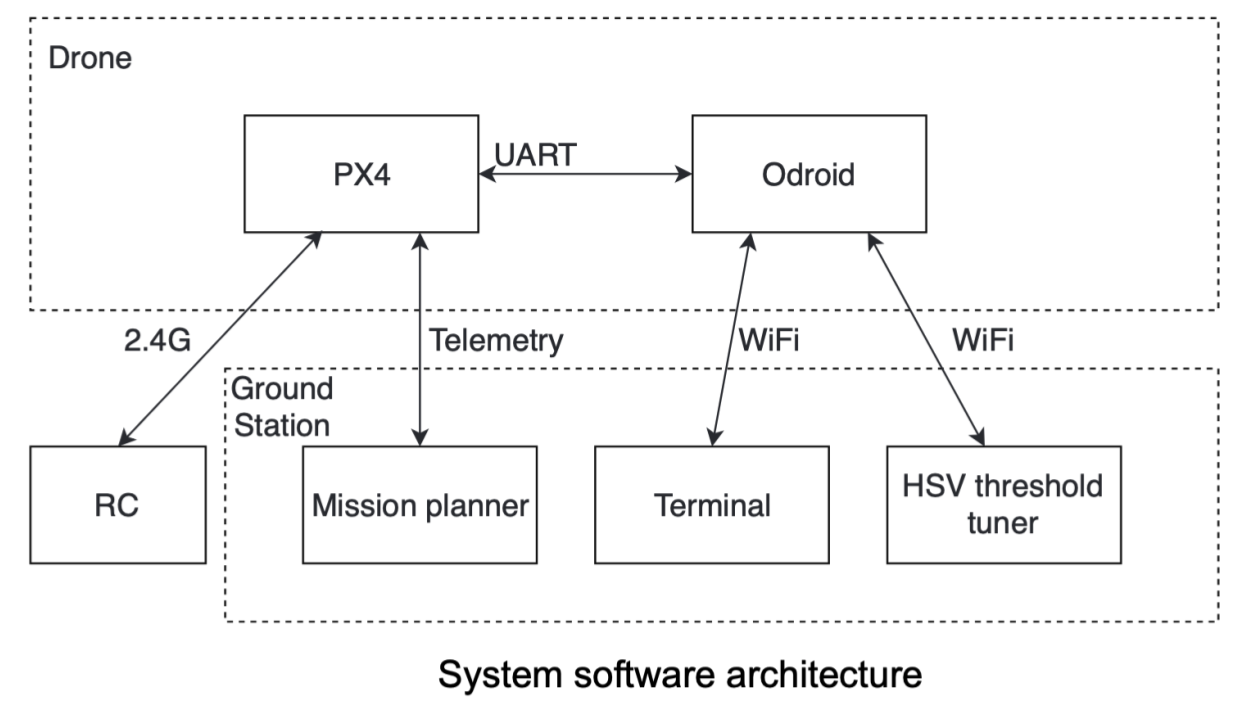
System HMI: PX4 ↔ UART ↔ Odroid ↔ RC, Mission Planner & WiFi Web GUI.
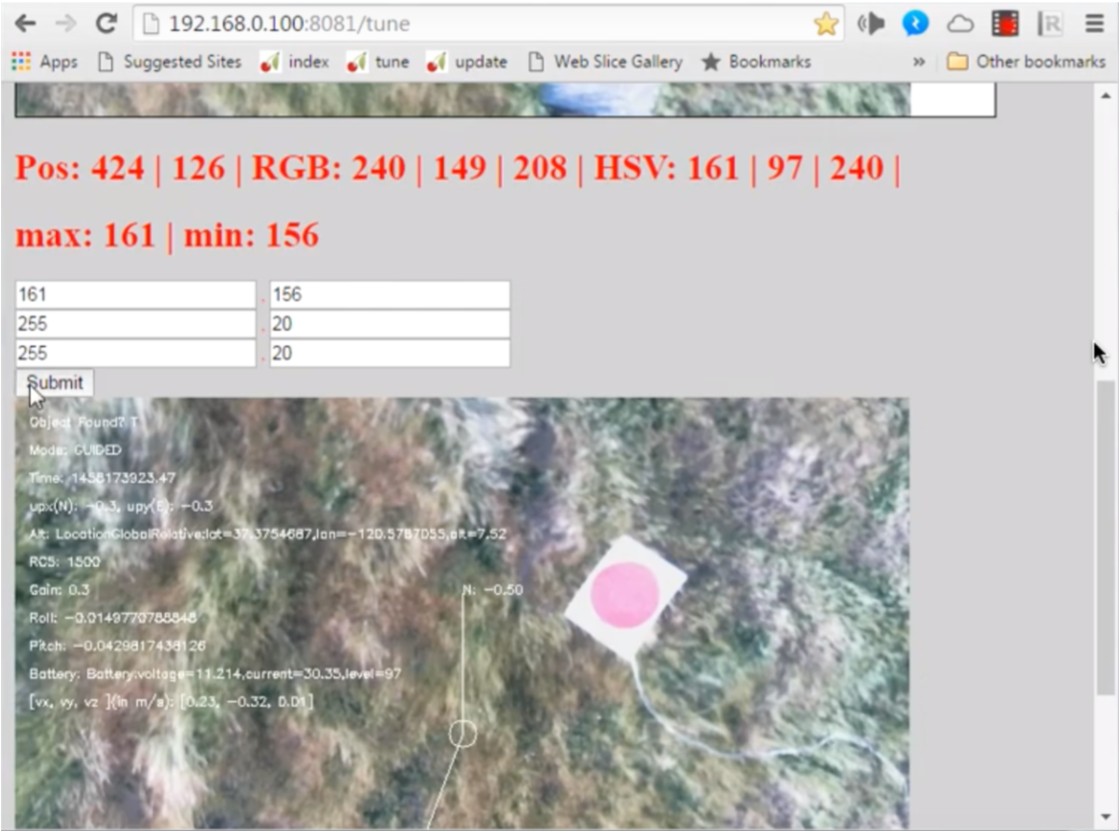
Onboard HTTP GUI (:8081/tune) for real-time outdoor HSV calibration.
THRUST II · OUTDOOR FLIGHT VALIDATION & CAVE MAPPING 19 / 26

20% Tighter Outdoor Hovering Precision & Live Flight Video
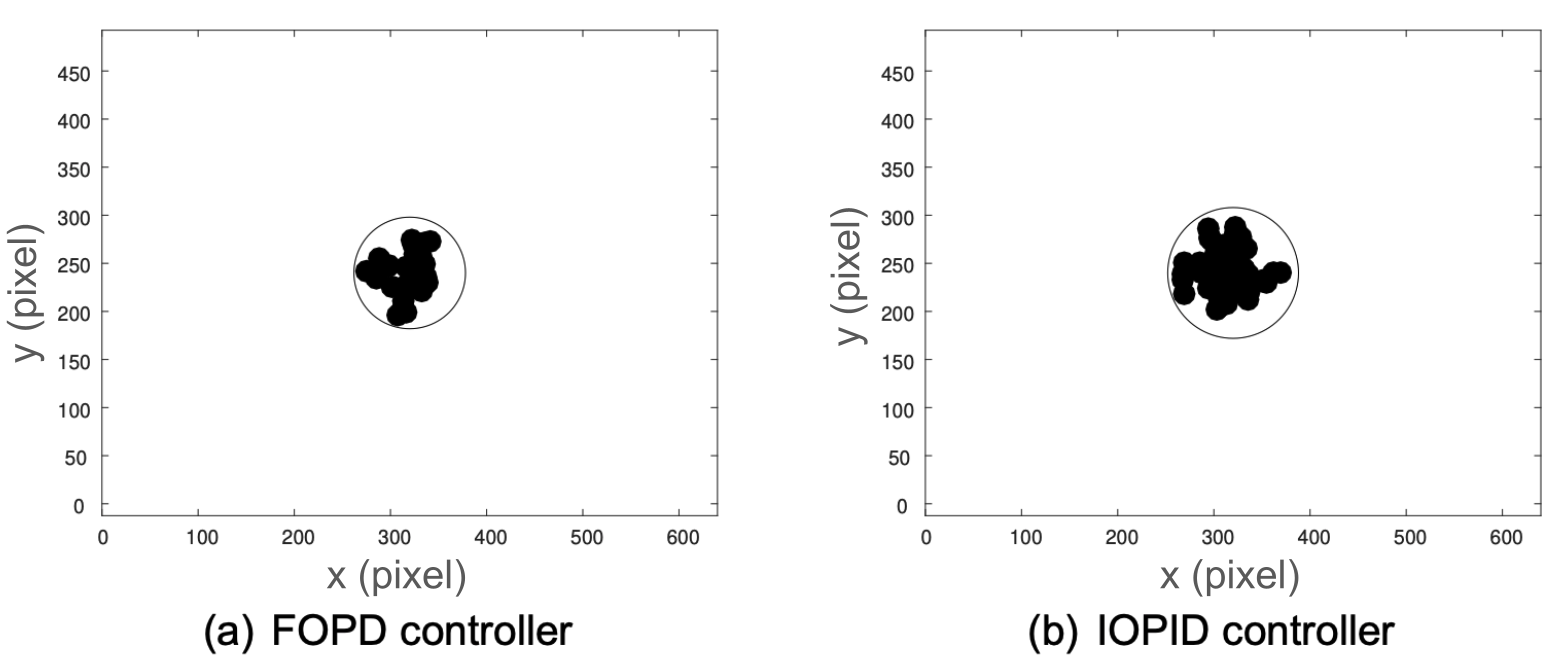
Outdoor flight pixel-error scatter: (a) FOPD achieves 20% tighter target hold than (b) IOPID.
Outdoor guided-mode visual servoing flight test & live ground-station telemetry.
Outdoor guided-mode visual servoing flight test & live ground-station telemetry. · YouTube ↗

Field Extension — SmartCaveDrone (ICUAS 2017): Applied GPS-denied UAV autonomy to 3D archaeological cave mapping as robotic co-archaeologists.

THRUST III · CLIMBING ROBOTICS, 3D NDT & 2025–2026 SENSOR PODS 20 / 26

Wall-Climbing Defect Analytics & Synchronized 3D LiDAR-Camera Systems

Updated from 2024 preprints to IEEE T-ASE 2025 / IROS 2025, CVPRW 2026, IEEE OJ-ITS 2026, and NYSDOT / UMD cyber-physical deployments.

IEEE T-ASE 2025

Selected for IEEE IROS 2025

90.1% vs. 72.9%

NYSDOT I-95 3D Crossing Recovery

0.37 → 1.00 PACO

Roadside V2I Occlusion Resolution

61.9 h · n = 180

Continuous Corridor & Safety Audits

THRUST III · ROBOT-TO-CLOUD MECHATRONIC WORKFLOW 21 / 26

Climbing-Robot Inspection, iPadOS Control & Serverless Cloud Engine

Bridging Wall-Climbing Hardware to Automated Cloud NDT

  • 42% of U.S. bridges are 50+ years old; concrete piers and seawalls exhibit dense cracking, spalling, and subsurface delamination.
  • GWCR Climbing Robot + iPad App: Developed an iOS/iPadOS TestFlight operator app logging synchronized RGB + Depth + Gravity vectors and GIS asset pins.
  • Serverless AWS Pipeline: API Gateway + Amplify S3 + 4 chained AWS Lambda functions automating InspectionNet CNN inference, mask overlay, and dimension extraction.
  • Distinct Lineage: Conducted at CCNY Robotics Lab (Feng, Shang, et al., Prof. Jizhong Xiao) — independent from Missouri S&T BIRDS.
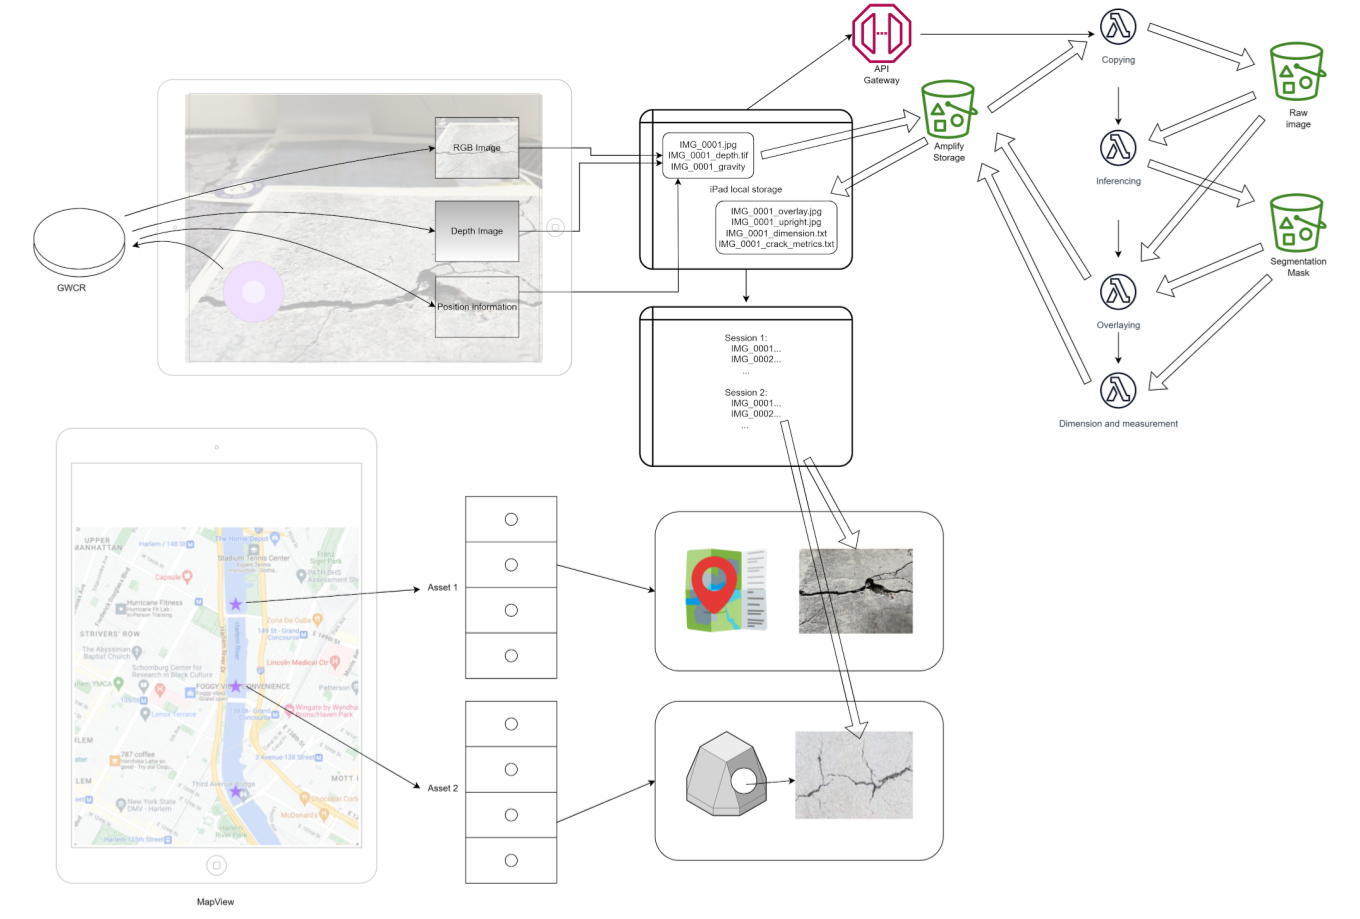
End-to-end architecture: GWCR climbing robot → iPad local/MapView app → AWS API Gateway, S3 & 4× Lambda stages.
THRUST III · 2025 MILESTONE — IEEE T-ASE & IEEE IROS 22 / 26

2D-to-3D Defect Registration & Metric Crack Skeletonization
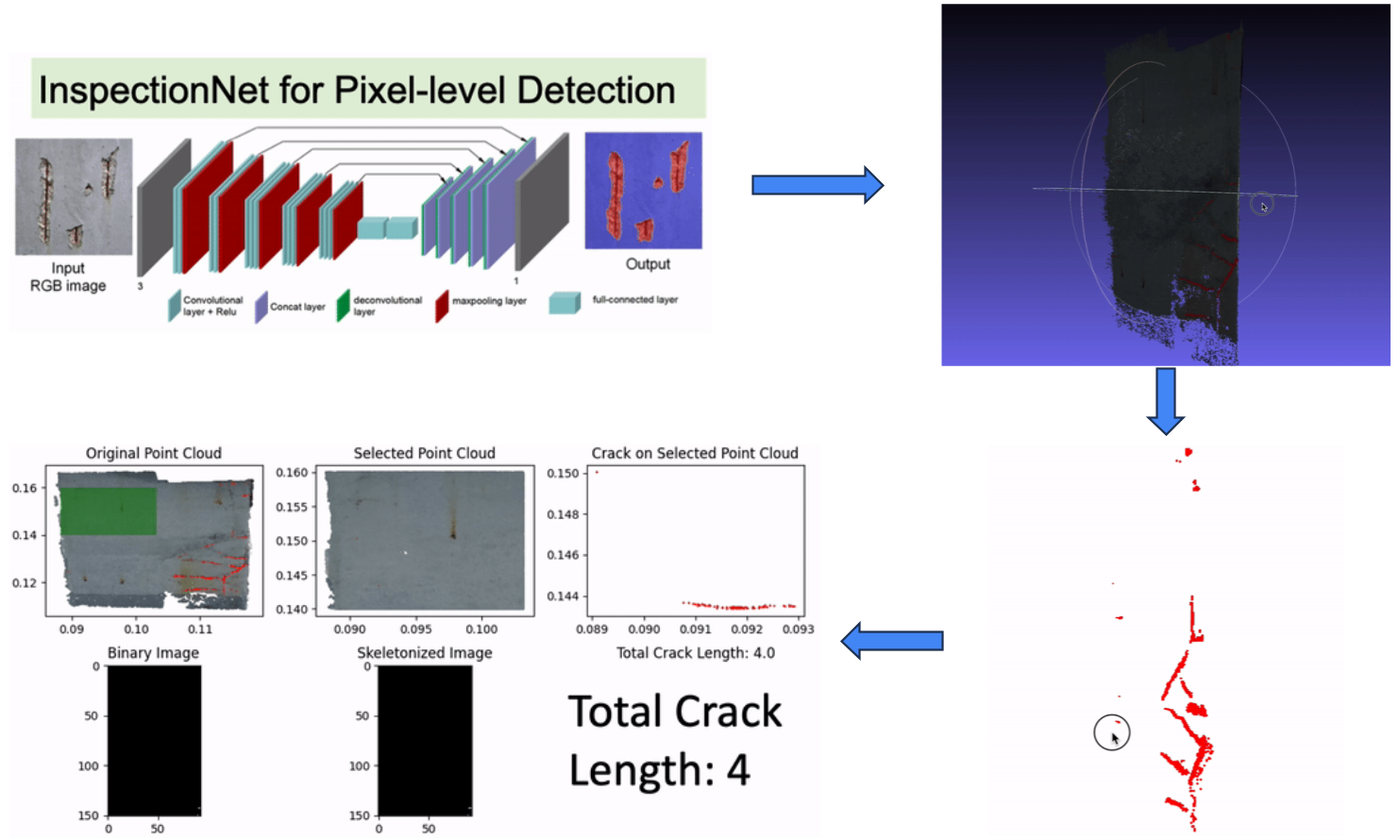
2D CNN segmentation registered onto 3D WebODM SfM point cloud.
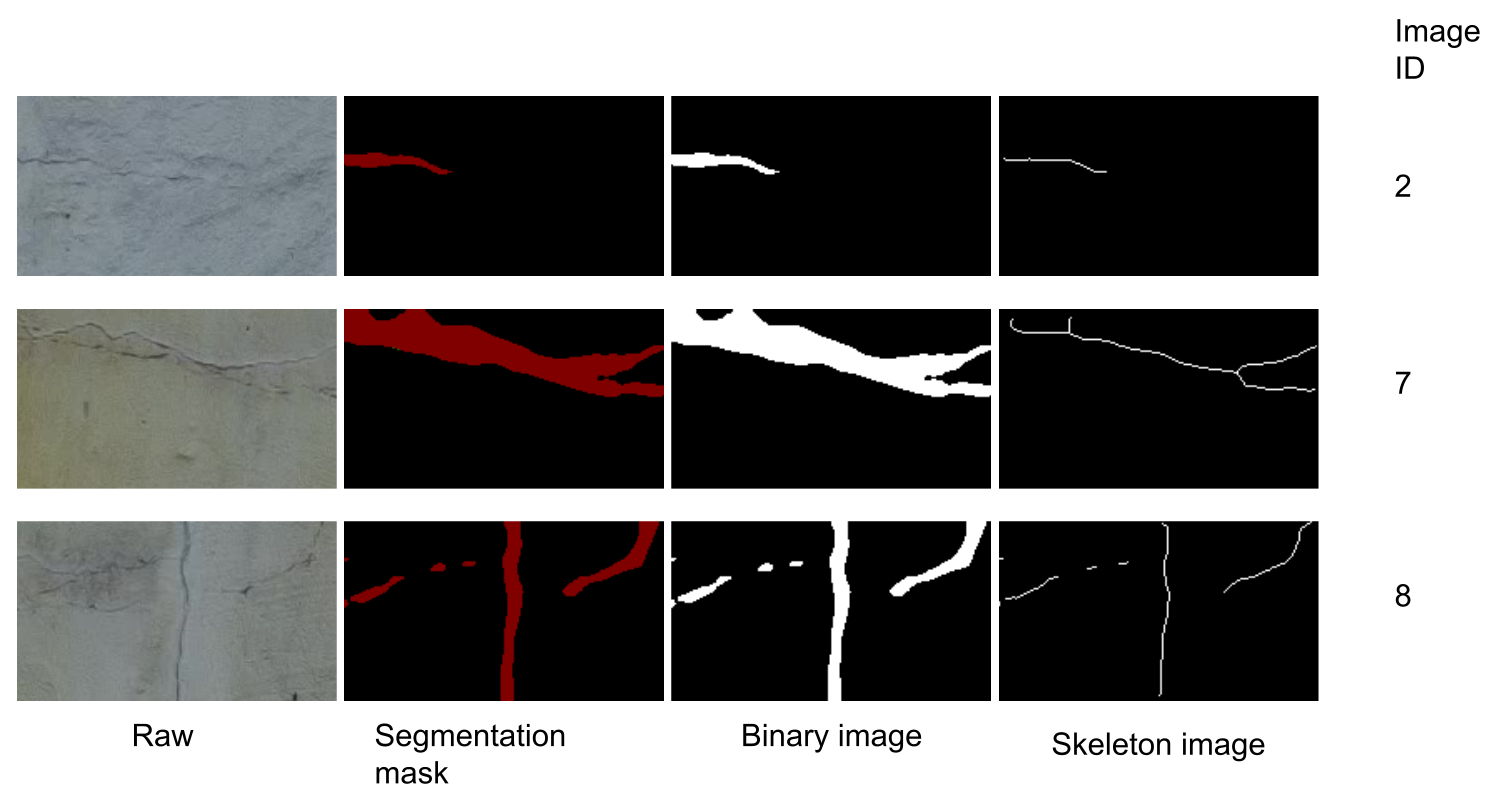
Raw surface → CNN mask → binary mask → 1-px medial-axis skeleton.
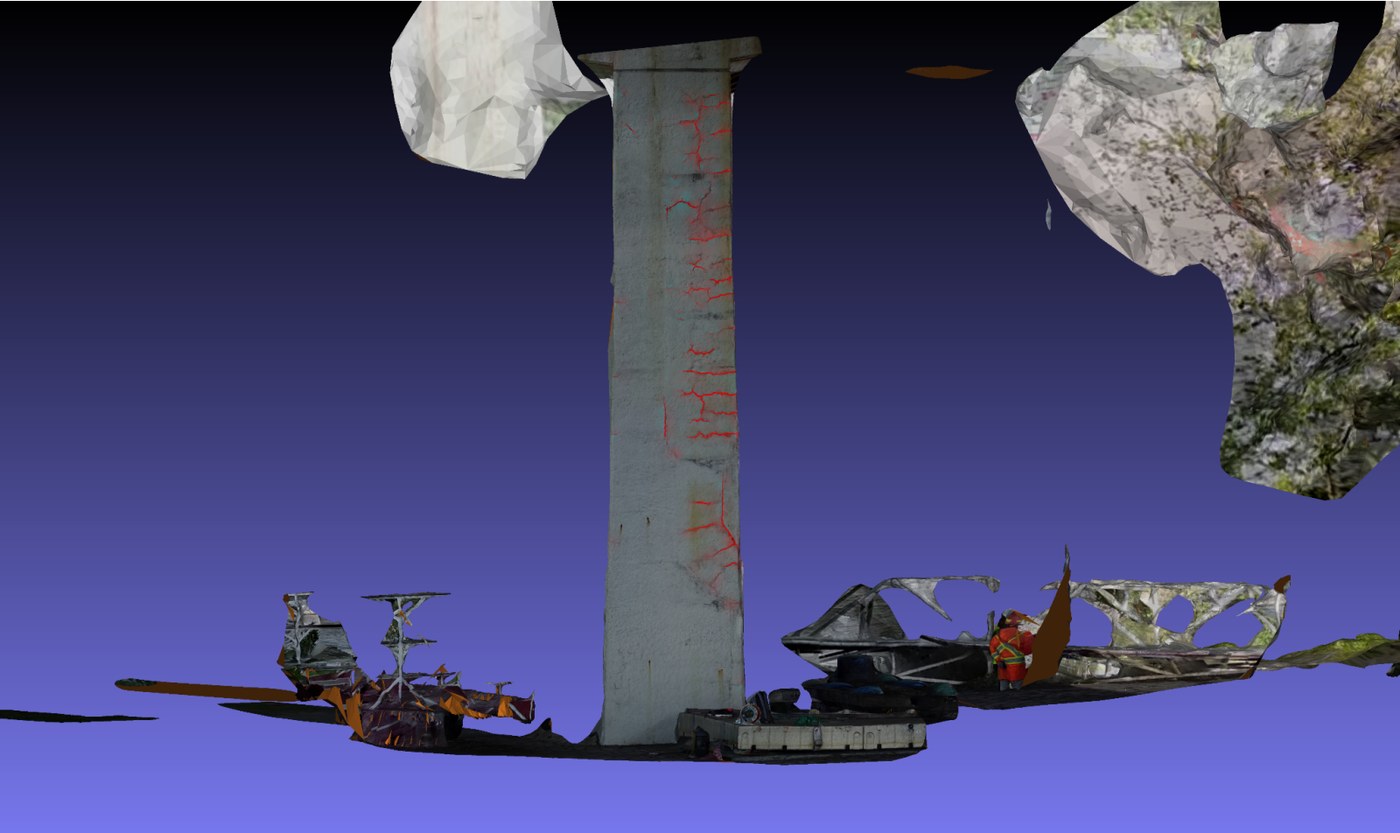
Full-scale concrete bridge column 3D reconstruction with localized defects.
THRUST III · 2025–2026 MULTI-SENSOR MECHATRONIC EXTENSION 23 / 26

Synchronized 3D LiDAR-Camera Pods, PACO & Cyber-Physical Twins
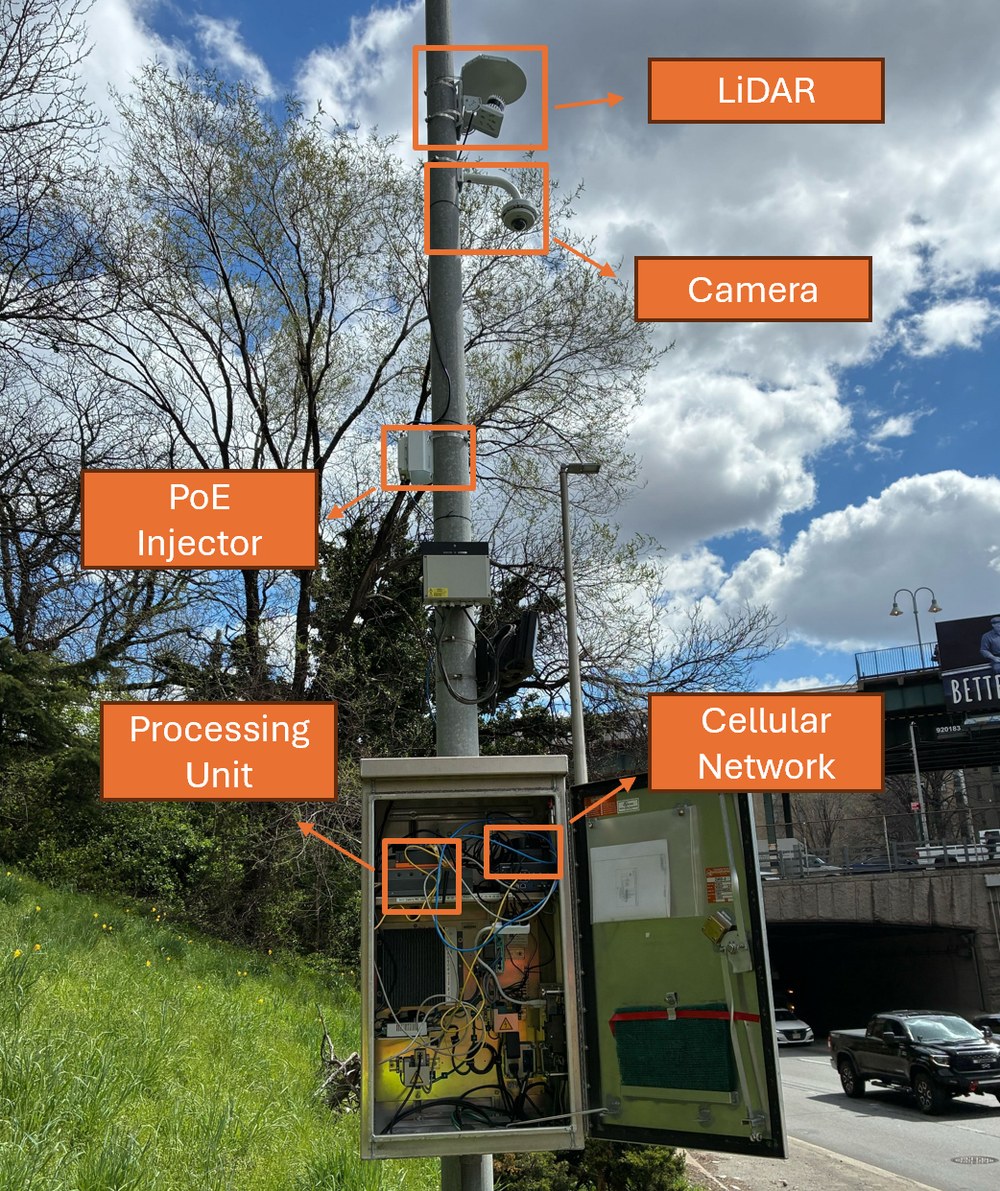
NYSDOT I-95 LiDAR+RGB pod: 90.1% vs. 72.9% recovery (61.9 h dataset).
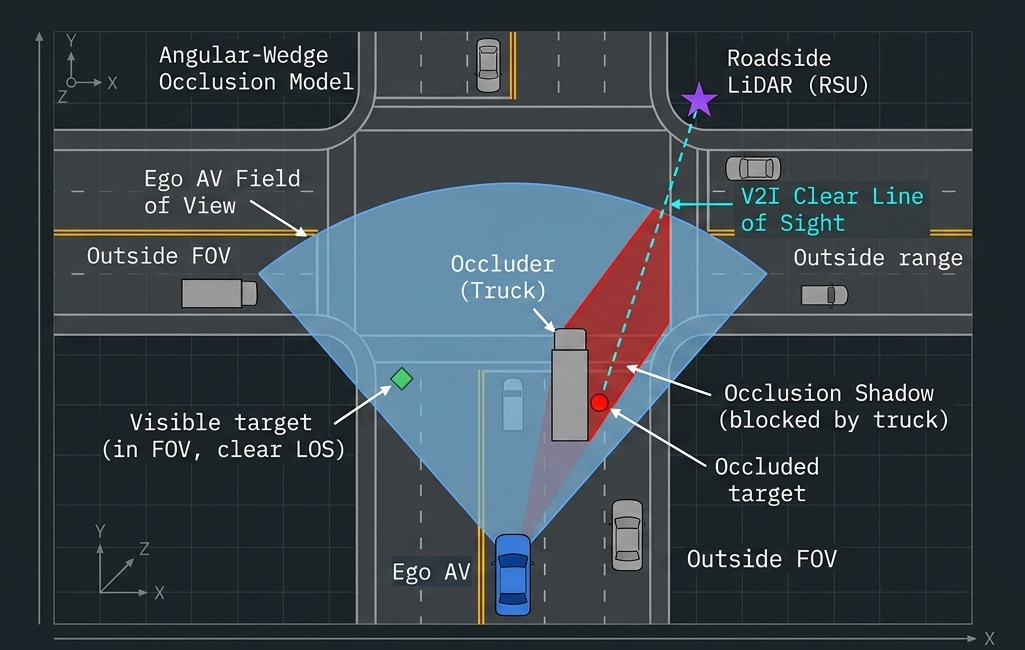
PACO occlusion physics: 0.37 ADAS → 0.61 AV → 1.00 V2I (CVPRW 2026).
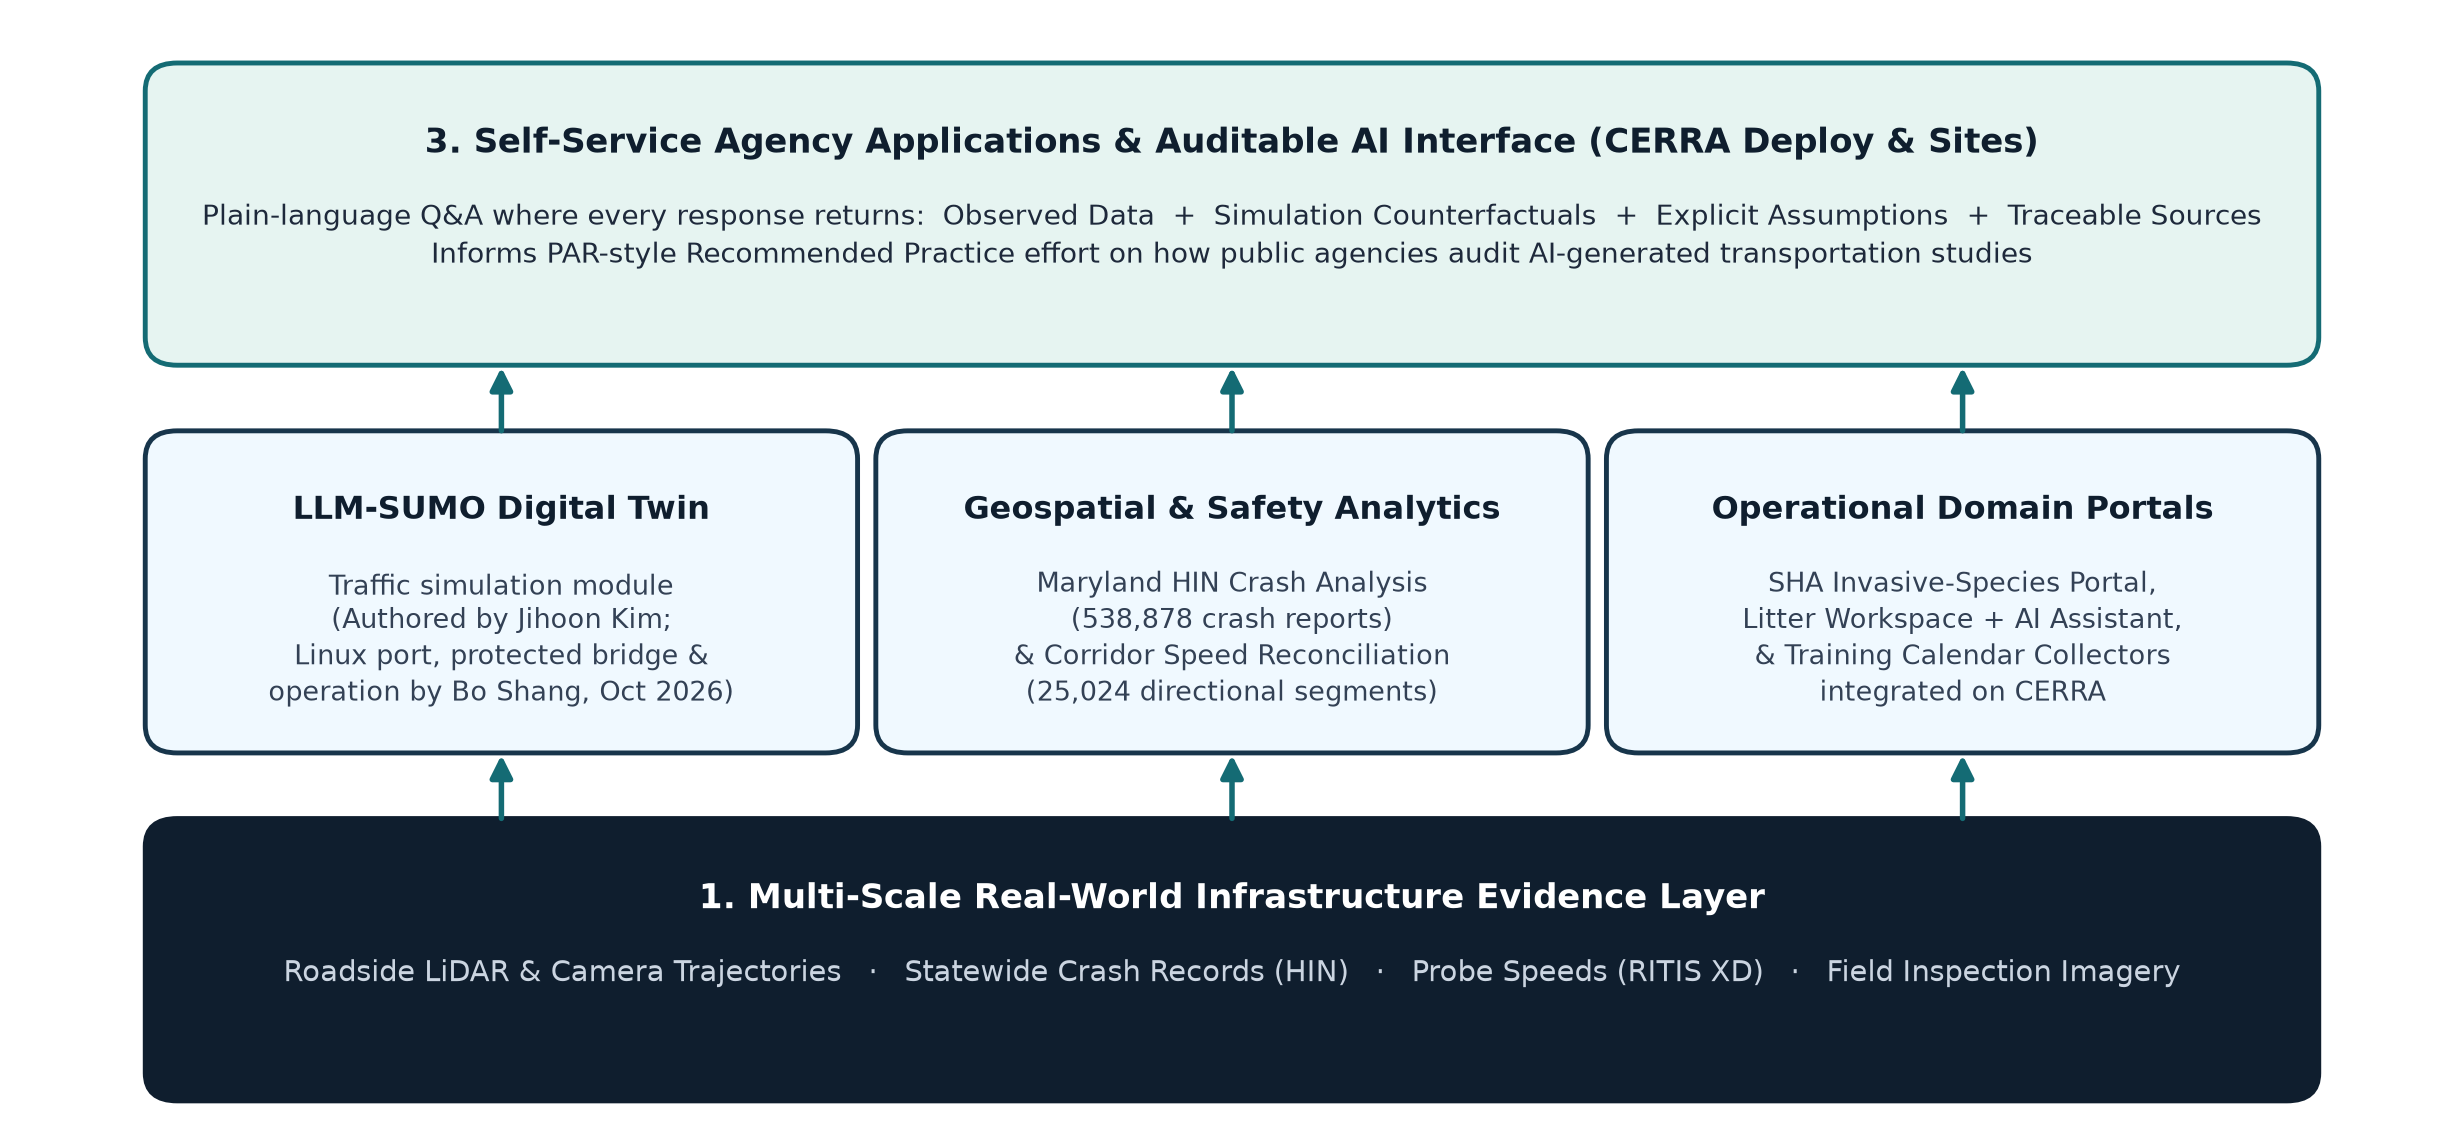
UMD CERRA geospatial AI & protected LLM-SUMO simulation bridge.
FUTURE VISION · 5-YEAR MECHATRONICS LAB AGENDA 24 / 26

Research Statement: Next-Generation Field Mechatronics Lab

Pillar 1 · Reconfigurable & Contact-Rich Field Robots

  • Next-gen aerial-perching, magnetic/vortex climbing, and multi-modal rolling mechanisms.
  • Compliant force/impedance end-effectors for contact acoustic, ultrasonic, and eddy-current NDT.
  • On-the-fly adaptive / liquid neural policies running on low-power edge NPUs.

Pillar 2 · Delay- & Uncertainty-Certified Control

  • Fractional-order and physics-informed nonlinear control with provable delay & gain margins.
  • Safe handoff between foundation-model high-level planners and deterministic real-time MCU/RTOS servo loops.
  • Wind-gust & contact-transition disturbance rejection.

Pillar 3 · Synchronized Sensor Pods & HIL Twins

  • Open-hardware sub-millisecond synchronized 3D LiDAR + RGB + thermal + acoustic mechatronic pods.
  • Hardware-in-the-loop (HIL) validation benches coupling physical actuators/sensors with calibrated digital twins.
  • Turnkey field partnerships with DOTs, utilities & manufacturing.

Synthesis: Lab Mission: Advance the science of coupled mechanism-sensor-control co-design so autonomous robots operate safely, enduringly, and auditably in harsh real-world environments.

EDUCATION & SPONSORSHIP · CURRICULUM & FUNDING STRATEGY 25 / 26

Mechatronics Studio Teaching & External Funding Roadmap

Mechatronics Curriculum & Student Hardware Studio

  • Undergraduate Core: Mechatronics System Design, Sensors, Actuators & Microcontrollers, Electric Circuits & Electro-Mechanics, Feedback Control Systems.
  • Senior / Graduate Electives: Introduction to Robotics, Mechanics & Control, Autonomous Aerial & Climbing Robots, Fractional-Order & Robust Digital Control.
  • Take-Home & Benchtop Kits: Modular MCU + encoder motor + IMU + RGB-D kits taking students from PCB/wiring and C firmware to Simulink system ID and ROS 2.
  • Undergraduate Research Pipeline: Direct integration of capstone teams into bridge/drone/sensor-pod field deployments.

Targeted External Funding & Cross-Disciplinary Links

  • NSF Engineering & CISE: CMMI (Dynamics, Control & Systems Diagnostics; Foundational Research in Robotics — FRR), CNS (Cyber-Physical Systems — CPS), and NSF CAREER (Years 2–3).
  • Infrastructure & Energy Agencies: USDOT UTCs, State DOT research boards (building on NYSDOT, NYC DOT & INSPIRE track record), DOE infrastructure resilience.
  • Defense & Aerospace: ONR / ARL / AFOSR (GPS-denied autonomous perching, compact multi-sensor autonomy under compute/comms constraints).
  • Departmental Synergies: Bridges Mechanical, Electrical/Computer, Civil, and Aerospace Engineering.
SELECTED MECHATRONICS, ROBOTICS & CONTROL OUTPUTS · THANK YOU 26 / 26

Selected Publications, Granted Patent & Contact

Key Patents & Peer-Reviewed Publications (Updated Through 2026)

  • [US Patent 12,296,994 B2, 2025] G. Chen, A. Reven, B. Shang, Z. Shi, L. Li. Unmanned Vehicle Having Flight Configuration and Surface Traverse Configuration · ASCE 2025 Charles Pankow Award.
  • [IEEE T-ASE 2025 · IROS 2025] J. Feng, B. Shang, E. Hoxha, C. Hernández, Y. He, W. Wang, J. Xiao. Robotic Inspection and Data Analytics to Localize and Visualize the Structural Defects of Concrete Infrastructure, vol. 22, pp. 22324–22336.
  • [CVPRW DriveX 2026 & IEEE OJ-ITS 2026] Proactive Roadside 3D LiDAR Urban Safety Auditing (n = 180) & Citywide Freight Activity Sensing.
  • [IEEE ISAS 2023] J. Li, B. Shang, I. Jayawardana, G. Chen. Hardware-in-the-Loop and Digital Twin Enabled Autonomous Robotics-Assisted Environment Inspection.
  • [Nonlinear Dynamics 2019] B. Shang, J. Liu, Y. Zhang, C. Wu, Y.Q. Chen. Fractional Order Flight Control of Quadrotor UAS on Vision-Based Precision Hovering with Larger Sampling Period.
  • [ICUAS 2016 & 2017 · ASME IDETC 2017] Fractional-Order Visual Servoing, Maximum Sampling-Period Analysis, & SmartCaveDrone 3D Cave Mapping.
Thank You & Questions! · Bo Shang, Ph.D. · bshang@umd.edu · https://cnpcshangbo.github.io/ · Interactive Demos: /portfolio/