DEPLOYED ROBOTICS · 3D PERCEPTION · GEOSPATIAL AI

Physical AI Built for Real Infrastructure

From patented flying-and-clamping bridge robots and 3D crack-mapping climbers to 61.9-hour highway LiDAR corridors and agency-facing traffic simulation platforms — explore hardware architectures, live interactive simulators, and real experimental footage.

U.S. Patent 12,296,994 B2 ASCE 2025 Charles Pankow Award 7 Playable Experimental Videos NYSDOT · NYC DOT · USDOT INSPIRE · UMD MTI
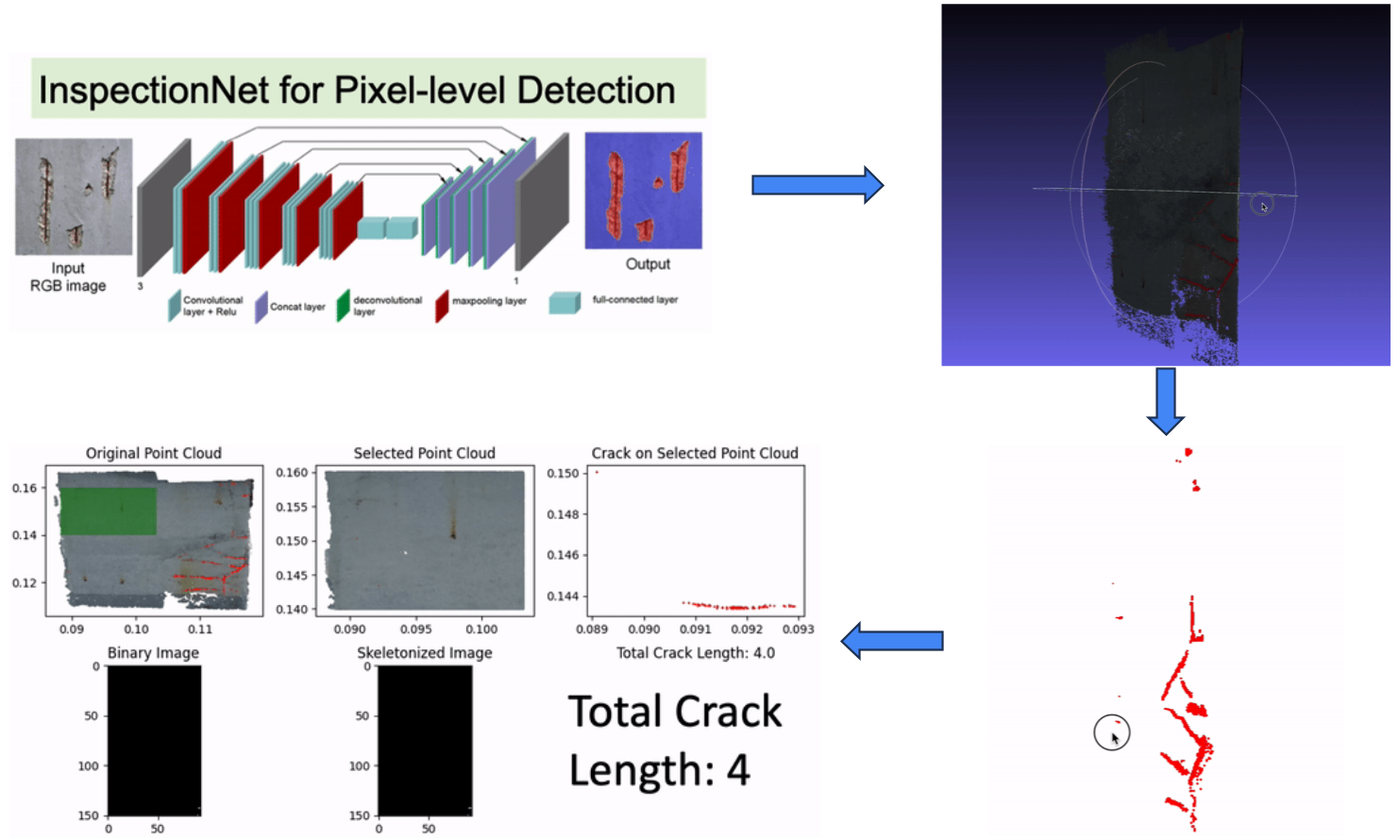
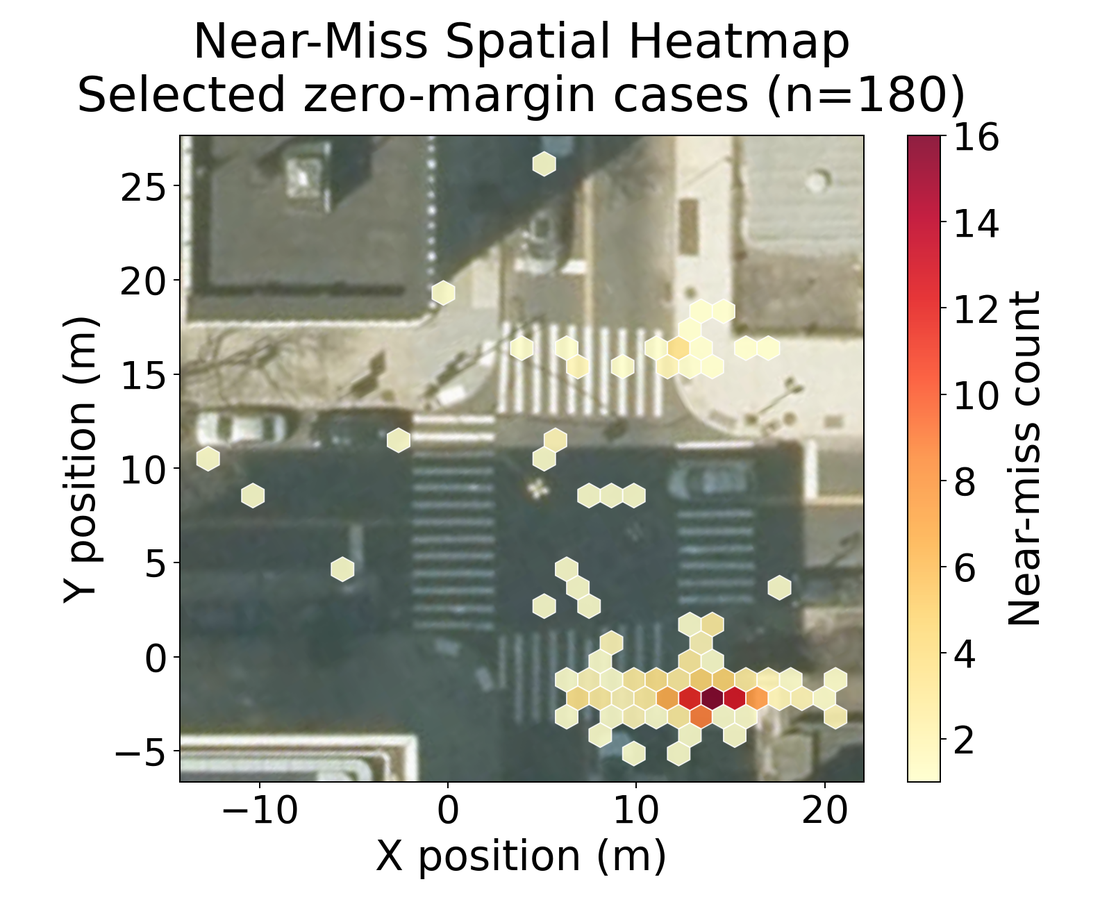
MICRO · ROBOTICS BIRDS + Climbers 1.3 s Girder Clamping 3D Crack Skeletonization PATENTED UAS MESO · V2I LIDAR PACO Safety Audit 0.37 ADAS → 1.00 V2I 180 Near-Misses Audited CVPRW 2026 MACRO · CORRIDOR InfraLiDAR-Eval 61.9 h Continuous 3D 90.1% I-95 Recovery NYSDOT DEPLOY UNIFIED DECISION LAYER · CERRA & LLM-SUMO Auditable Infrastructure Intelligence Observed Telemetry + Calibrated Simulation + Explicit Assumptions
MULTI-SCALE ARCHITECTURE MICRO → MESO → MACRO → CITY
US 12,296,994 Granted Robotics Patent Hybrid flight & girder-traversing vehicle + ASCE 2025 Pankow Award
7 Videos + 3 Sims Interactive Demos Inline Real hardware flight/clamping footage & live telemetry sandboxes
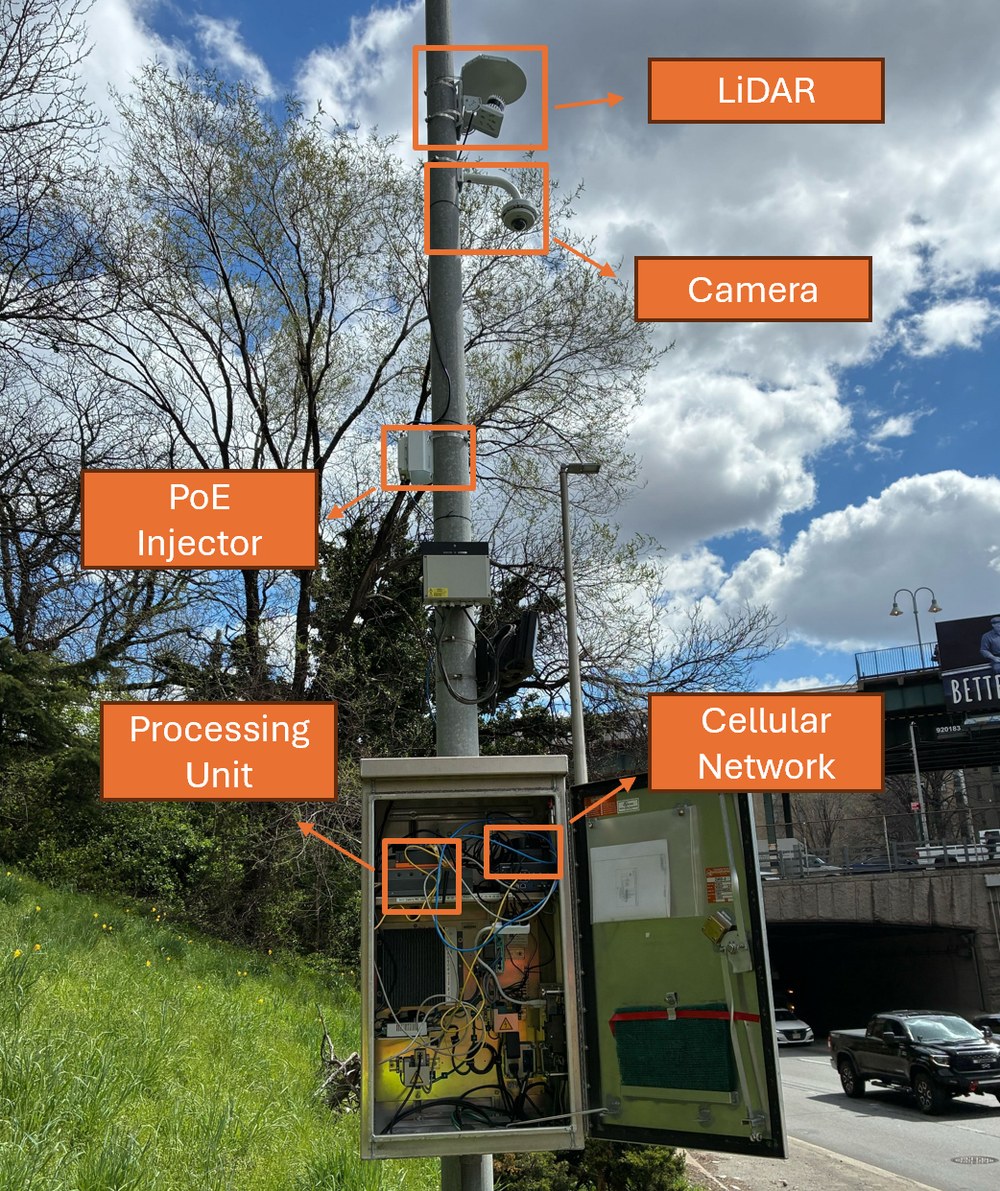
61.9 Hours Field Roadside 3D LiDAR 743 continuous sessions across NYC & NYSDOT I-95 corridors
0.37 → 1.00 PACO Observability Gain Closing dynamic truck occlusion shadows via elevated V2I LiDAR

PRODUCT & SYSTEM CATALOG

Select a Scale or Explore All 7 Systems

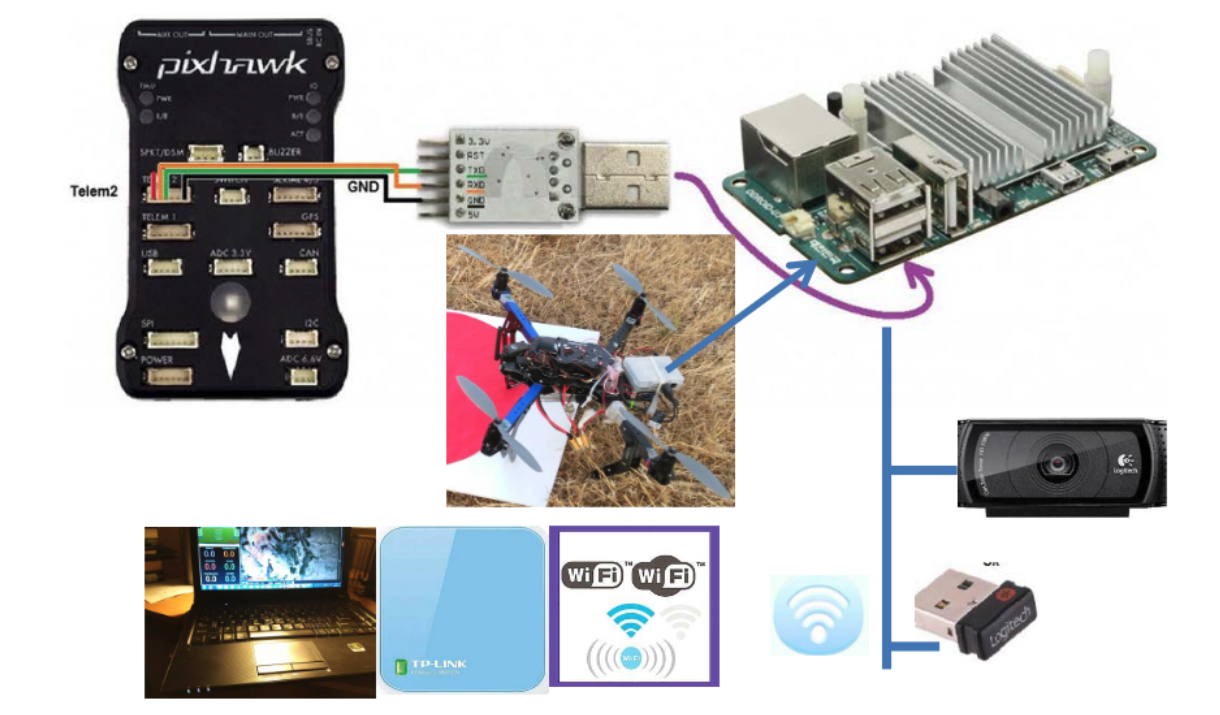
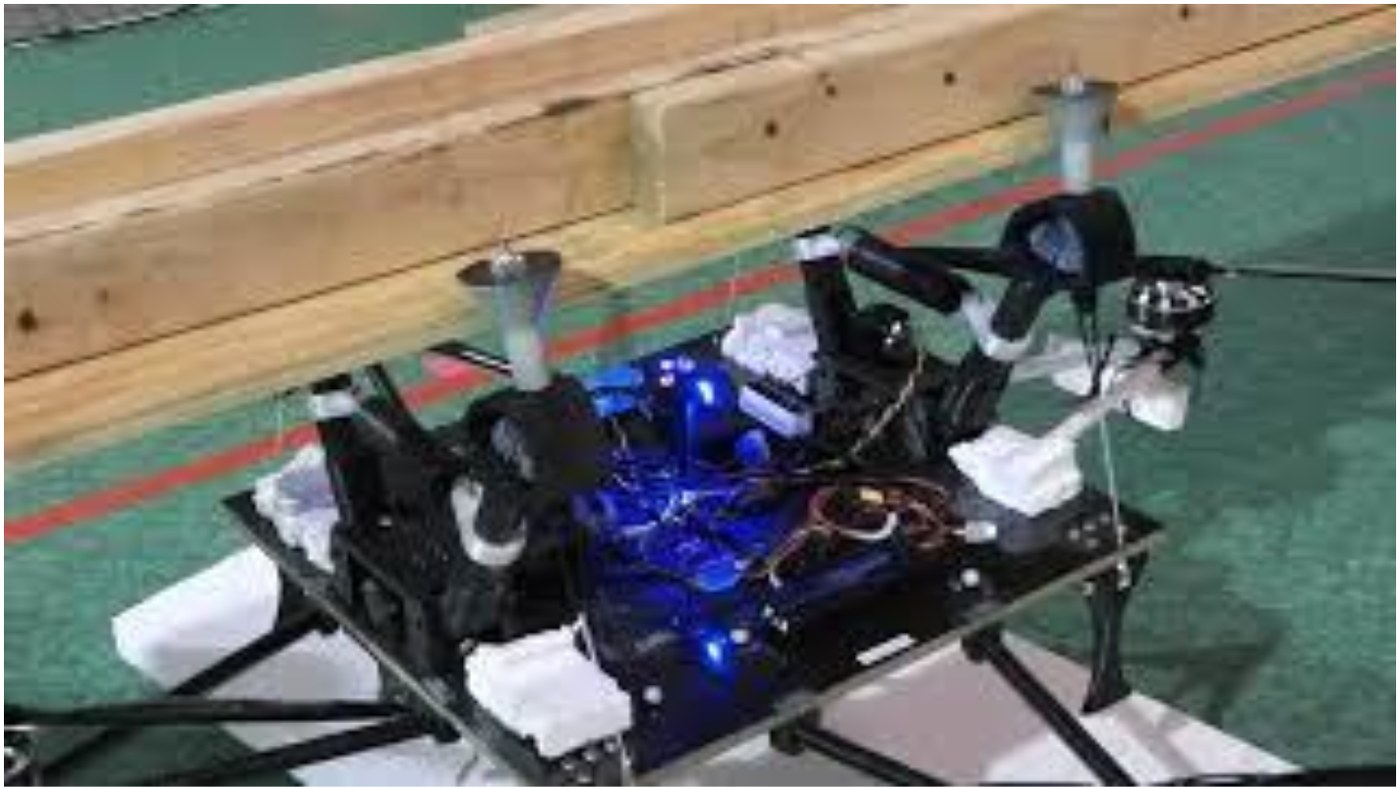
BIRDS hybrid quadrotor and steel girder traversing bridge inspection robot
6 Experimental Videos + Sim US Patent 12,296,994 · Pankow Award
MICRO SCALE · HYBRID AERIAL-CLIMBING ROBOTICS

BIRDS: Bridge Inspection Robot Deployment System

Multi-rotor flight consumes massive power while hovering in under-bridge wind gusts where GPS fails. BIRDS flies up beneath steel I-girders, locks onto the bottom flange via onboard NVIDIA Jetson RGB-D vision, clamps autonomously in 1.3 seconds, powers down its rotors, and rolls along the span for continuous multi-camera NDT inspection.

1.3 s Autonomous Clamping 0 W Rotor Power While Rolling 6 Inline Lab & Flight Videos
ROSNVIDIA JetsonRGB-D VisionPID / Fractional ControliOS Telemetry AppEmbedded Linux
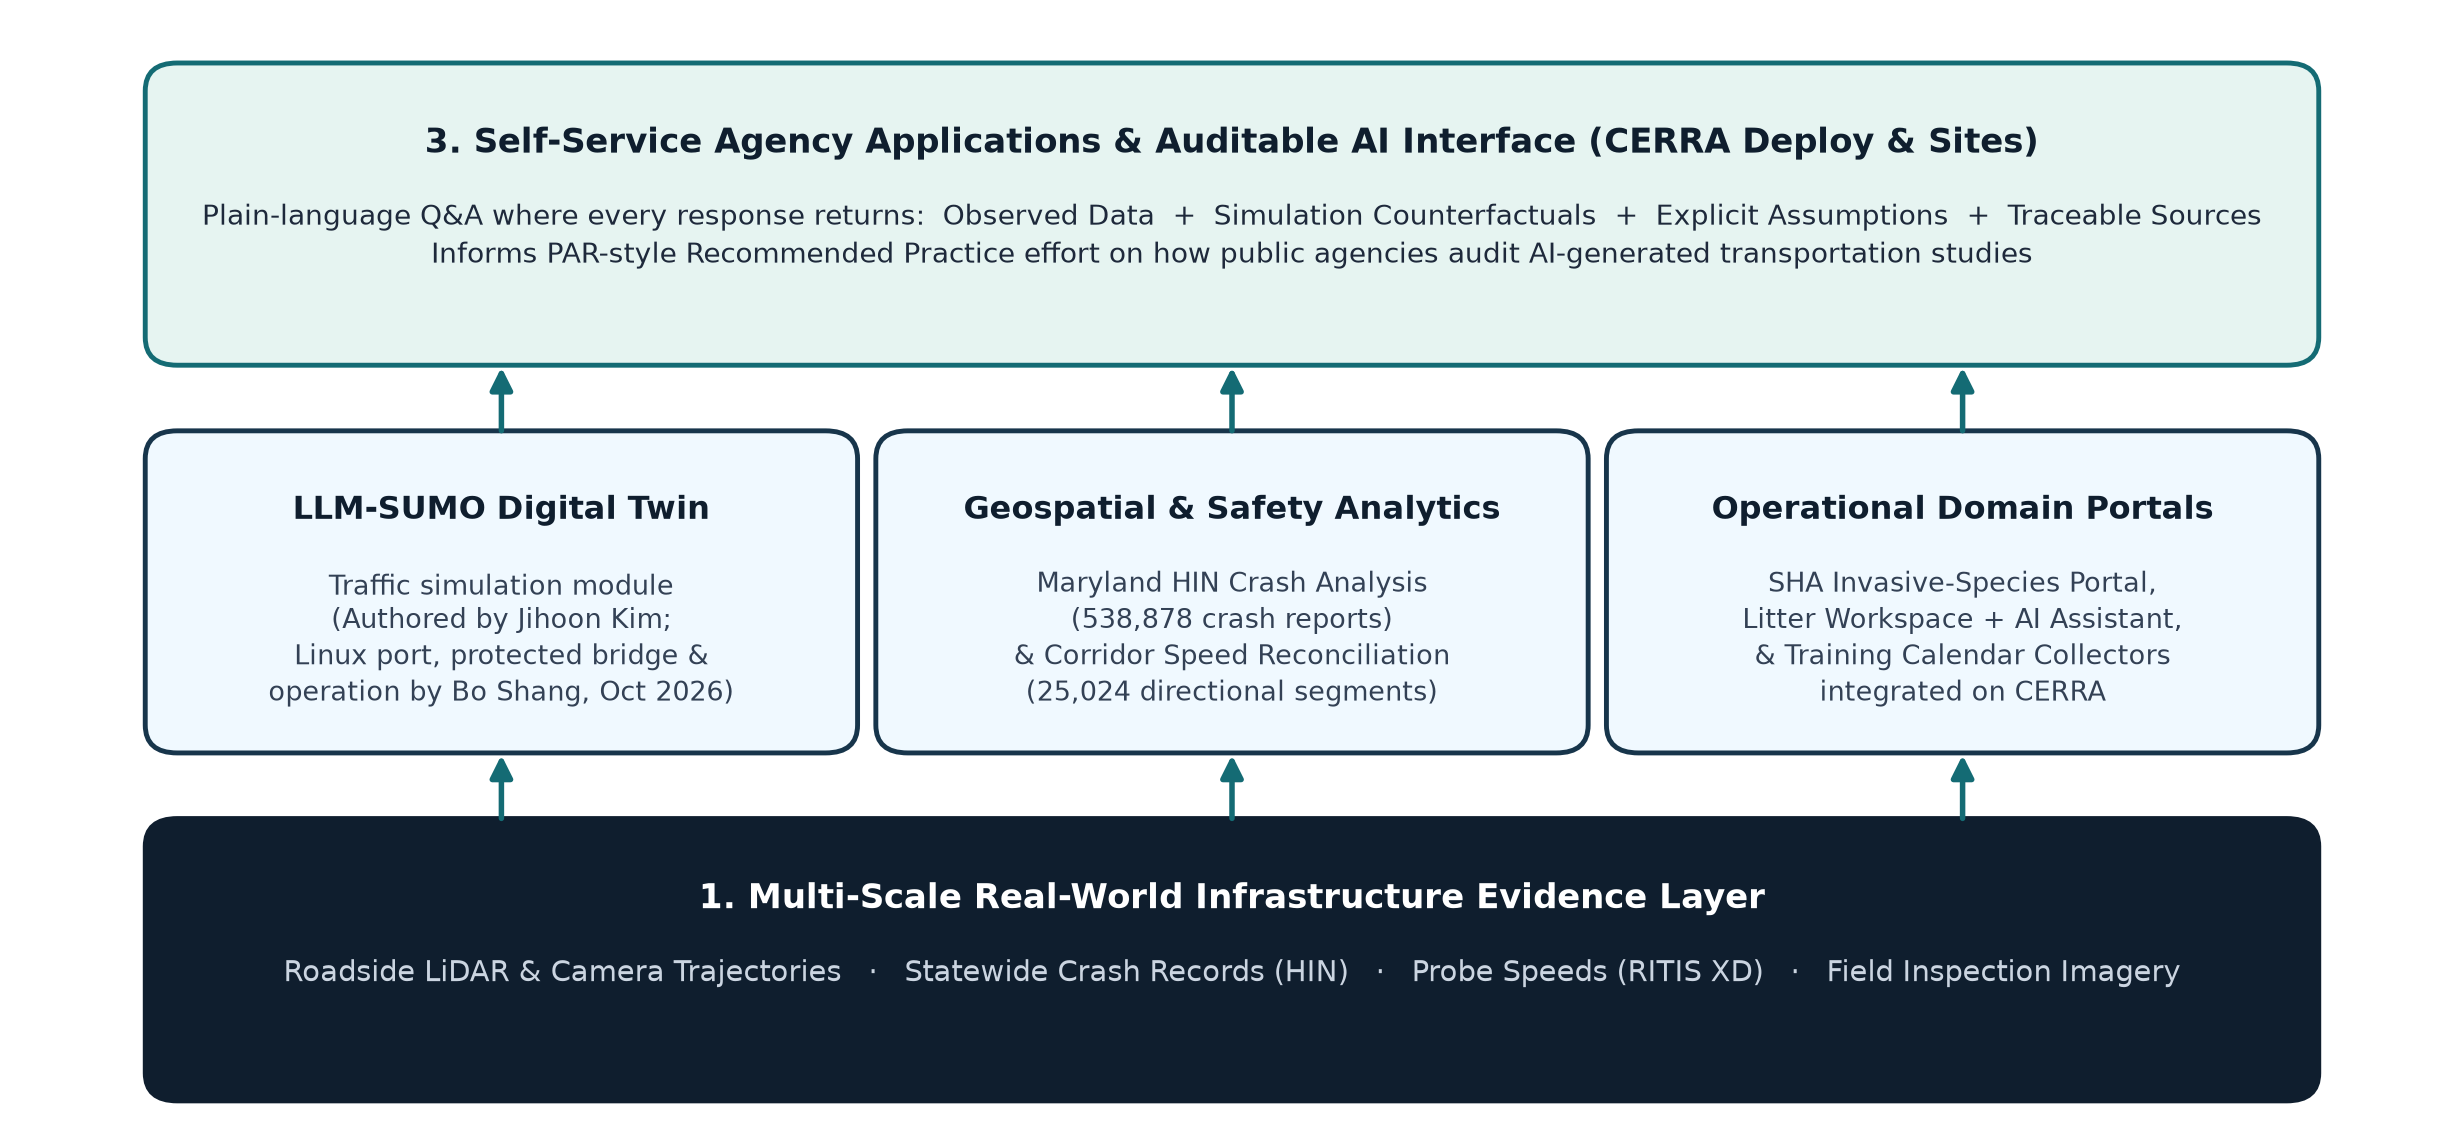
CERRA geospatial AI architecture and LLM-SUMO traffic simulation workflow
Live at cerra.cloud UMD M-TRAIL · IBM Heron
CITY SCALE · GEOSPATIAL AI & SIMULATION

CERRA Geospatial AI Platform & LLM-SUMO Digital Twin

Agency-facing spatiotemporal analytics platform pairing observed corridor telemetry with a protected LLM-SUMO traffic-simulation bridge, explicit assumption audit logs, and quantum-hardware VRP benchmarking.

4-Part Auditable Copilot IBM Heron VRP Validated
SUMOLLM Tool BridgeLinux ContainersGeospatial AnalyticsQAOA / VRP
academic.hopeembark.org · Claude + Qwen/Ollama BILINGUAL AI COPILOT EN / 中文 Research Synthesis Citation-grounded · Guardrailed 34-COURSE CURRICULUM Recorded lessons + live labs MODEL ROUTER • Claude API (Reasoning) • Self-Hosted Qwen / Ollama • Multi-subdomain prod deploy KNOWLEDGE GRAPH · 34 NODES DP BFS DAG TRIE HEAP UF 102 Interactive Progression Units
Live 0-to-1 AI Product Claude + Qwen/Ollama
FULL-STACK AI PRODUCT · 0-TO-1 DEPLOYMENT

ScholarMind AI / Merit Point Academy

Independently architected and shipped bilingual AI learning & research platform combining Claude + self-hosted Qwen/Ollama agents, a 34-course library, and a 34-node / 102-unit interactive knowledge-graph engine.

34 Courses & Graph Nodes 102 Progression Units
Claude AgentsQwen / OllamaKnowledge GraphsBilingual UXProduction Web