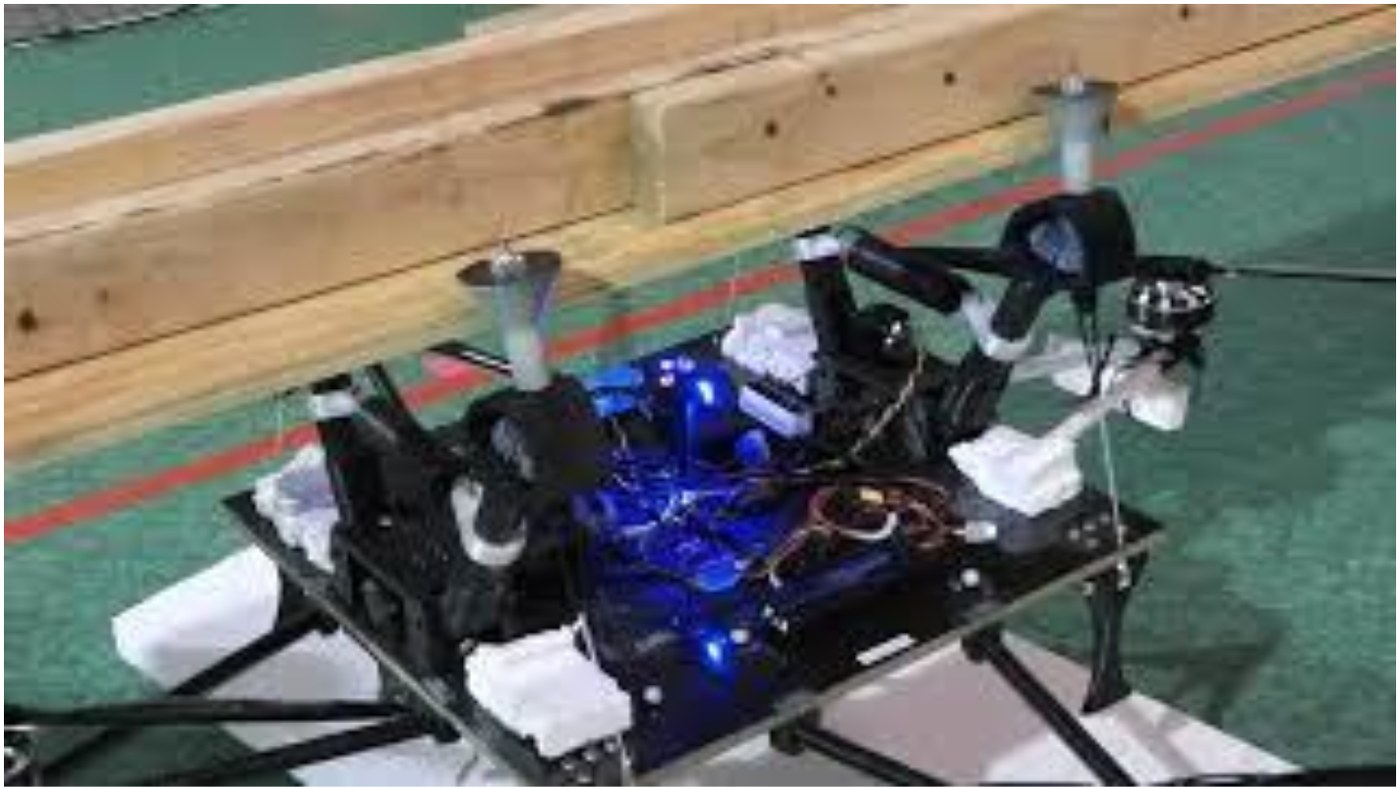
01 · SURFACE TRAVERSE MODE
Motorized Steel I-Girder Traversal After Clamping
Propellers powered off; motorized drive wheels carry the multi-sensor payload smoothly along the bottom flange of a steel I-girder.
Watch on YouTube ↗MICRO SCALE · U.S. PATENT 12,296,994 B2 · USDOT INSPIRE
Conventional inspection drones drain batteries in minutes while fighting under-bridge wind gusts without GPS. BIRDS flies up to a steel I-girder, locks onto the bottom flange via onboard NVIDIA Jetson RGB-D vision, clamps in 1.3 seconds, shuts off its rotors, and rolls smoothly along the bridge span.
EXPERIMENTAL FOOTAGE · CLICK ANY CARD TO PLAY INLINE
Every stage of the patented flight-to-girder transition was validated on physical hardware — from benchtop actuator response and RGB-D flange perception to flight perching and motorized steel I-girder traversal.
Propellers powered off; motorized drive wheels carry the multi-sensor payload smoothly along the bottom flange of a steel I-girder.
Watch on YouTube ↗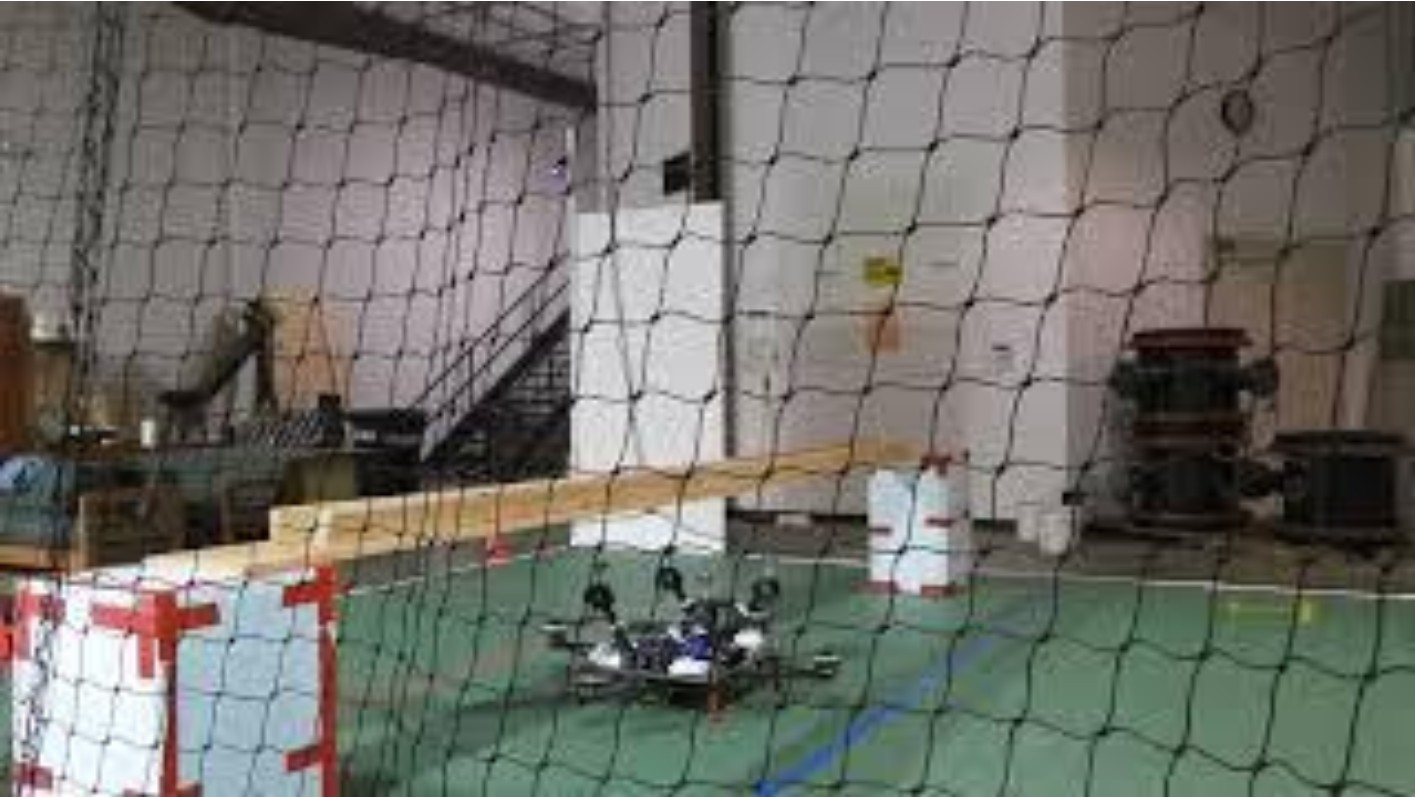
Indoor flight-arena test demonstrating upward approach, distance-triggered dual-arm clamping onto an overhead beam, and mode transition.
Watch on YouTube ↗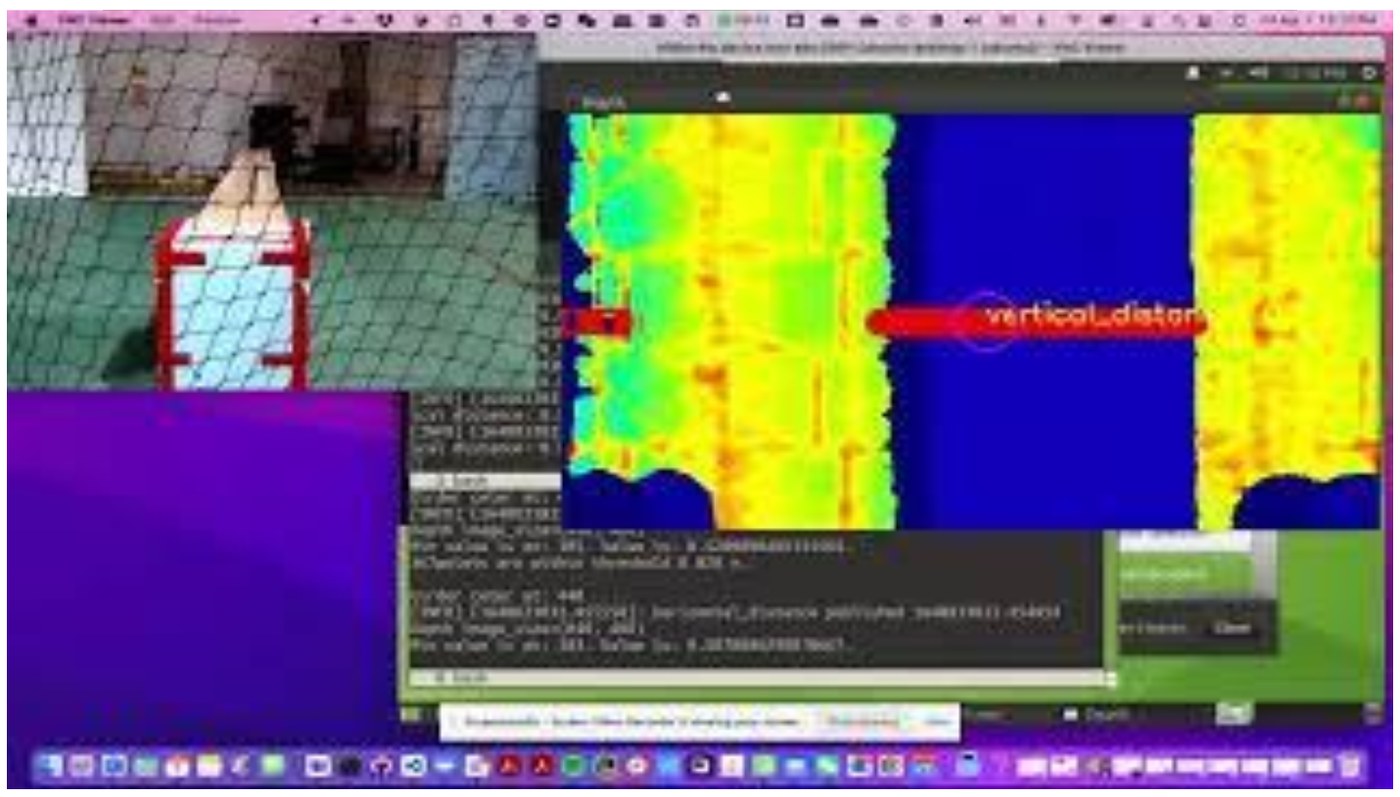
Real-time segmentation tracking the girder centerline (pink marker), boundary inliers (red), and metric camera-to-flange distance.
Watch on YouTube ↗
ROS perception-to-actuation loop firing immediate clamping closure the instant vertical RGB-D standoff crosses the capture threshold.
Watch on YouTube ↗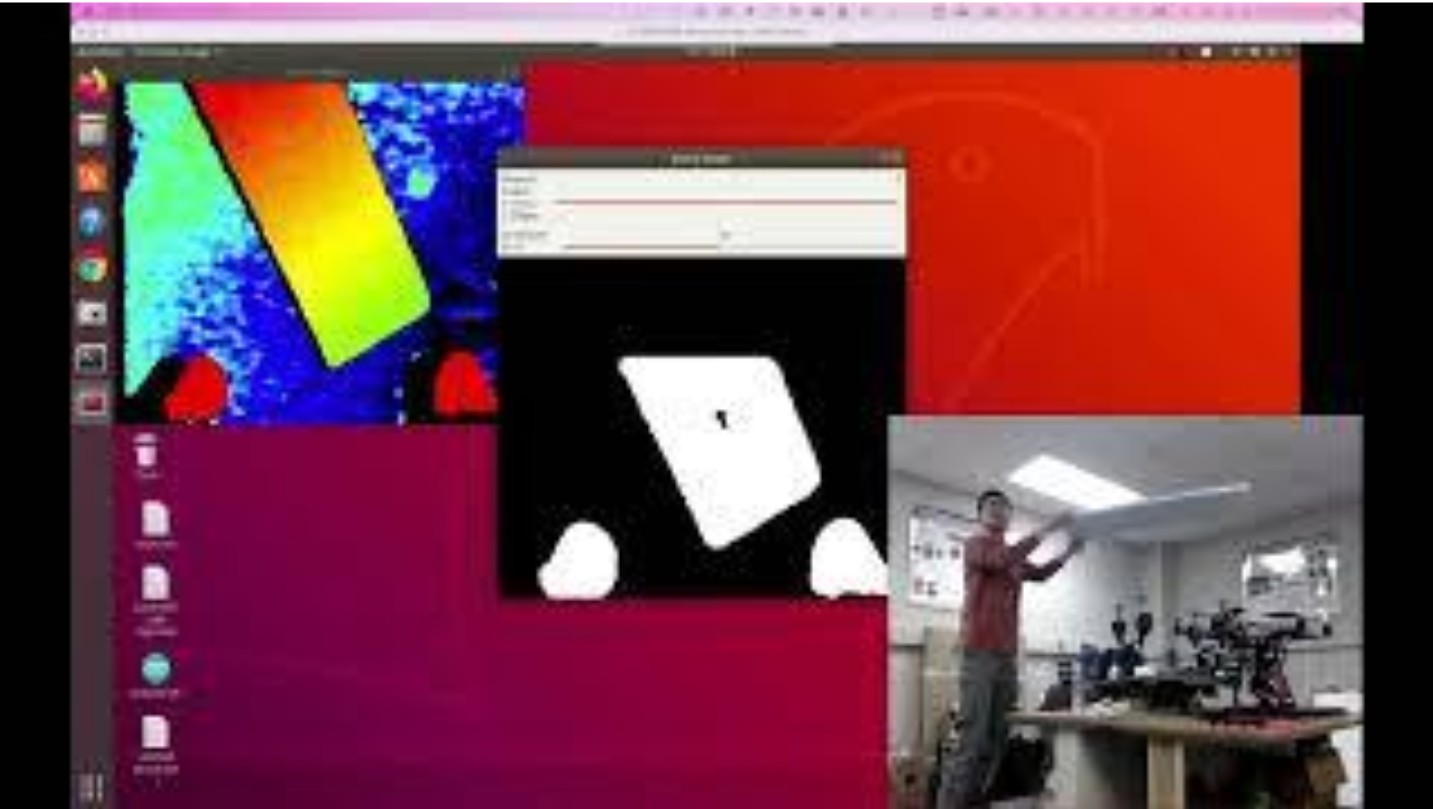
Depth-plane mask extraction estimating yaw orientation of the overhead girder without magnetometers (which steel bridges distort) or GPS.
Watch on YouTube ↗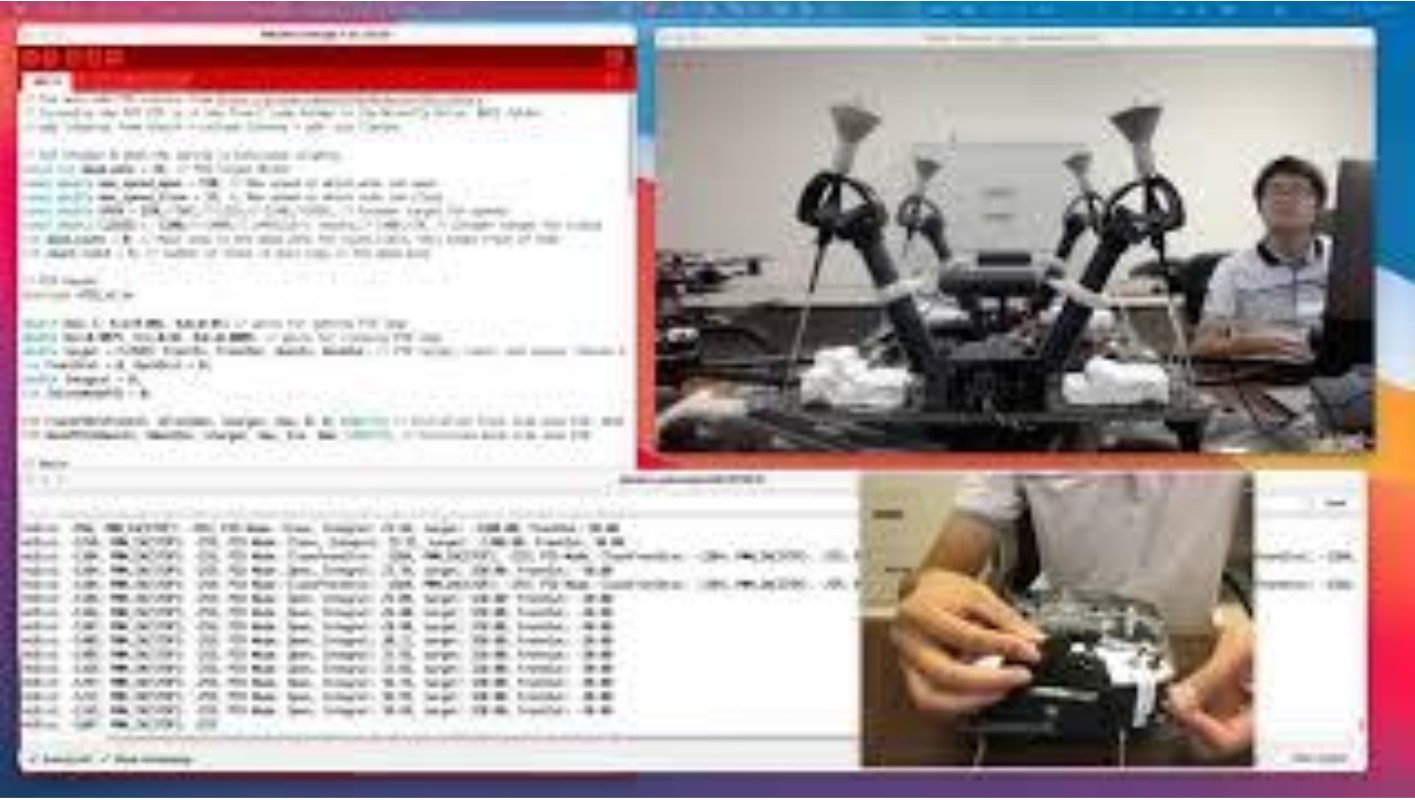
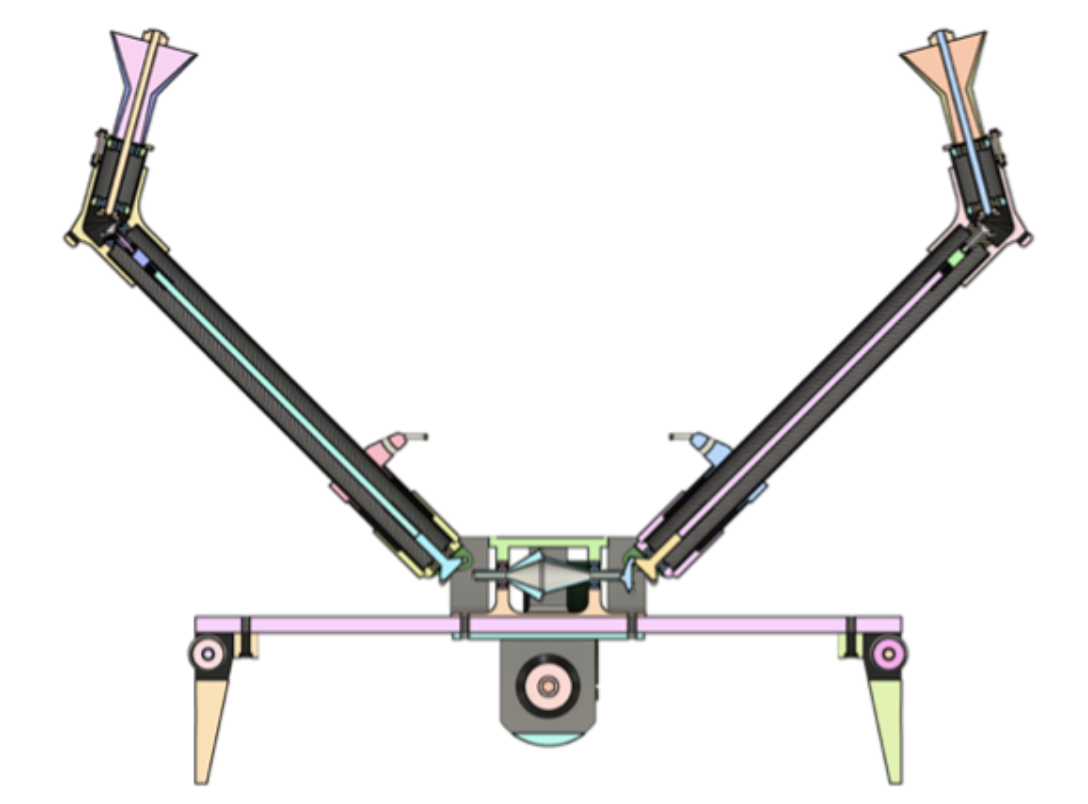
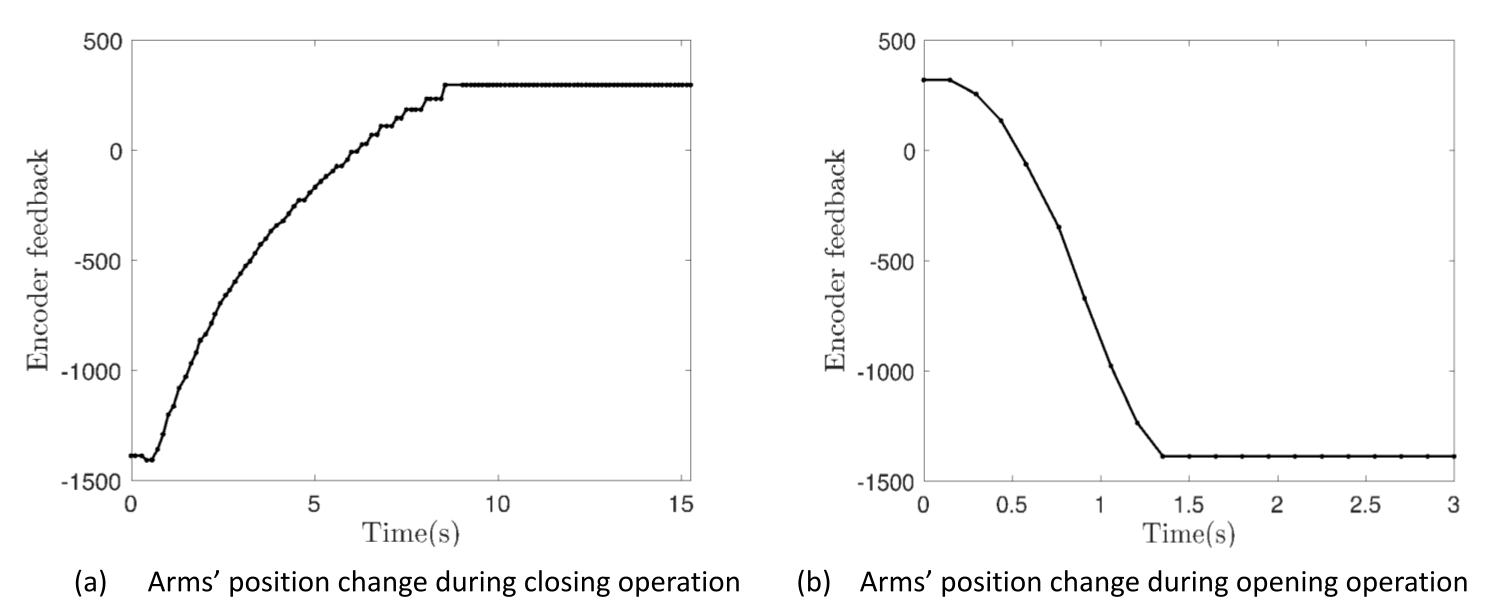
Synchronized front/rear clamping arms with encoder feedback, current/position protection, and asymmetric 1.3 s close / 8.5 s release profile.
Watch on YouTube ↗INTERACTIVE TELEMETRY SANDBOX
Click each operating state below to inspect how propulsion, Jetson RGB-D perception, dual linear clamping arms, and drive rollers coordinate across the mission.
Crossing the vertical distance threshold triggers rapid dual-arm closure in ~1.3 seconds with encoder position limits and PID/fractional-order force regulation against wind gust sway.
PATENTED DUAL-SUBSYSTEM ARCHITECTURE
Co-invented under U.S. Patent 12,296,994 B2, BIRDS integrates two tightly coordinated ROS subsystems with human-in-the-loop supervision via a custom iOS operator app:
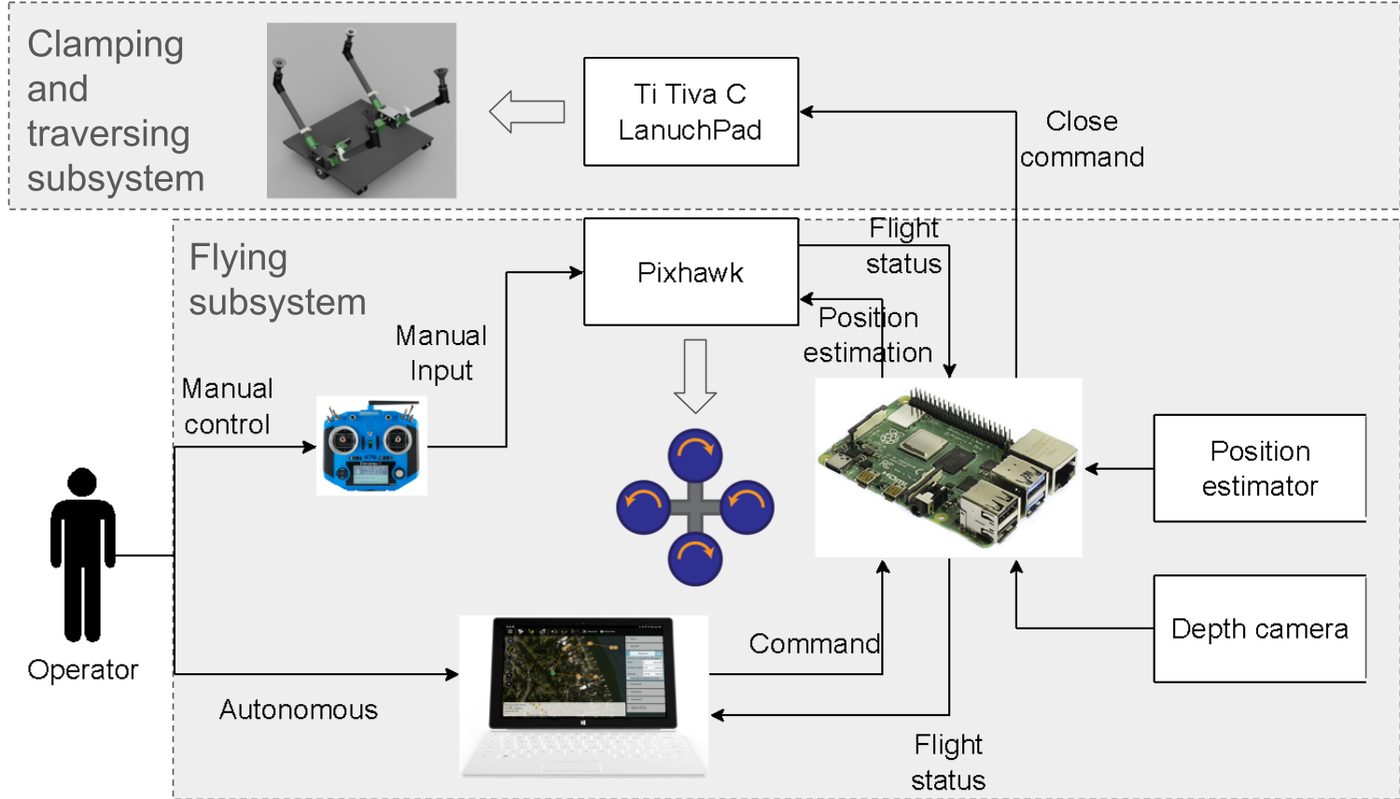
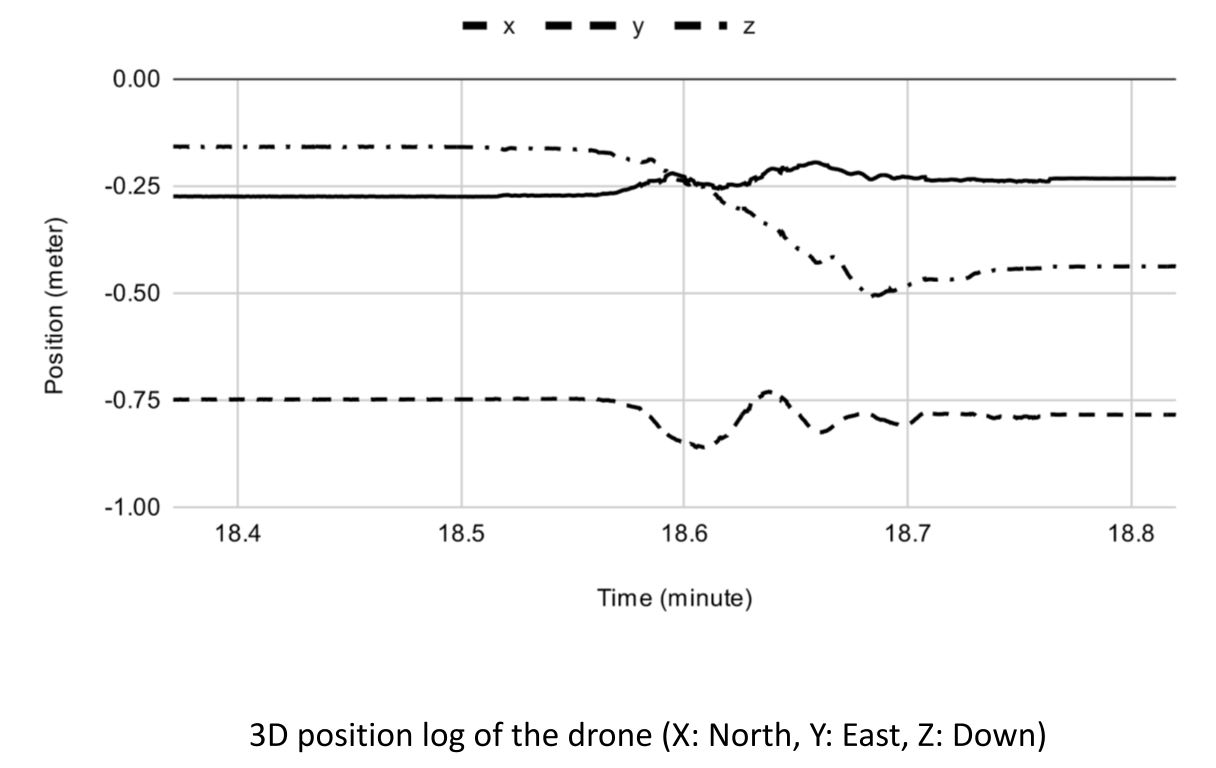
ASYMMETRIC ACTUATION & 3D TRAJECTORY LOGS
When hovering centimeters beneath a bridge girder in turbulent crosswinds, slow mechanical grippers risk blade strikes or missed perches. We engineered an asymmetric PID/fractional-order actuator profile:
PATENT, NATIONAL AWARD & TECHNICAL DELIVERABLES
MULTI-SCALE PORTFOLIO
Physics-grounded intersection observability engine (0.37 ADAS → 1.00 V2I) and sub-meter PET/TTC near-miss audito...
View System Architecture Macro · Continuous Corridor Sensing61.9-hour roadside 3D LiDAR + RGB synchronization, multi-sweep reconstruction, and NYSDOT I-95 corridor evaluati...
View System Architecture Micro · Climbing Robot & 3D NDTWall-climbing robot + iPad TestFlight app + AWS Lambda CNN + WebODM 3D mesh registration for millimeter-scale co...
View System Architecture City · Geospatial AI & SimulationAgency-facing spatiotemporal analytics platform at UMD M-TRAIL integrating LLM-SUMO counterfactual simulation, e...
View System Architecture Micro · Robust Flight ControlIso-damping fractional-order PD^μ quadrotor visual servoing (0.933 s vs. 0.546 s max sampling period) with live ...
View System Architecture Full-Stack AI Product · 0-to-1Bilingual AI research & education platform with Claude + self-hosted Qwen/Ollama agents, 34 courses, and a 34-no...
View System ArchitectureAsk about Bo
AI assistantAsk about Bo's research, teaching, publications or CV. Answers come only from what is published on this site.
Answers are AI-generated from Bo's public CV and may contain mistakes. Please check the CV for the authoritative record.