MICRO SCALE · IEEE T-ASE 2025 · SELECTED FOR IEEE IROS 2025
Robotic Concrete Defect Localization on 3D Structural Meshes
Raw inspection video gives civil engineers thousands of disconnected 2D crack snapshots with no global coordinates or metric scale. Developed at the CCNY Robotics Lab, this end-to-end system connects a wall-climbing robot and iPad operator app to AWS serverless CNN segmentation and WebODM 3D point-cloud registration — localizing and measuring cracks directly on full-scale concrete columns and seawalls.
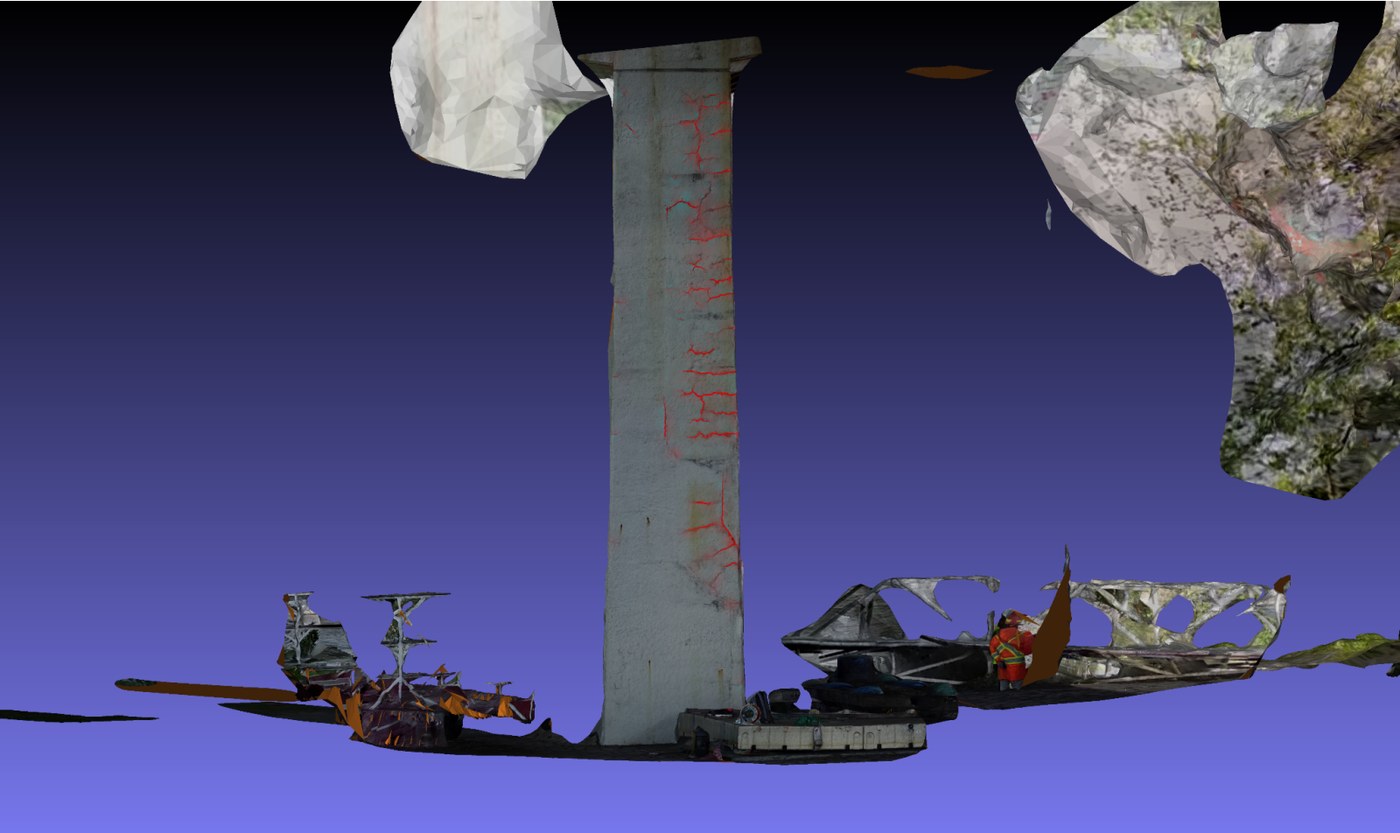
ROBOT-TO-CLOUD-TO-3D ARCHITECTURE
From Wall-Climbing Capture to Metric 3D Crack Skeletons
Note on project lineage: this concrete inspection system at the CCNY Robotics Lab (Prof. Jizhong Xiao's group) is a completely independent research line from the Missouri S&T BIRDS steel-girder project (Prof. Genda Chen's group).
FIELD-TO-CLOUD ENGINEERING
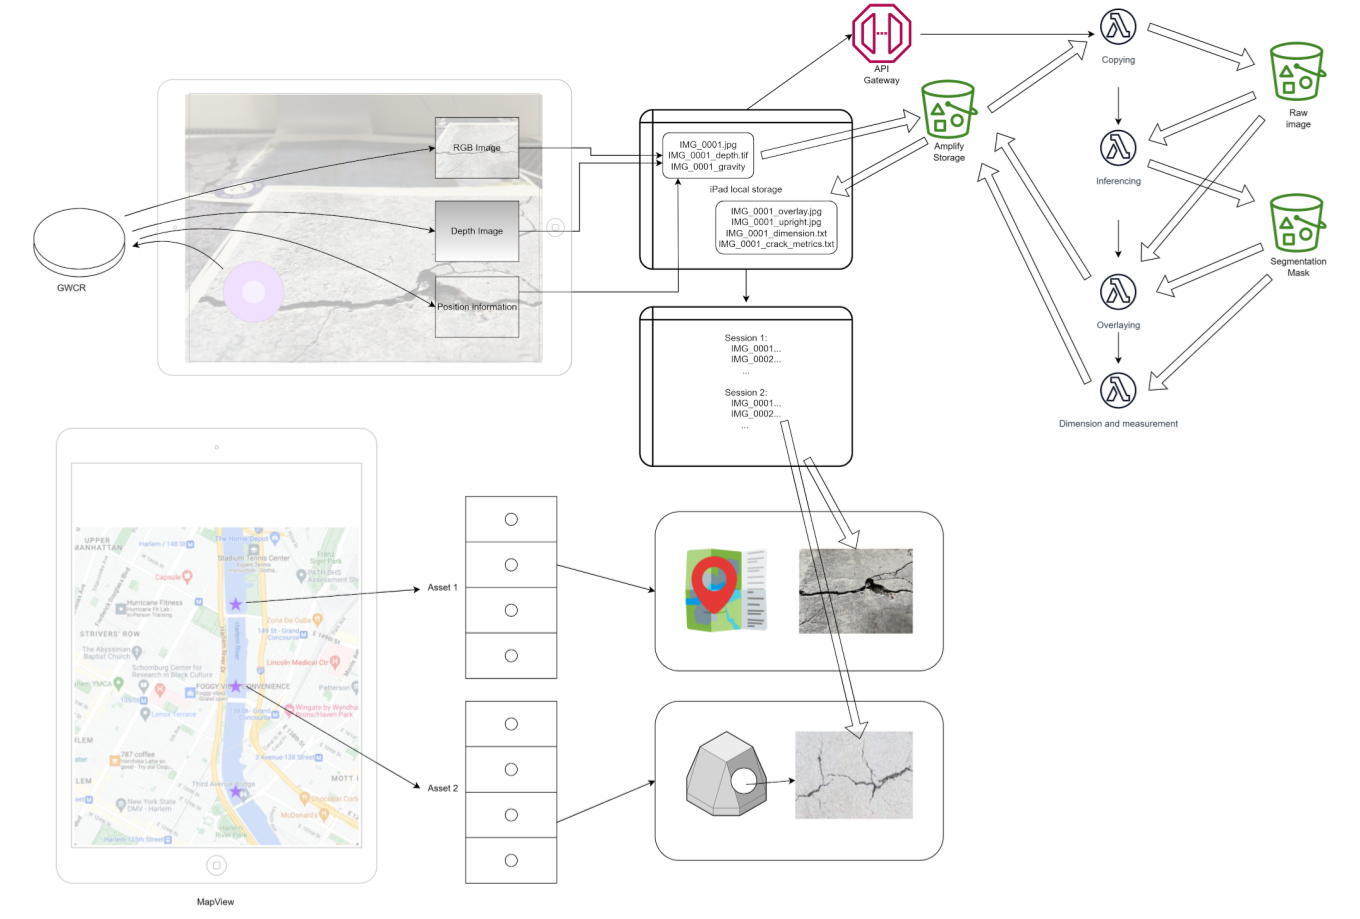
iPad Operator App & AWS Serverless Defect Engine
To make robotic defect analytics usable by field inspectors rather than only lab researchers, I built and deployed the cloud-connected mobile workflow:
- iOS/iPadOS Control & MapView App: Operates the climbing robot via TestFlight, logs RGB + depth + gravity vectors per frame, and pins inspection sessions onto an interactive asset map.
- 4-Stage AWS Lambda Pipeline: Automatically ingests raw session imagery into Amplify/S3, runs deep CNN crack segmentation, generates visual overlays, and computes dimension metrics.
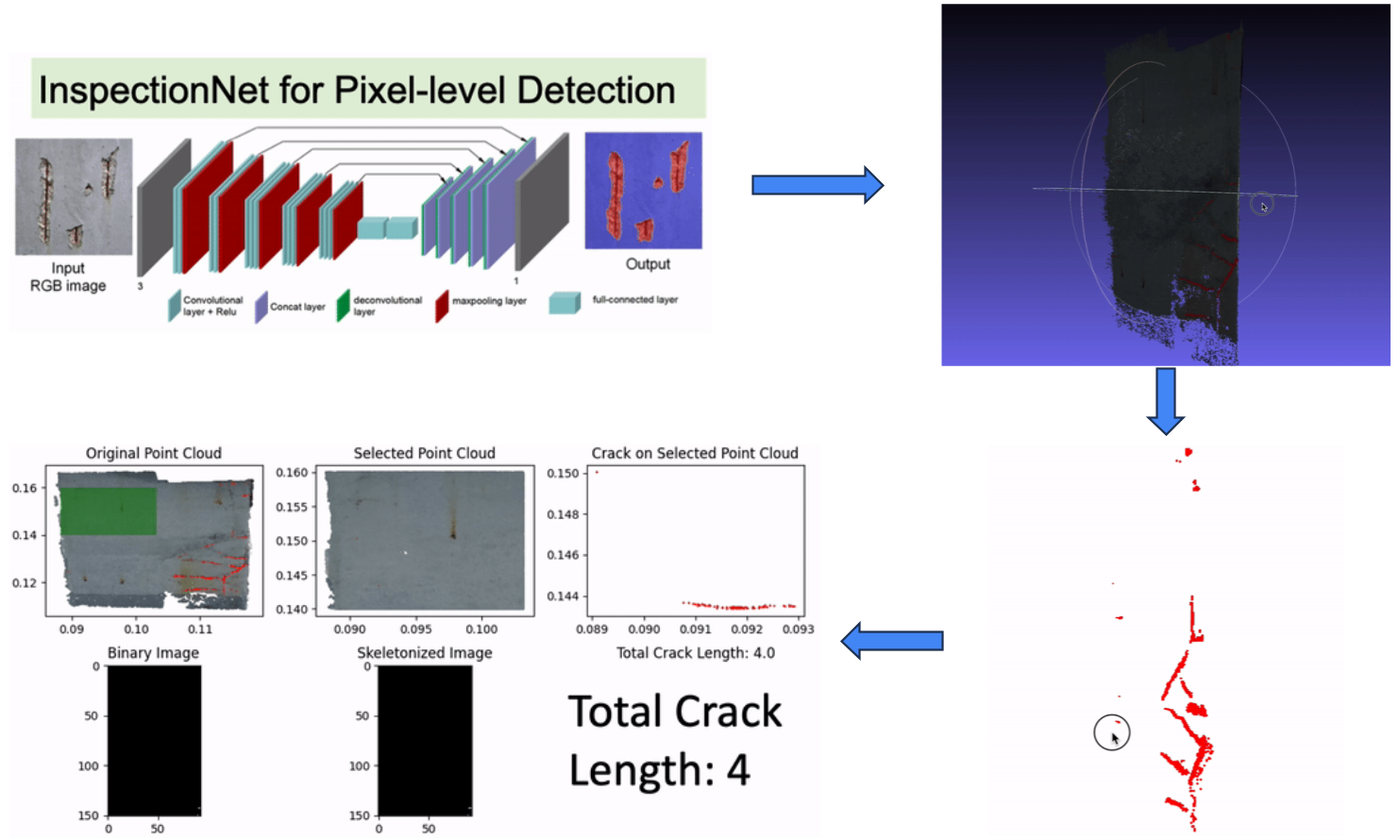
3D LOCALIZATION & MEDIAL-AXIS SKELETONIZATION
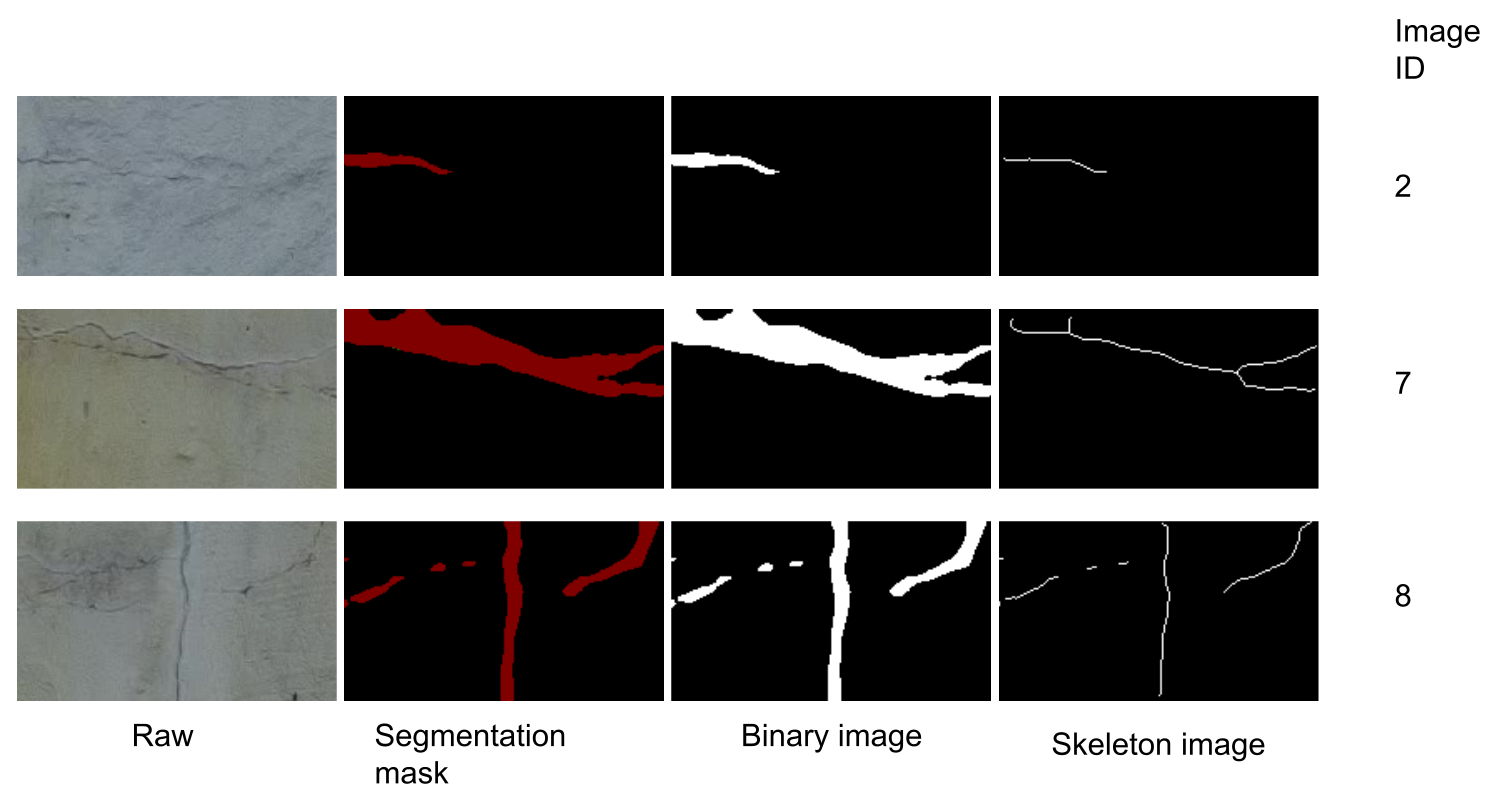
Turning Pixel Masks into Engineering-Grade Crack Topology
Binary segmentation masks alone cannot tell a structural engineer whether a hairline fracture grew by 4 cm since the last biennial cycle. Our analytics pipeline bridges pixels to structural mechanics:
- 2D-to-3D Texture & Point-Cloud Fusion: Registers segmented defect masks directly onto a WebODM 3D structure-from-motion model of the entire concrete pier or seawall.
- Morphological Skeletonization: Extracts 1-pixel medial-axis crack skeletons with homography/depth scale calibration to compute metric crack length and orientation.
- Subsurface NDT Companion Work: Complemented by automated acoustic impact-echo and rotary-percussive sounding analytics plus thermal IR delamination detection.
PEER-REVIEWED JOURNAL & FLAGSHIP CONFERENCE
Primary Publication
Robotic Inspection and Data Analytics to Localize and Visualize the Structural Defects of Concrete Infrastructure
MULTI-SCALE PORTFOLIO
Explore Other Deployed Systems
BIRDS Hybrid Bridge Robot
Patented drone + motorized girder-clamping robot with 1.3 s autonomous flange capture, Jetson RGB-D vision, and ...
View System Architecture Meso · Cooperative V2I LiDARPACO & V2I Safety Auditor
Physics-grounded intersection observability engine (0.37 ADAS → 1.00 V2I) and sub-meter PET/TTC near-miss audito...
View System Architecture Macro · Continuous Corridor SensingHighway LiDAR Sync & InfraLiDAR-Eval
61.9-hour roadside 3D LiDAR + RGB synchronization, multi-sweep reconstruction, and NYSDOT I-95 corridor evaluati...
View System Architecture City · Geospatial AI & SimulationCERRA & LLM-SUMO Platform
Agency-facing spatiotemporal analytics platform at UMD M-TRAIL integrating LLM-SUMO counterfactual simulation, e...
View System Architecture Micro · Robust Flight ControlFractional-Order UAV Servoing
Iso-damping fractional-order PD^μ quadrotor visual servoing (0.933 s vs. 0.546 s max sampling period) with live ...
View System Architecture Full-Stack AI Product · 0-to-1ScholarMind AI Platform
Bilingual AI research & education platform with Claude + self-hosted Qwen/Ollama agents, 34 courses, and a 34-no...
View System Architecture