Autonomous Guided-Mode Visual Servoing & Target Tracking
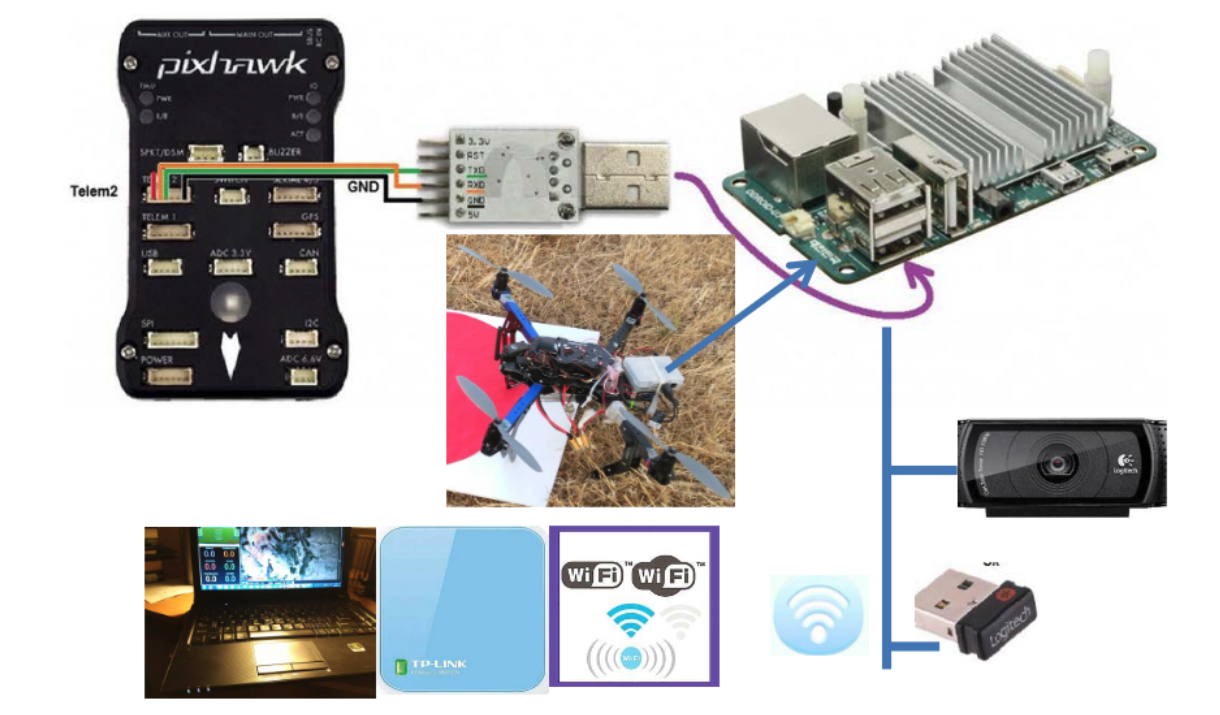
Real-time onboard visual target acquisition, MAVLink velocity-loop command streaming to Pixhawk, and live browser telemetry readout during outdoor hovering.
Watch on YouTube ↗MICRO SCALE · NONLINEAR DYNAMICS 2019 · ICUAS 2016 / 2017
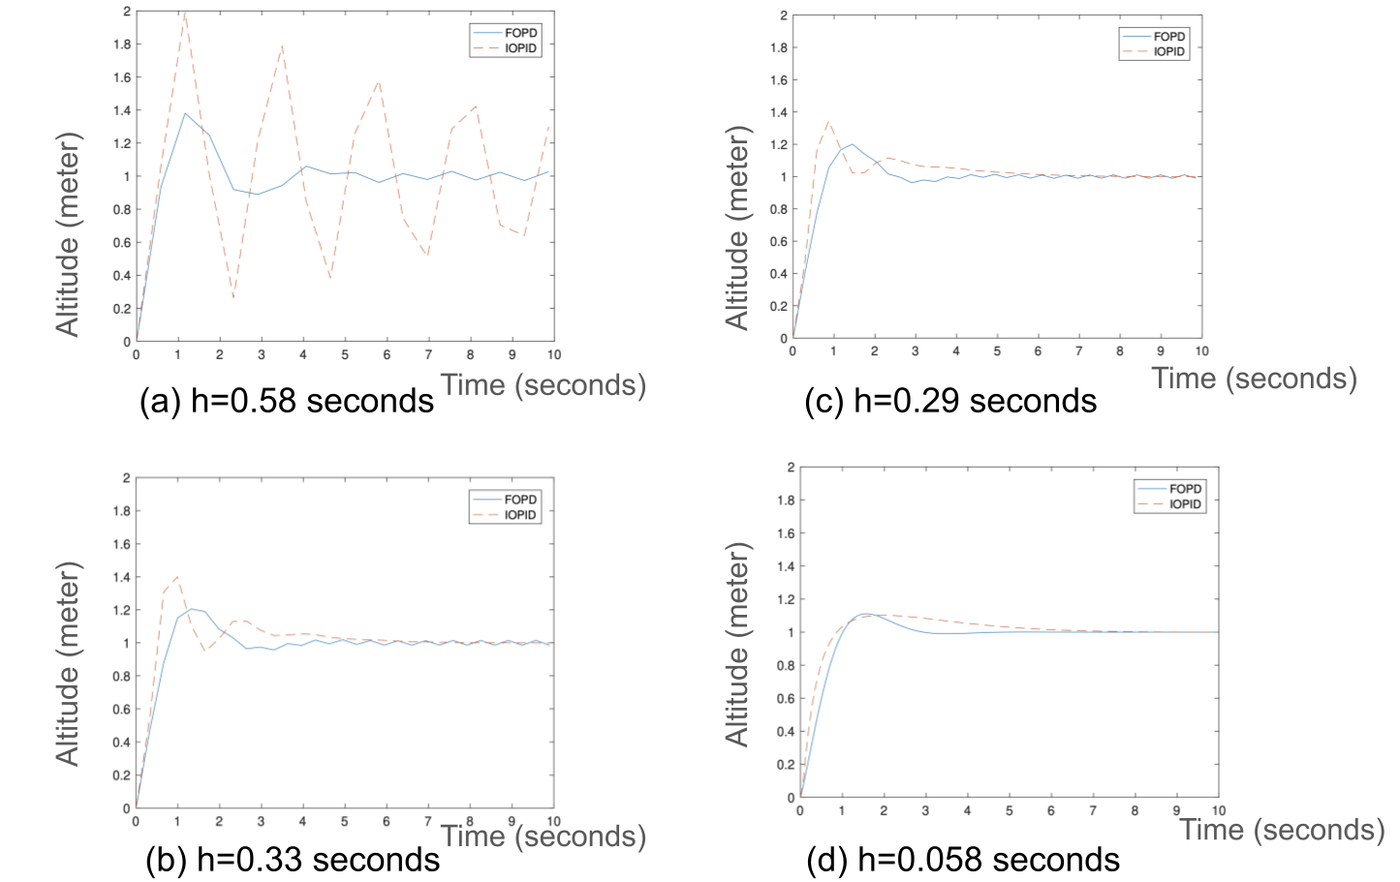
Under bridges and inside GPS-denied caves, small inspection drones rely on onboard vision whose frame rate drops and jitters under compute load. By replacing integer-order PID with an iso-damping fractional-order PD^μ flight controller, we expanded the maximum stable vision sampling period by 71% (0.546 s → 0.933 s) and improved outdoor hovering precision by 20%.

OUTDOOR FLIGHT EXPERIMENT & BROWSER TELEMETRY
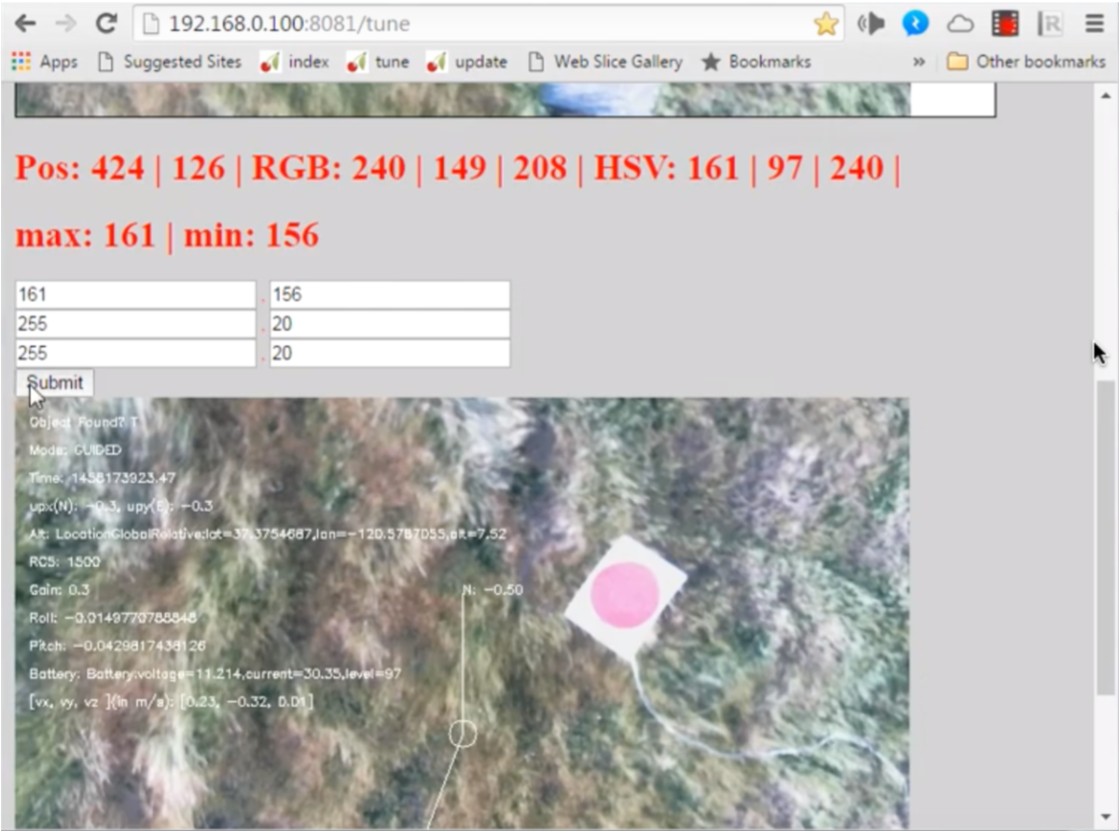
Outdoor illumination shifts rapidly between sun and cloud shadow, causing static color trackers to lose lock mid-flight. Alongside the fractional-order flight controller, I built a live embedded HTTP interface (:8081/tune) on the companion Linux computer for instant pre-flight calibration and telemetry monitoring.
Real-time onboard visual target acquisition, MAVLink velocity-loop command streaming to Pixhawk, and live browser telemetry readout during outdoor hovering.
Watch on YouTube ↗
INTERACTIVE CONTROL SANDBOX
PD^μ Survives Large Vision DelaysIncrease the vision sampling period h below to observe how integer-order PID rings and diverges past h = 0.546 s, whereas the fractional-order controller maintains bounded convergence up to h = 0.933 s.
FREQUENCY & FLIGHT-DOMAIN VALIDATION
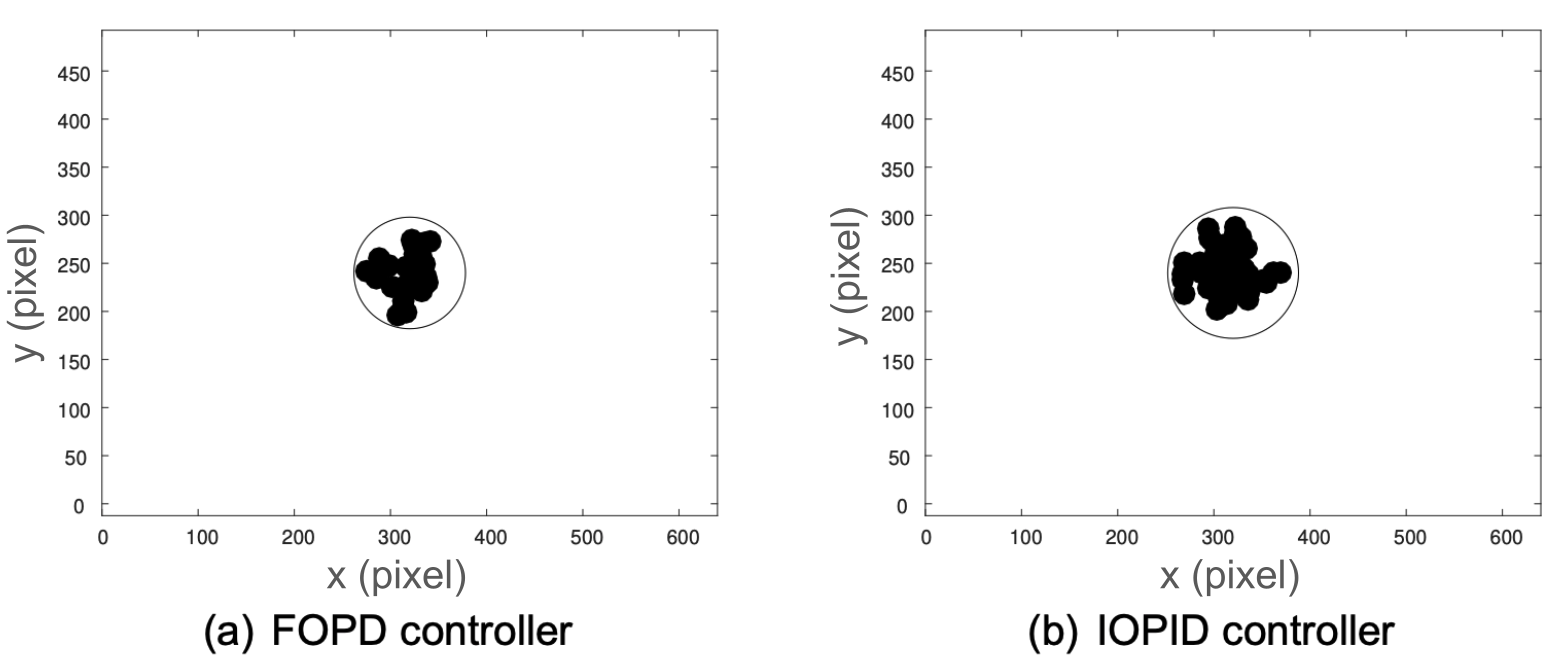
By enforcing zero phase derivative at the gain crossover frequency, the fractional differentiation order μ flattens the Bode phase curve — keeping step-response overshoot invariant when battery voltage drops or payload mass changes, and tightening real flight pixel error dispersion by 20%.


MULTI-SCALE PORTFOLIO
Patented drone + motorized girder-clamping robot with 1.3 s autonomous flange capture, Jetson RGB-D vision, and ...
View System Architecture Meso · Cooperative V2I LiDARPhysics-grounded intersection observability engine (0.37 ADAS → 1.00 V2I) and sub-meter PET/TTC near-miss audito...
View System Architecture Macro · Continuous Corridor Sensing61.9-hour roadside 3D LiDAR + RGB synchronization, multi-sweep reconstruction, and NYSDOT I-95 corridor evaluati...
View System Architecture Micro · Climbing Robot & 3D NDTWall-climbing robot + iPad TestFlight app + AWS Lambda CNN + WebODM 3D mesh registration for millimeter-scale co...
View System Architecture City · Geospatial AI & SimulationAgency-facing spatiotemporal analytics platform at UMD M-TRAIL integrating LLM-SUMO counterfactual simulation, e...
View System Architecture Full-Stack AI Product · 0-to-1Bilingual AI research & education platform with Claude + self-hosted Qwen/Ollama agents, 34 courses, and a 34-no...
View System Architecture