MACRO SCALE · NYSDOT I-95 & NYC DOT · 61.9 HOURS
Continuous Highway 3D LiDAR + RGB Synchronization & Evaluation
Models trained on sunny 20-second ego-vehicle clips break down on multi-lane highways when clocks drift by tens of milliseconds or sparse far-range sweeps hit 6-lane traffic. We engineered an end-to-end synchronized capture, calibration, and sparse-to-dense 3D perception pipeline validated across 61.9 hours (743 raw sessions) and live NYSDOT I-95 deployments.
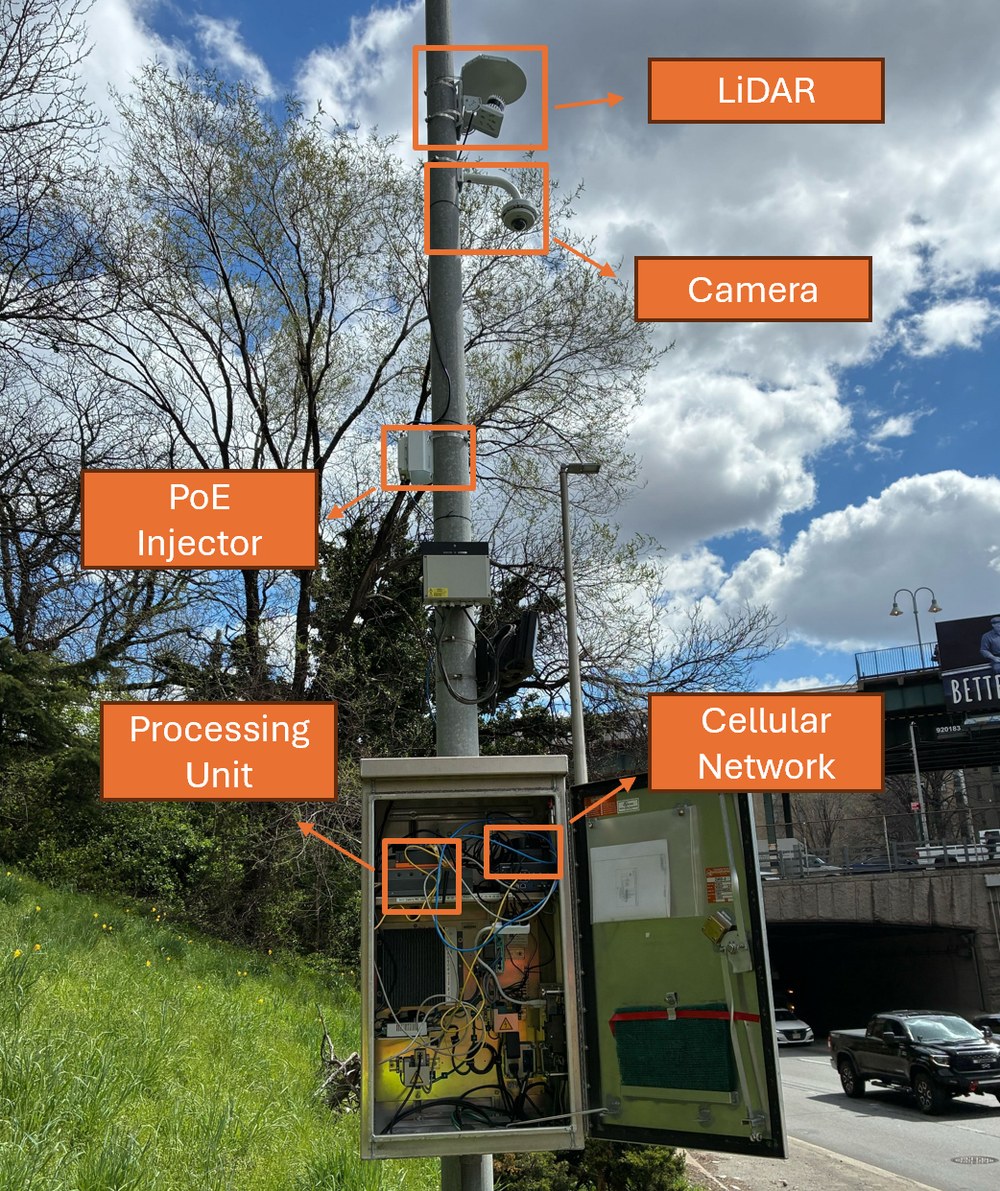
WHY SYNCHRONIZATION IS THE HARD PART
Sub-Frame Temporal & Spatial Alignment at Highway Speeds
At 65 mph (29 m/s), a 50 ms clock offset between a spinning 3D LiDAR and an RGB camera shifts projected bounding boxes by 1.45 meters — smearing multi-frame point-cloud reconstruction and collapsing downstream VRU/freight classification.
Multi-Sensor Ingestion
Continuous capture of raw 3D LiDAR UDP sweeps and high-resolution RGB streams across 743 unattended field sessions.
Temporal Drift Correction
Timestamp alignment and online clock-skew compensation between LiDAR hardware timestamps and camera exposure triggers.
6-DoF Extrinsic Calibration
Rigid spatial calibration mapping 3D point clouds onto RGB image planes across varying mast heights and tilt geometries.
Background Modeling
Exploiting stationary roadside geometry to strip guardrails, overpasses, and foliage before 3D proposal generation.
CNN 3D VRU & Freight Detection
Config-portable 3D detection classifying passenger cars, multi-unit freight trucks, motorcycles, cyclists, and pedestrians.
Multi-Frame Vehicle Stitching
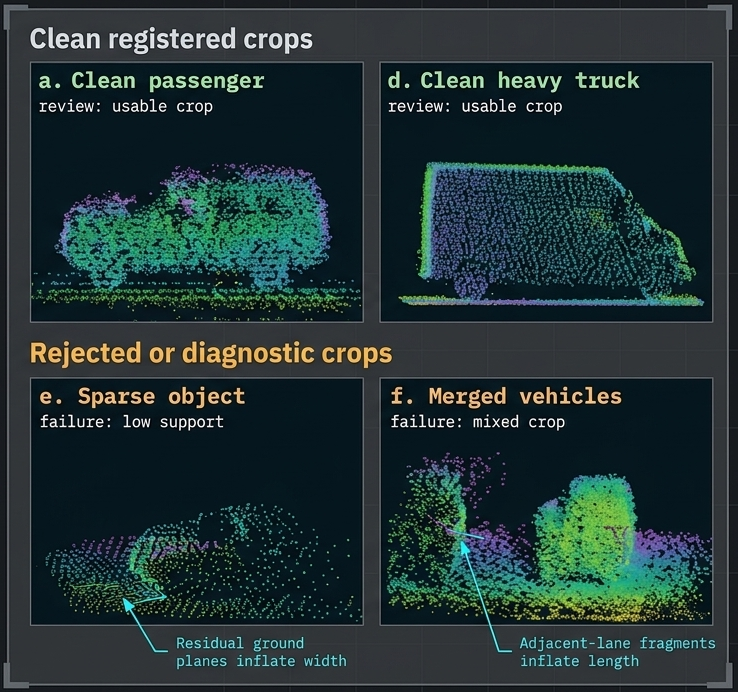
Rigid-body registration accumulating sparse distant LiDAR returns across consecutive sweeps into dense per-vehicle 3D models.
NYSDOT I-95 BENCHMARK · INFRALIDAR-EVAL
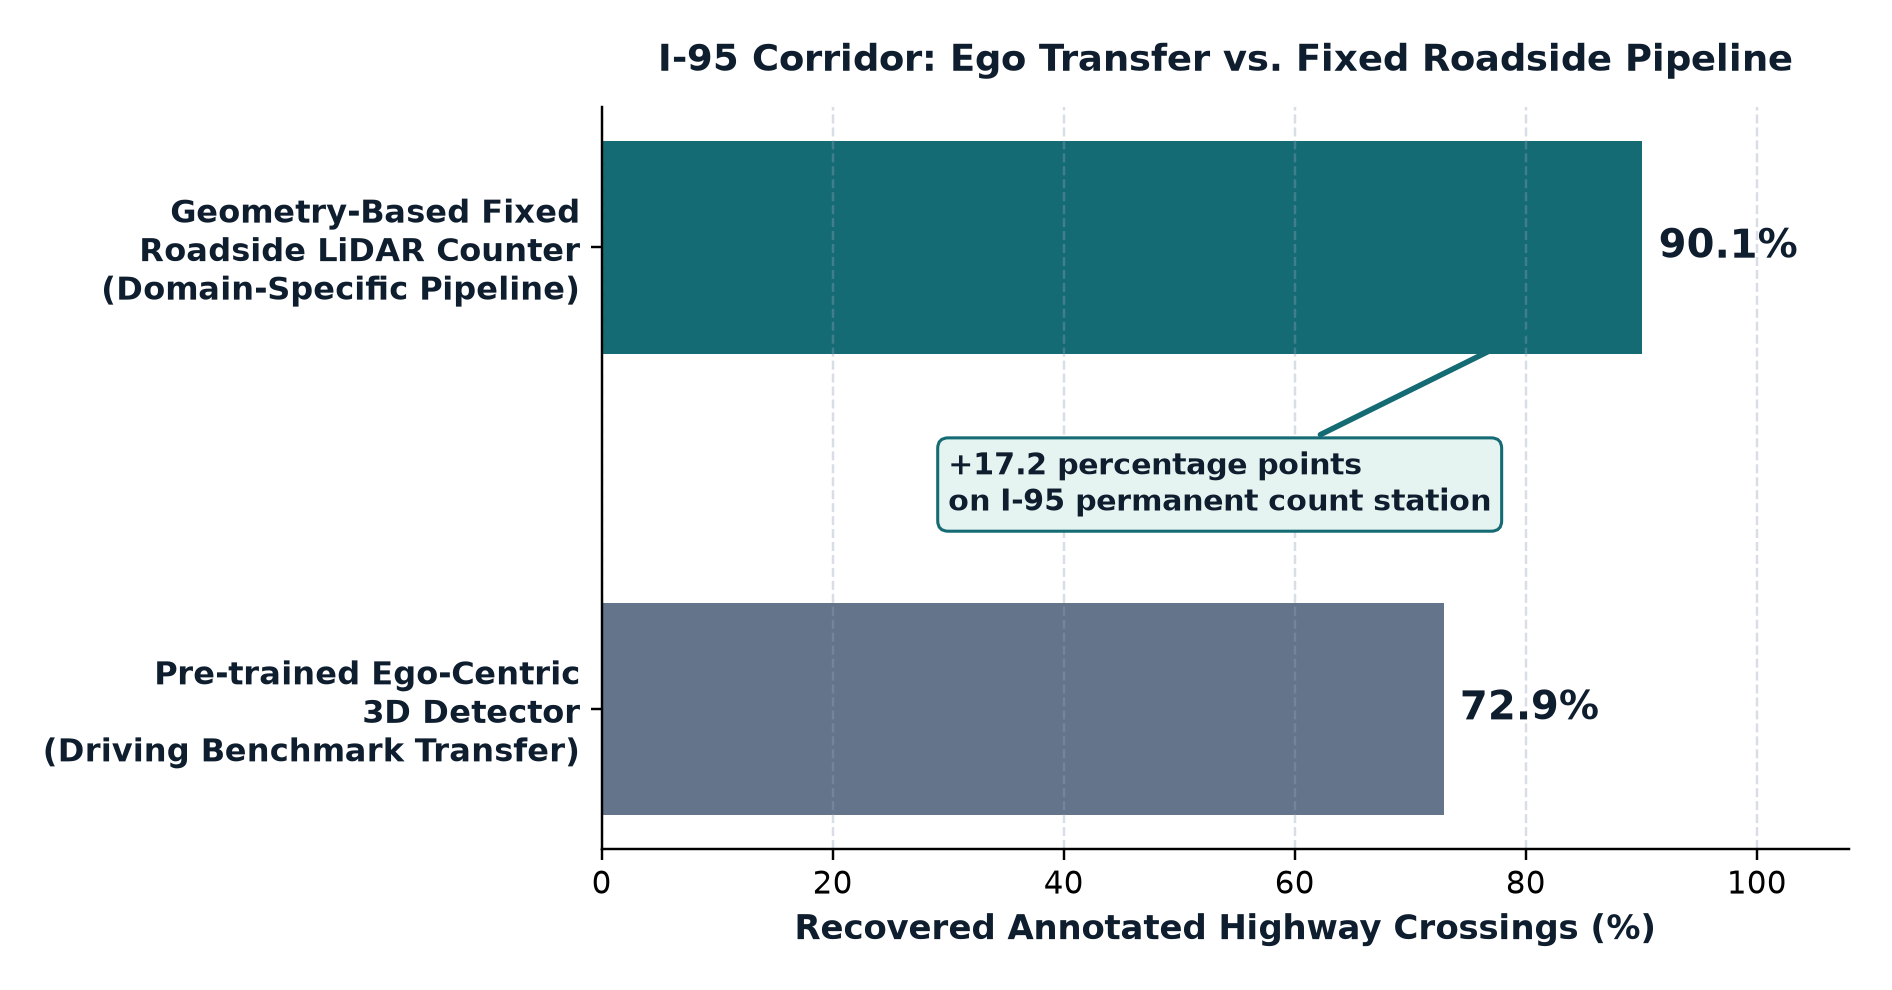
90.1% Fixed-Sensor Crossing Recovery vs. 72.9% Ego Baseline
Off-the-shelf 3D detectors trained on ego-vehicle datasets (KITTI, Waymo, nuScenes) assume a sensor moving at bumper/roof height (~1.8 m). Mounted on an elevated roadside mast overlooking Interstate 95 in the Bronx, those ego-centric models drop to 72.9% vehicle crossing recovery due to pitch/height domain shift and far-lane sparsity.
- Fixed-Geometry Conditioning (90.1%): Incorporating stationary background priors, ground-plane rectification, and temporal track continuity recovers +17.2 percentage points on live highway traffic.
- 61.9-Hour Failure Taxonomy: Documents sensor thermal drift, rain/spray backscatter, heavy-truck shadow handoffs, and beam-count sensitivity across 743 sessions.
FINE-GRAINED FREIGHT & ZERO-INFRASTRUCTURE SCALING
From Dense 3D Truck Profiles to Citywide Curbside Freight Sensing
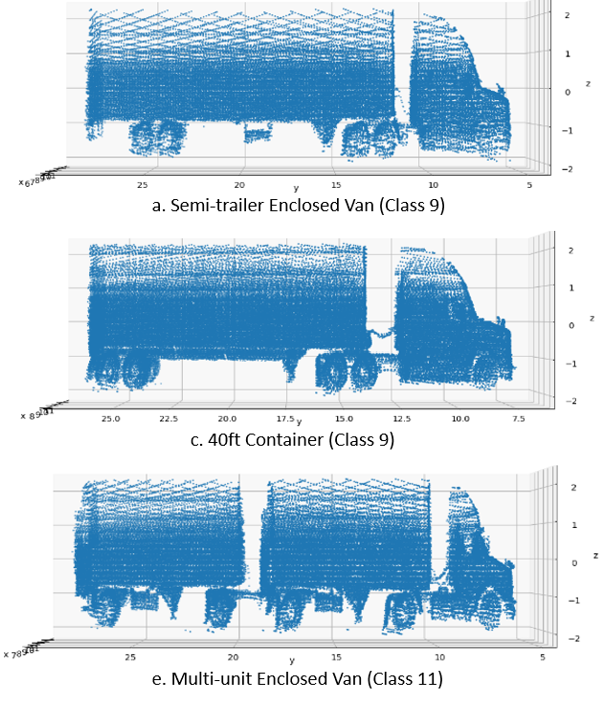
Multi-sweep point-cloud registration unlocks fine-grained geometric classification of commercial vehicles (box trucks, articulated tractor-trailers, tankers) directly from roadside LiDAR — and pairs with citywide Street View imagery (IEEE OJ-ITS 2026) and VLM-guided traffic curation to map freight demand before permanent sensors are installed.
PUBLICATIONS & AGENCY COLLABORATIONS
Published Corridor & Freight Sensing Work
Citywide Urban Freight & Truck Activity Estimation from Street-Level Imagery
Roadside Sensing Perspectives & LiDAR Beam-Count Study for VRU Detection
MULTI-SCALE PORTFOLIO
Explore Other Deployed Systems
BIRDS Hybrid Bridge Robot
Patented drone + motorized girder-clamping robot with 1.3 s autonomous flange capture, Jetson RGB-D vision, and ...
View System Architecture Meso · Cooperative V2I LiDARPACO & V2I Safety Auditor
Physics-grounded intersection observability engine (0.37 ADAS → 1.00 V2I) and sub-meter PET/TTC near-miss audito...
View System Architecture Micro · Climbing Robot & 3D NDTConcrete 3D Defect Analytics
Wall-climbing robot + iPad TestFlight app + AWS Lambda CNN + WebODM 3D mesh registration for millimeter-scale co...
View System Architecture City · Geospatial AI & SimulationCERRA & LLM-SUMO Platform
Agency-facing spatiotemporal analytics platform at UMD M-TRAIL integrating LLM-SUMO counterfactual simulation, e...
View System Architecture Micro · Robust Flight ControlFractional-Order UAV Servoing
Iso-damping fractional-order PD^μ quadrotor visual servoing (0.933 s vs. 0.546 s max sampling period) with live ...
View System Architecture Full-Stack AI Product · 0-to-1ScholarMind AI Platform
Bilingual AI research & education platform with Claude + self-hosted Qwen/Ollama agents, 34 courses, and a 34-no...
View System Architecture